Nonprofit · 2022–2024
PerryBotics
I founded and led PerryBotics, a nonprofit cultivating engineering passion through competitive robotics. I mentored teams of 7–14 high school students building for the VEX Robotics Competition (20,000+ teams globally), and directed engineering, timeline, and finances.
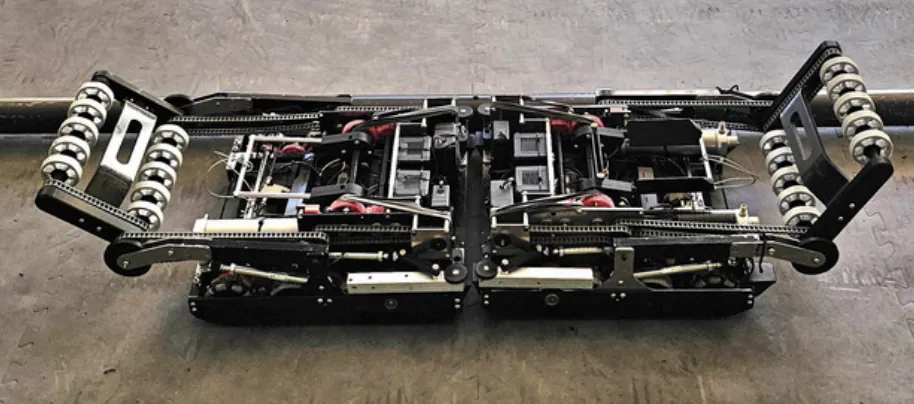
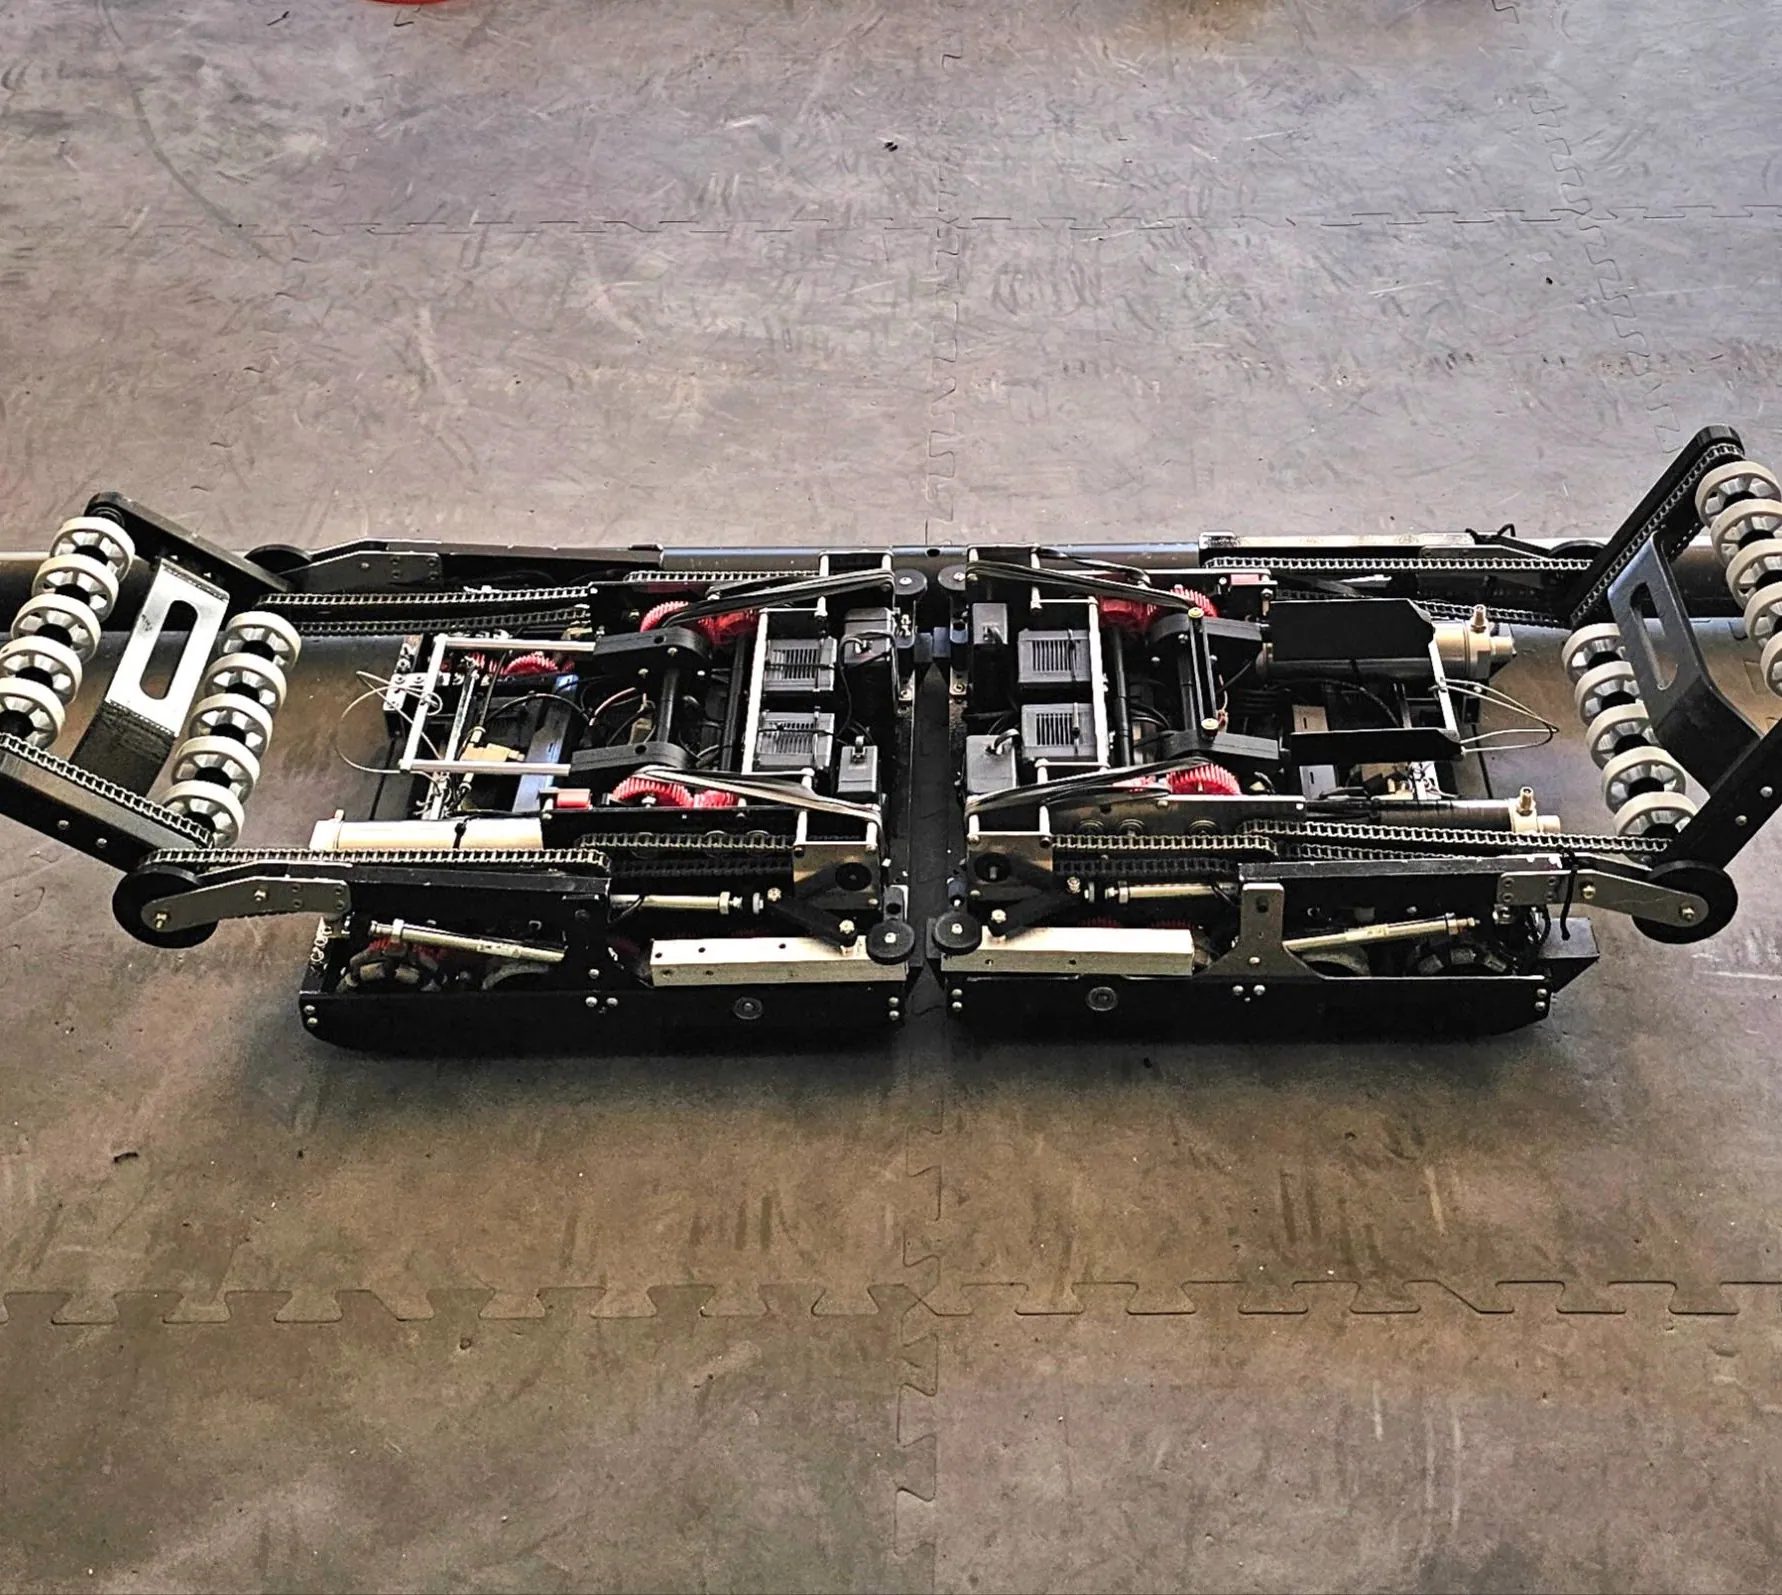
2024 · Over Under
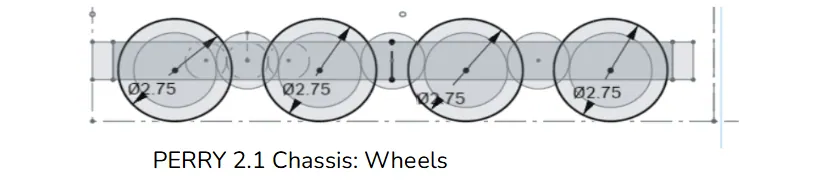
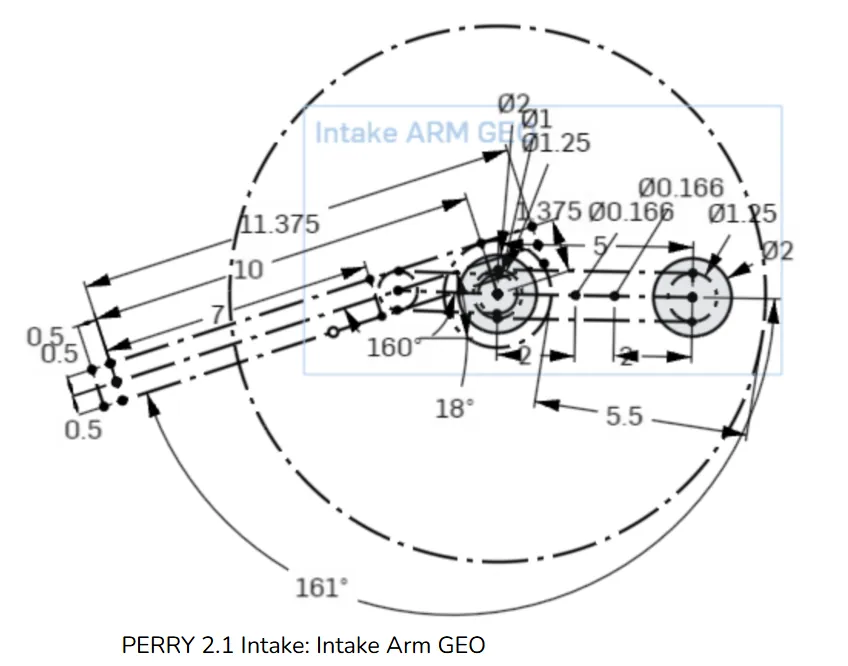
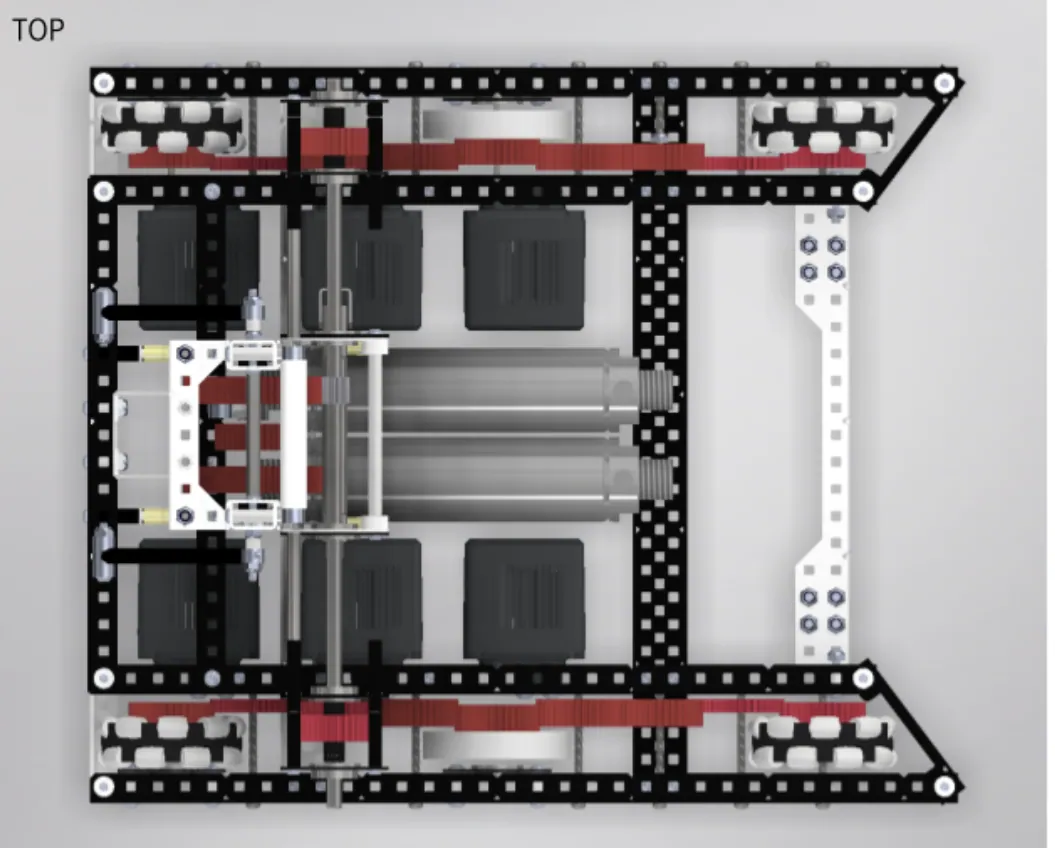
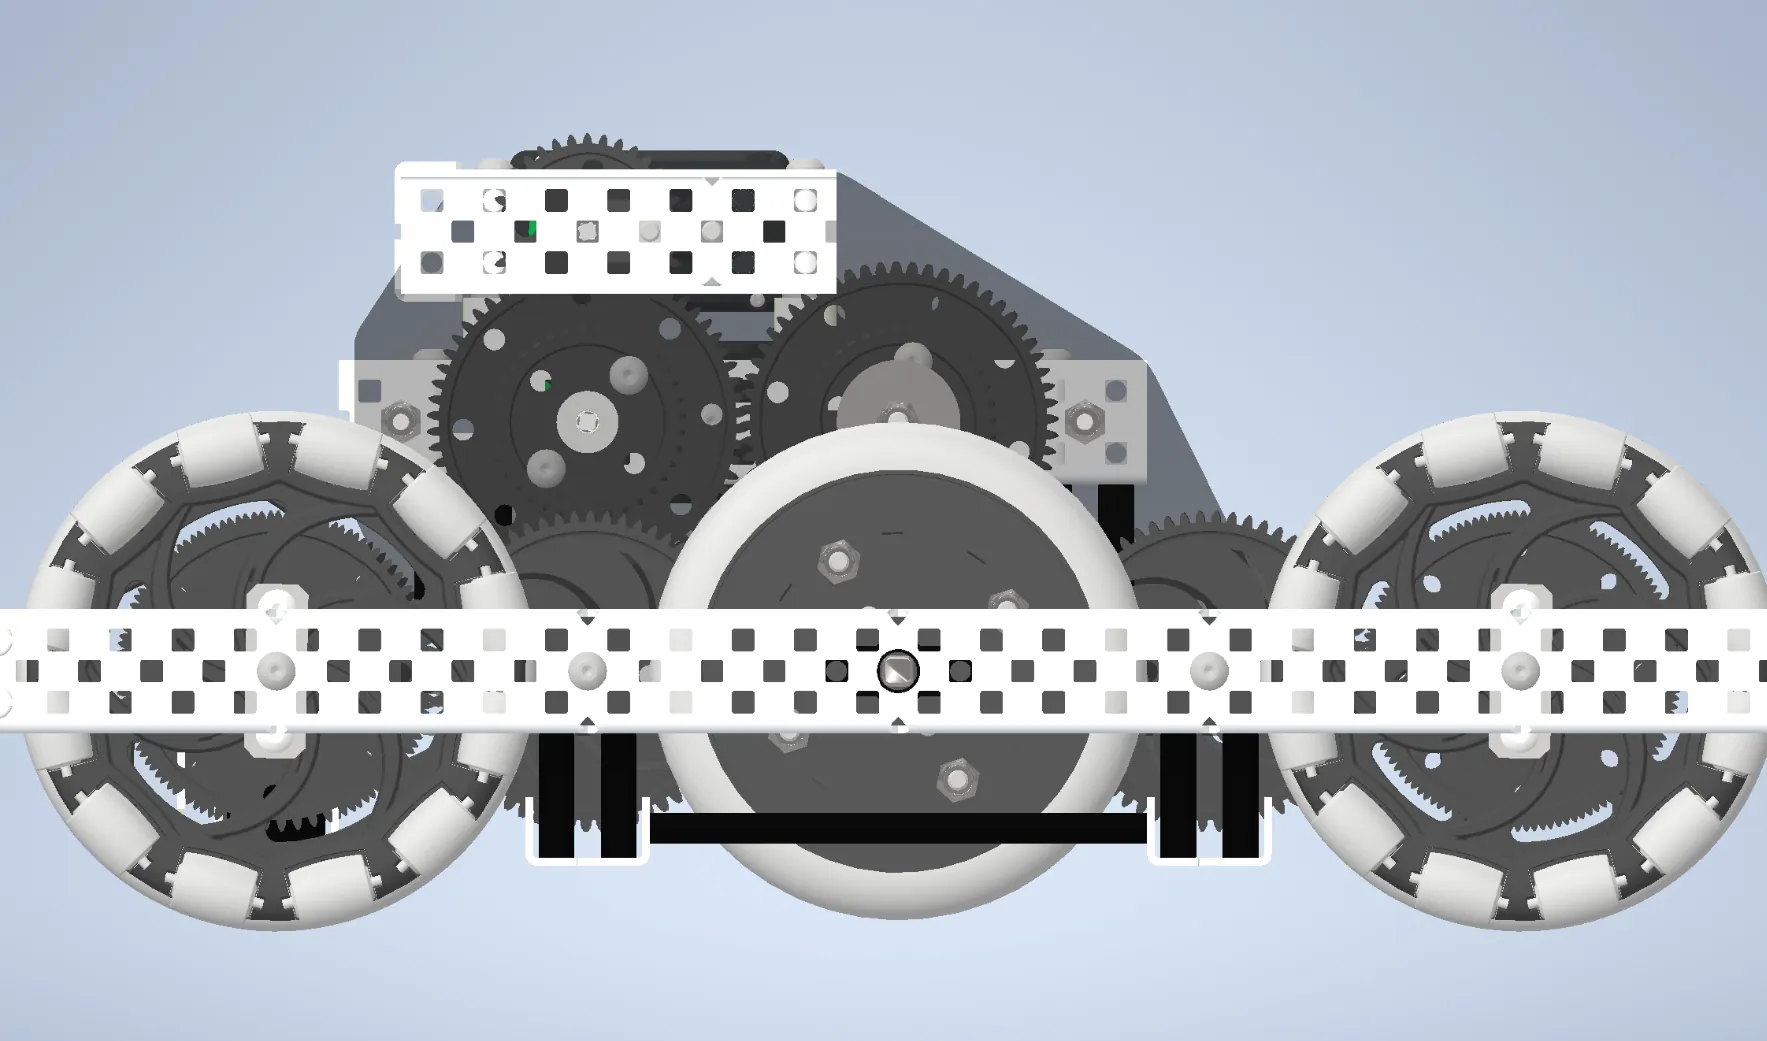
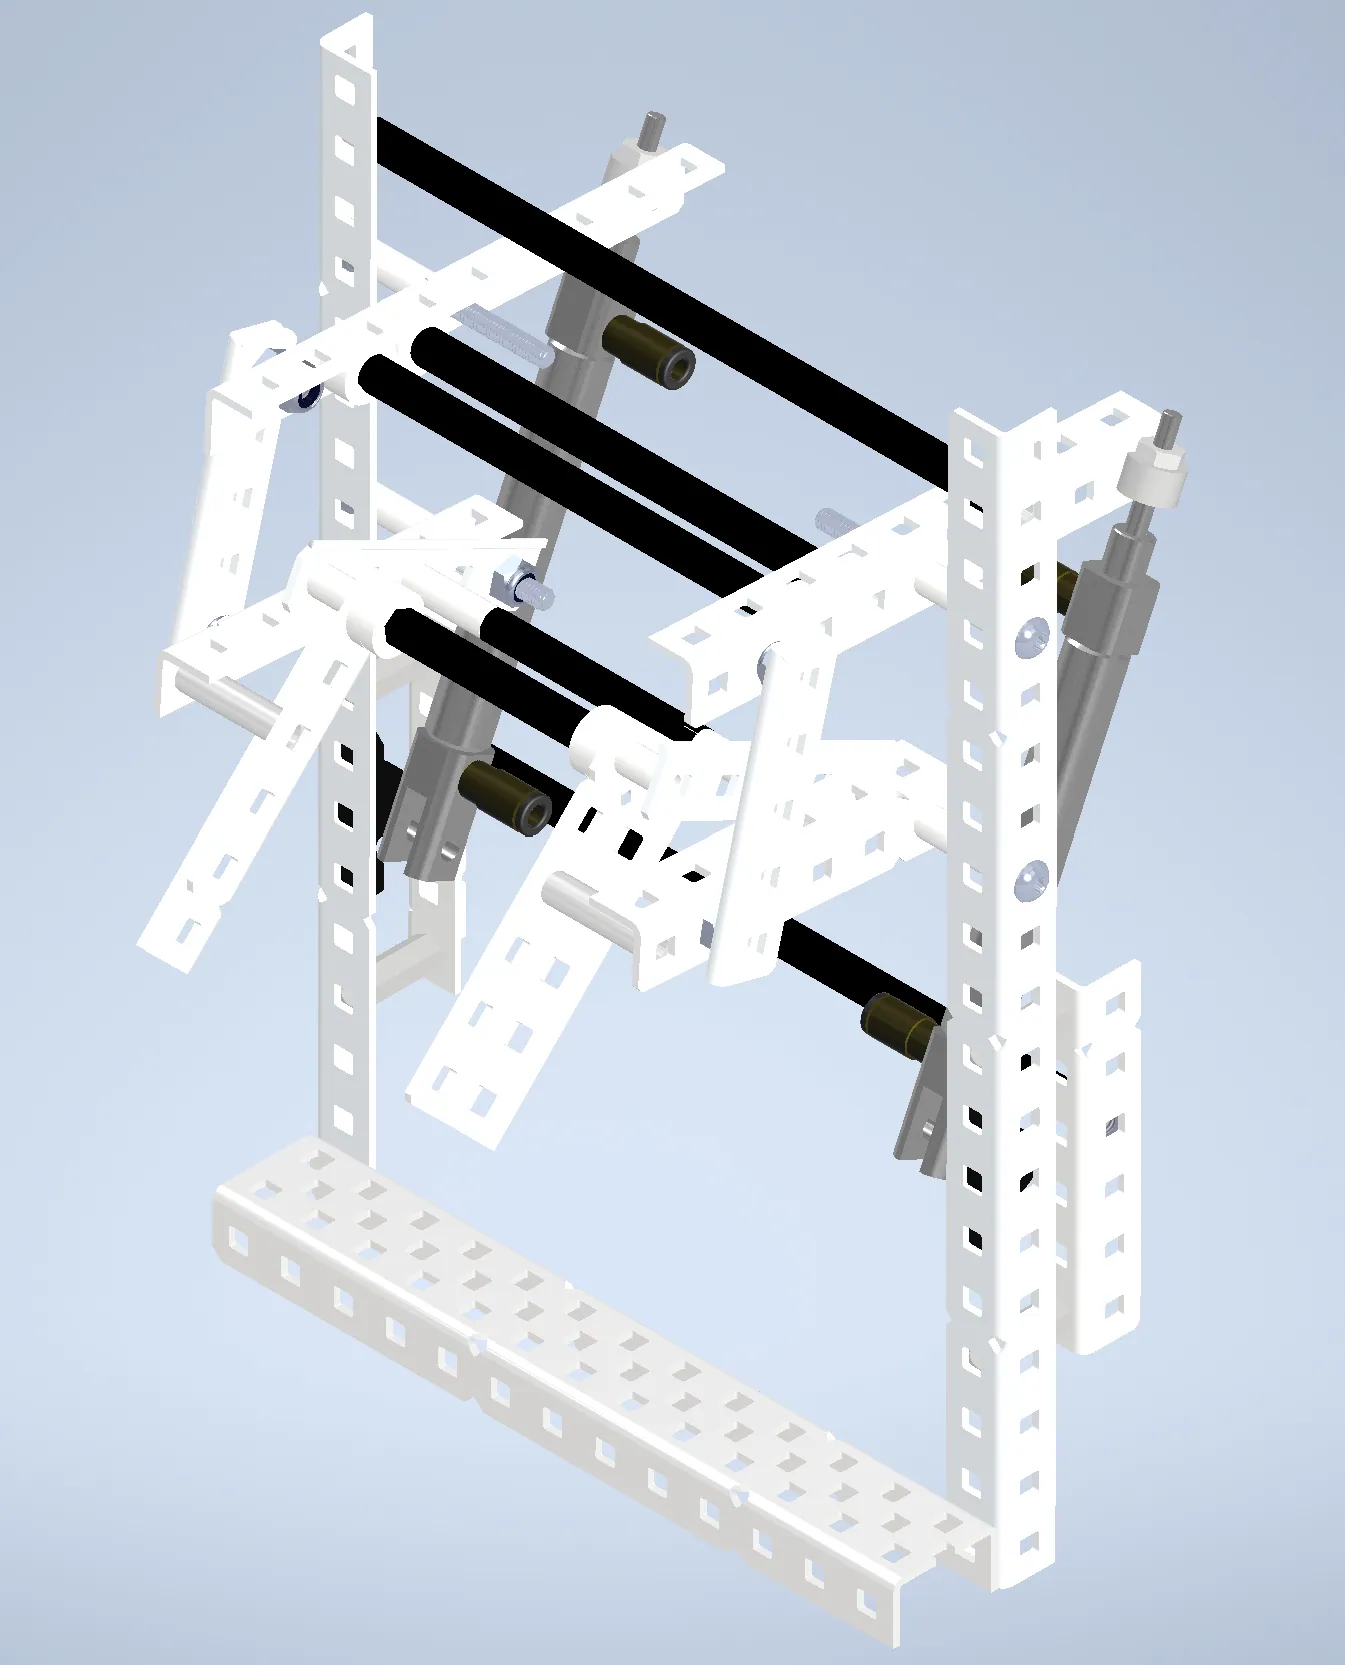
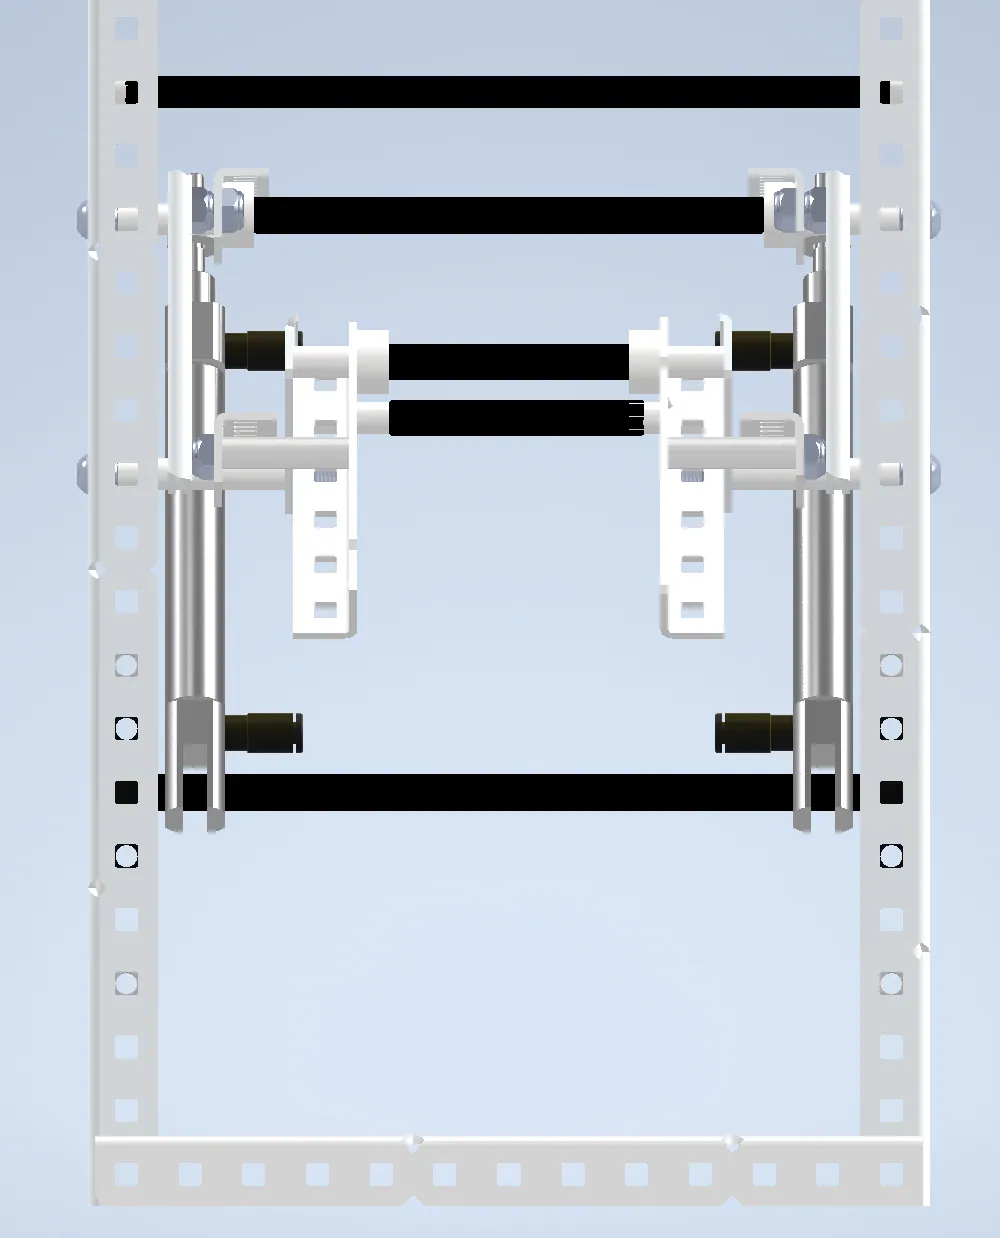
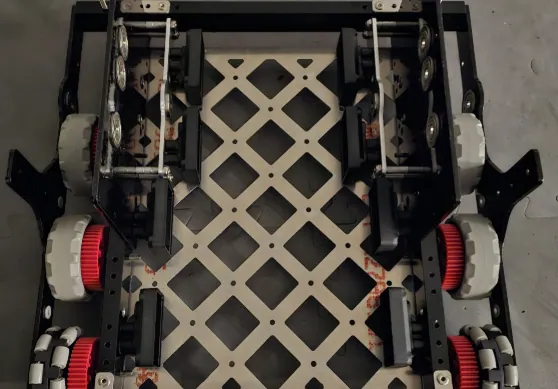
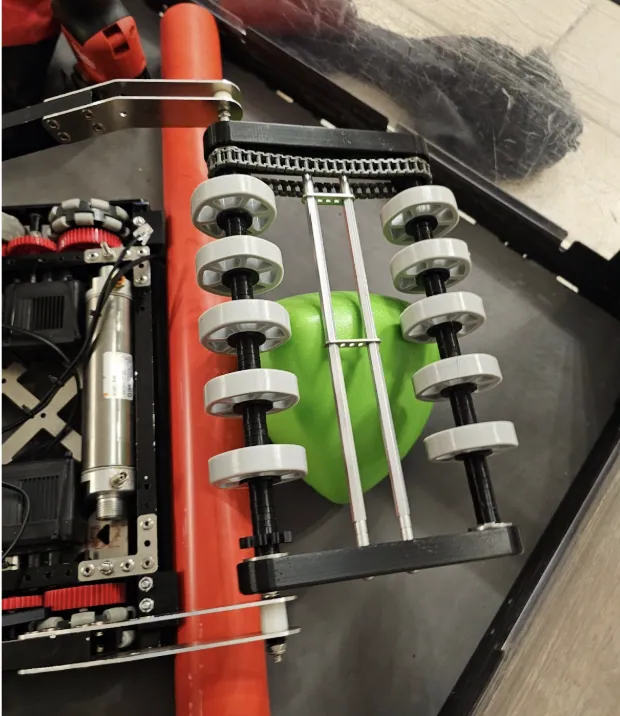
Two identical 15" cubes for full scoring, descoring, and traversal. 8-motor, 8-wheel drive at 8.5 ft/s, collapsing under 6 inches to pass beneath goals. Dual wings for object control, a 2-DOF intake arm extending 8 inches, and a custom catapult. 50+ custom components per robot, including printed gears and gearboxes.
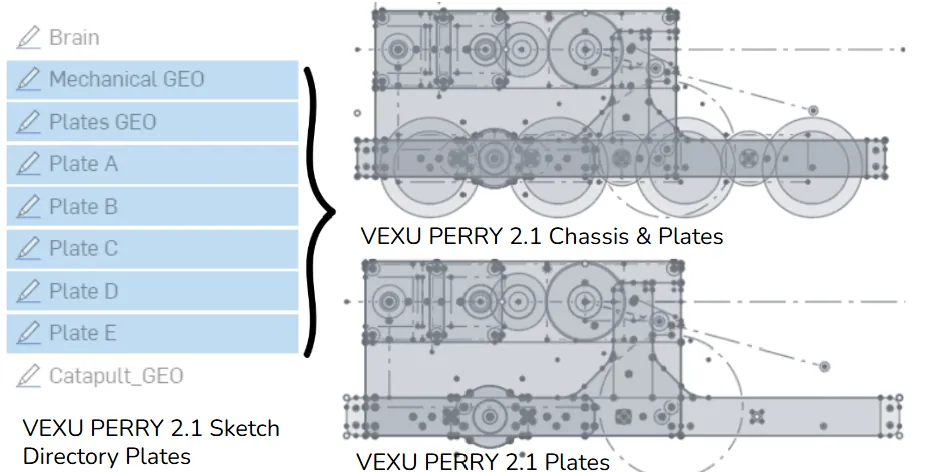
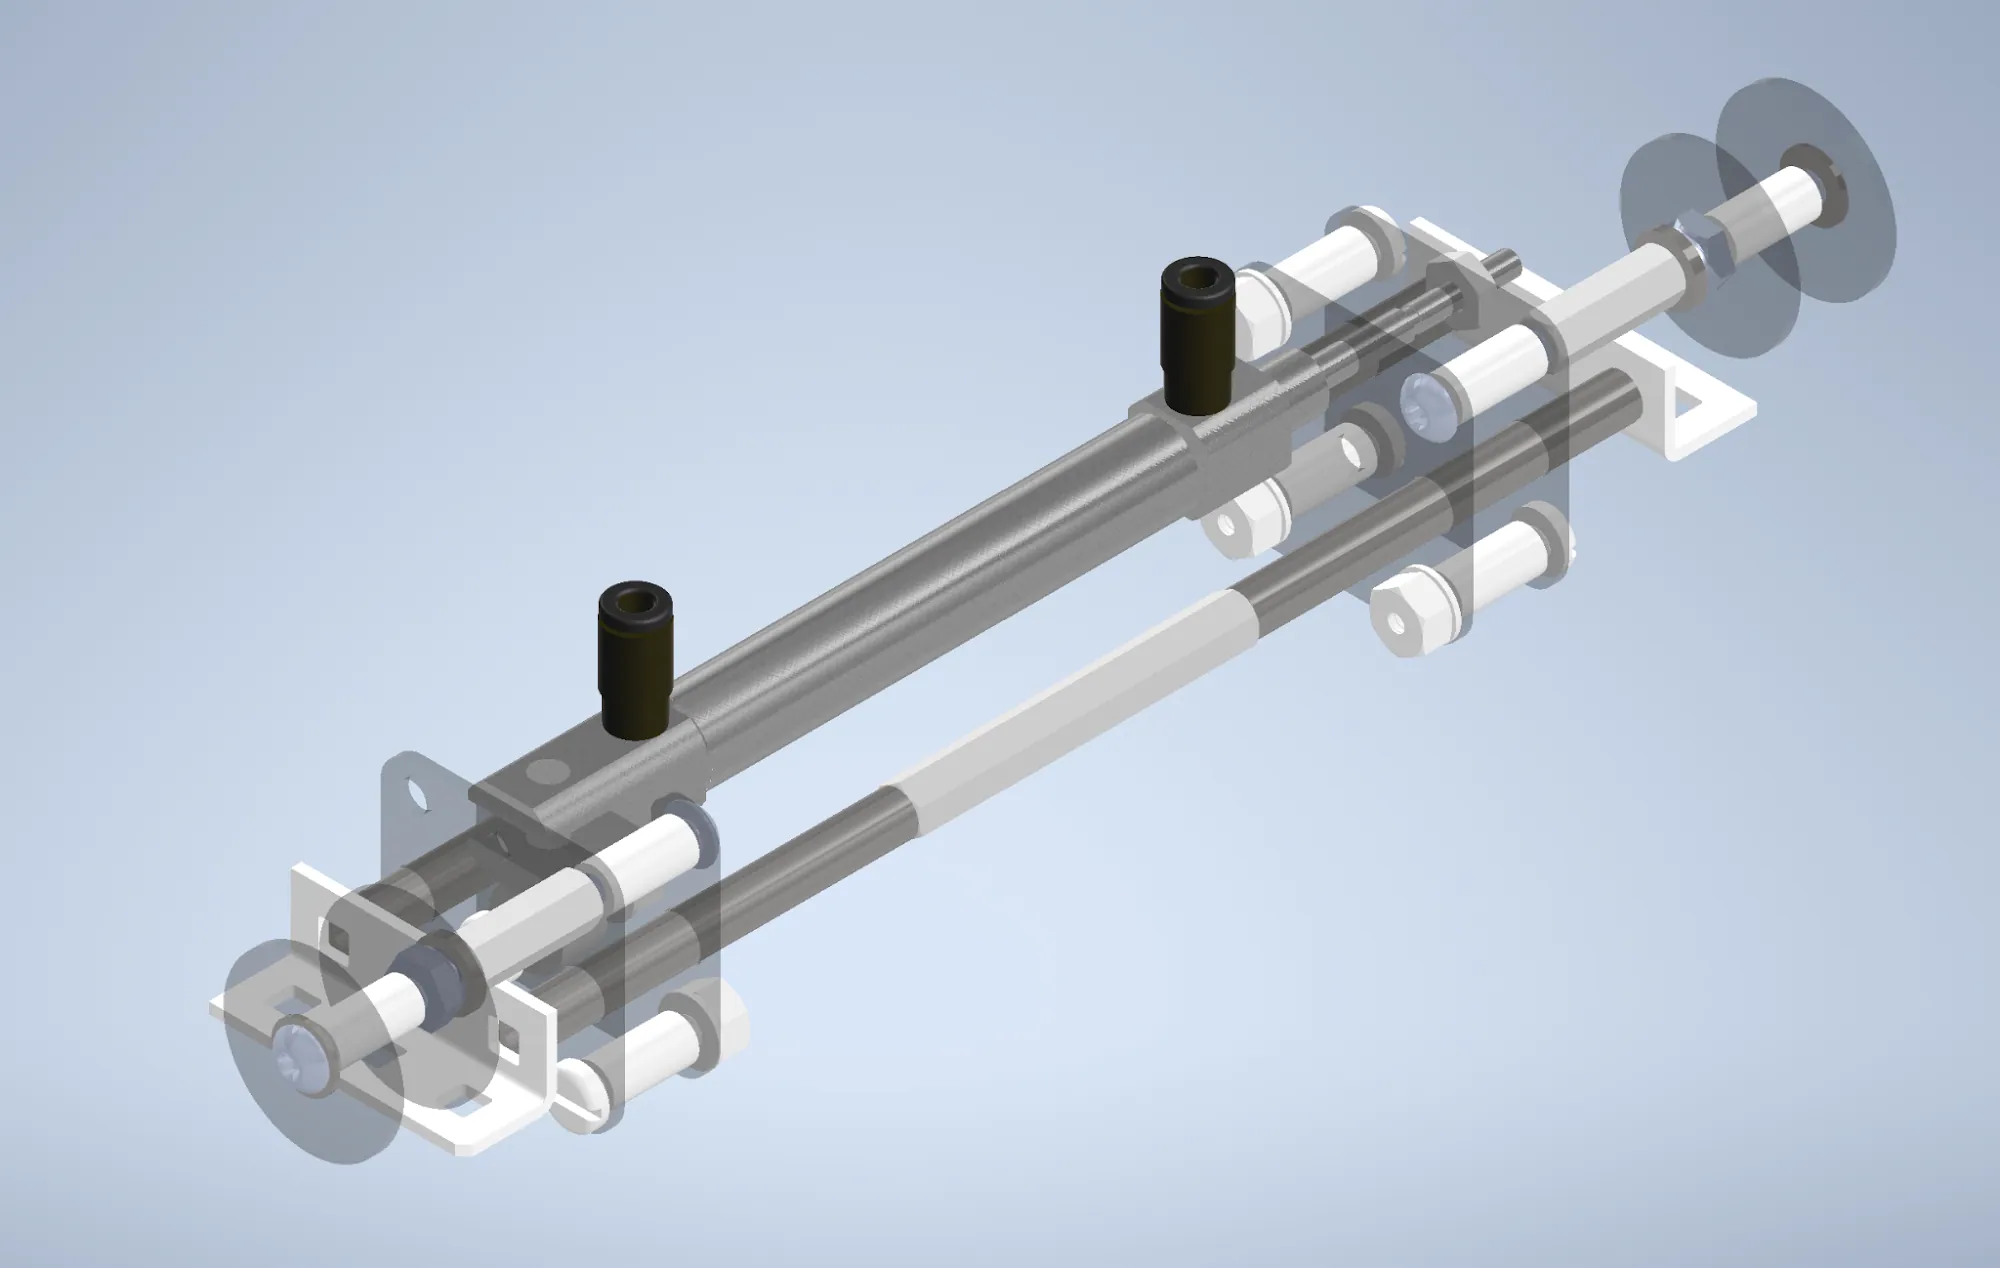
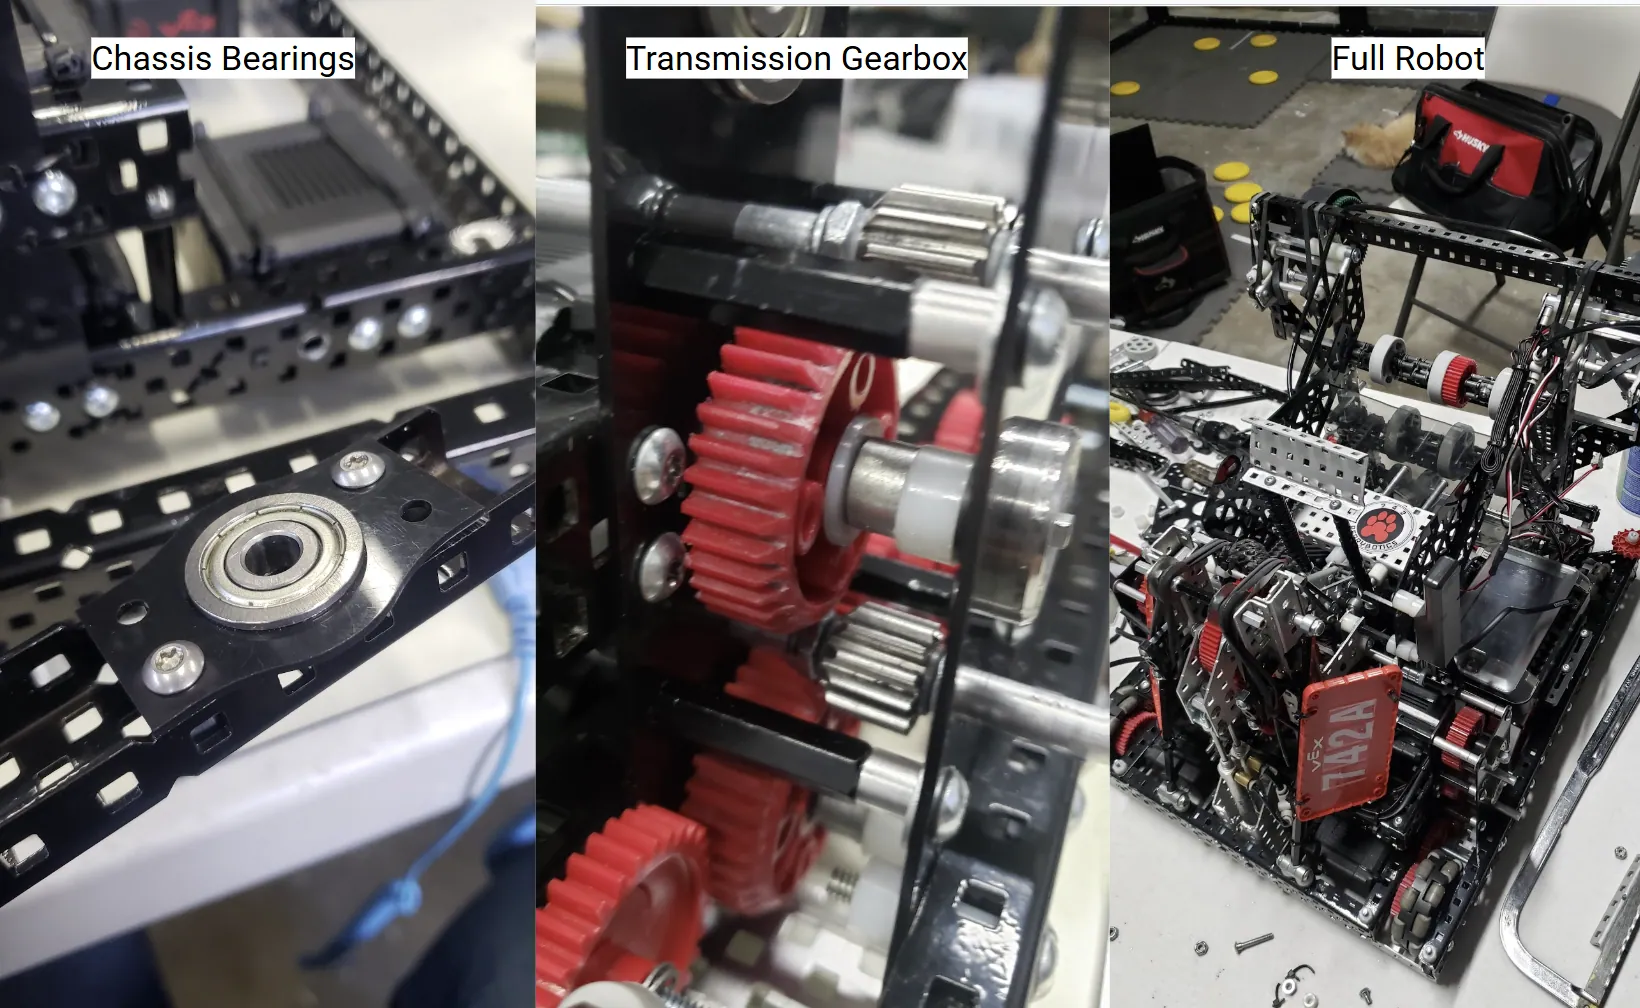
1/2" × 1" aluminum tube, gusseted and riveted. Traction wheels inside, omni on the corners, 1:1 so drive power survives a wheel lifting. Climbs 3" obstacles. Catapult gearbox runs 1:5 with triple slip rings, up to 60 shots per minute.
Building both robots identically was deliberate: one tuning process, one spares kit, one strategy across the alliance.
2023 · Spin Up
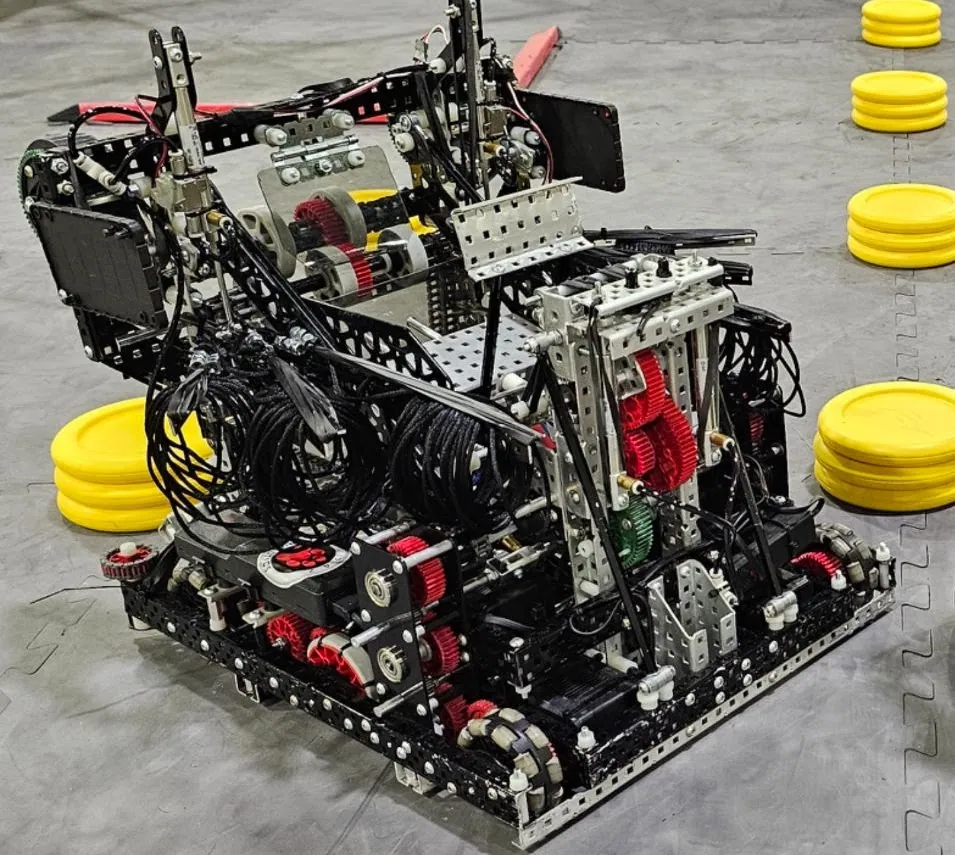
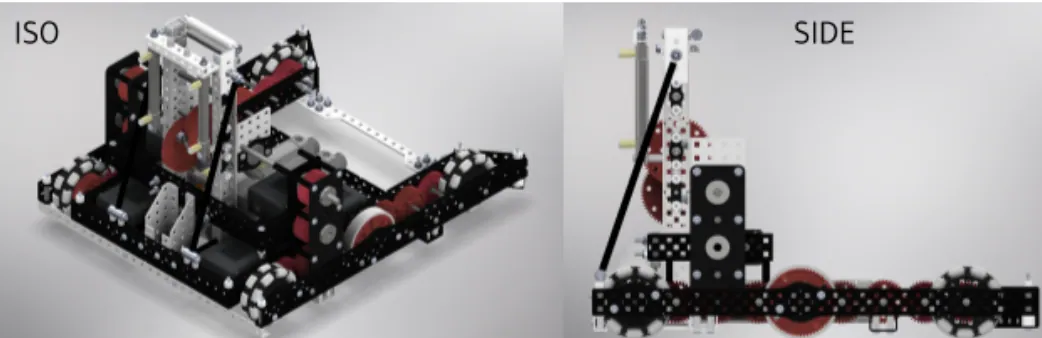
A flat catapult with 10 ft range launching three discs, fed by a dual-piston pneumatic transmission that reallocates two motors between drivetrain and intake, switching between 6-motor (66 W) and 8-motor (88 W) drive at 7.19 ft/s.
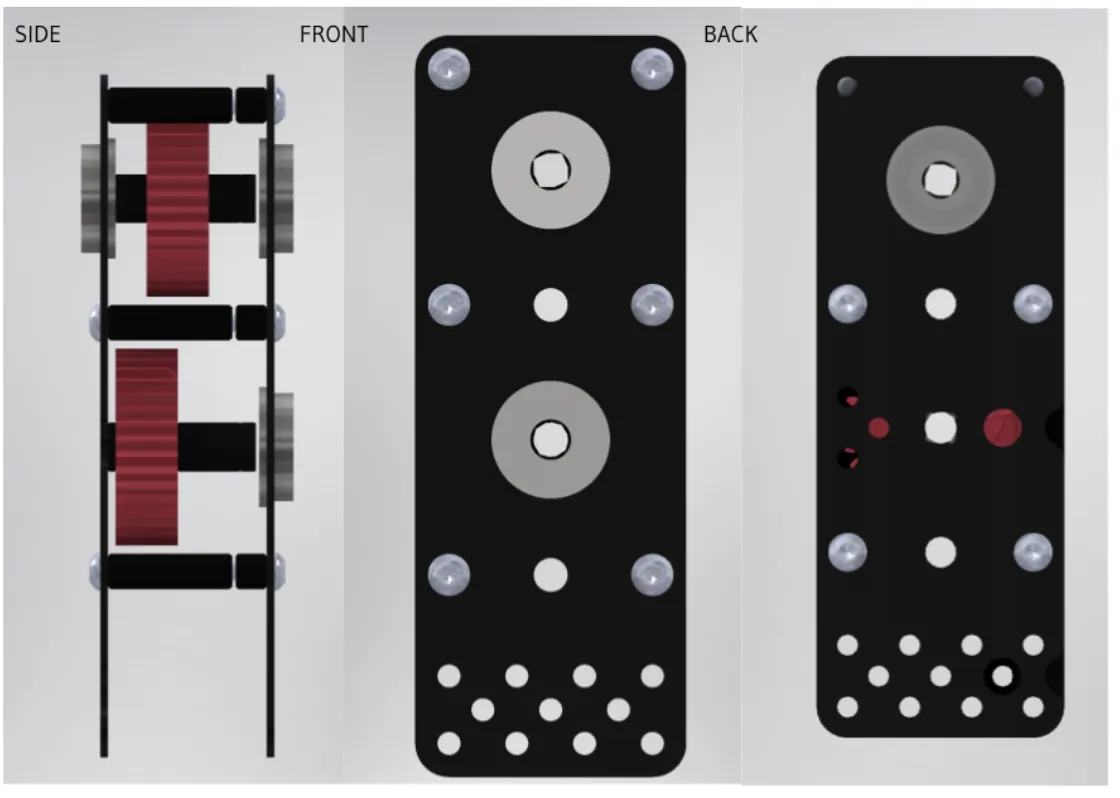
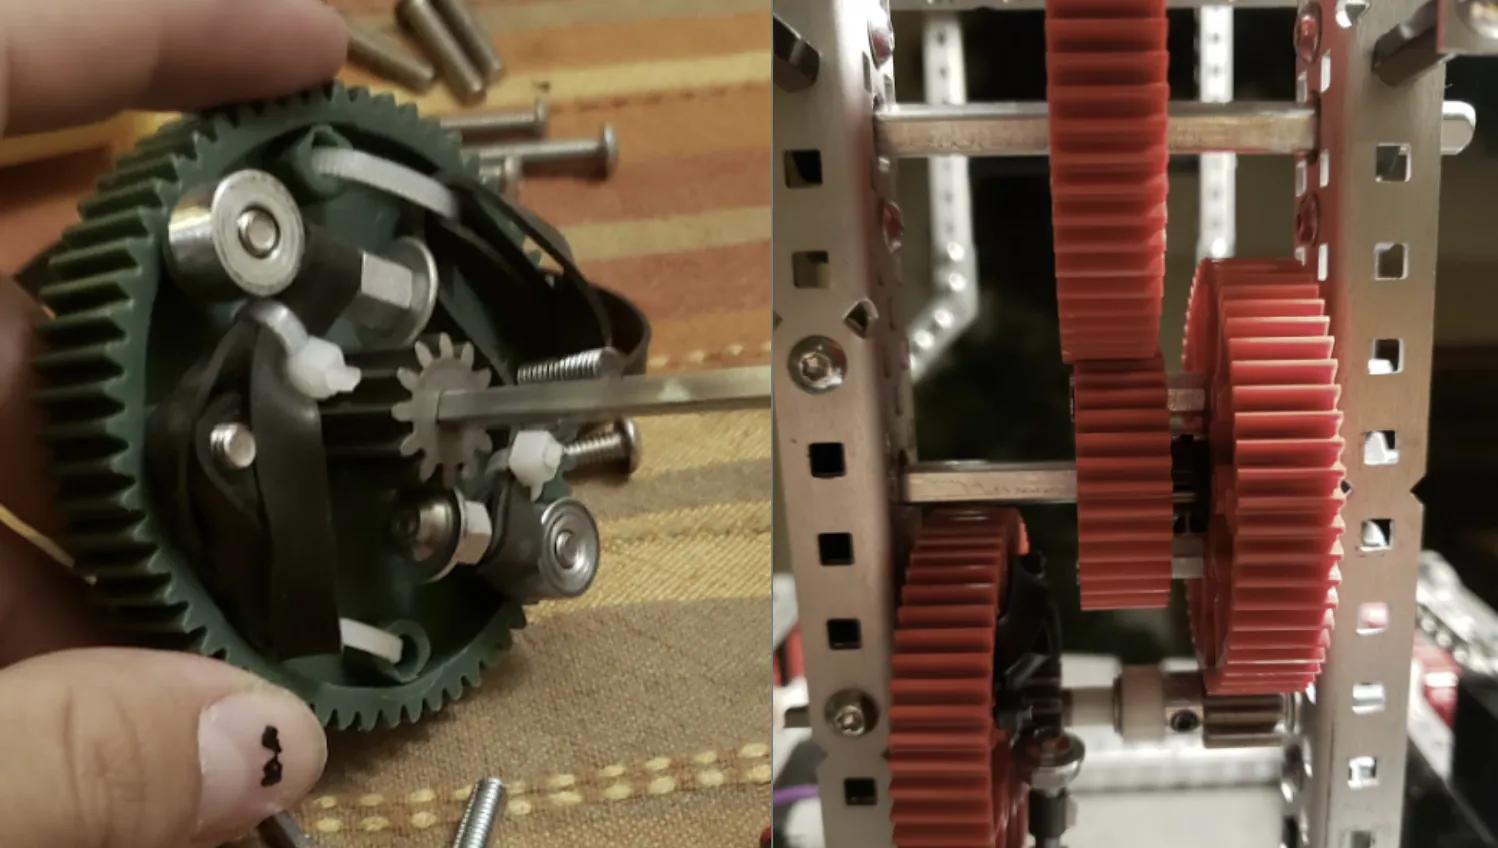
Each side carries a Delrin gearbox: a motor-driven 36T gear meshing two shifting 12T pinions above and below. Pistons shift in counter-unison, so the two motors either drive wheels or drive the ratchet-catapult-intake. Teeth are chamfered to slip into mesh under load.
A compound ratio with a slip gear winds the rubber-band catapult back to a limit switch, then releases when the teeth slip. One ratchet prevents early fire, a second lets the motors reverse into the intake. Three virtual iterations, two builds. Won California State and Nationals.
2022 · Tipping Point
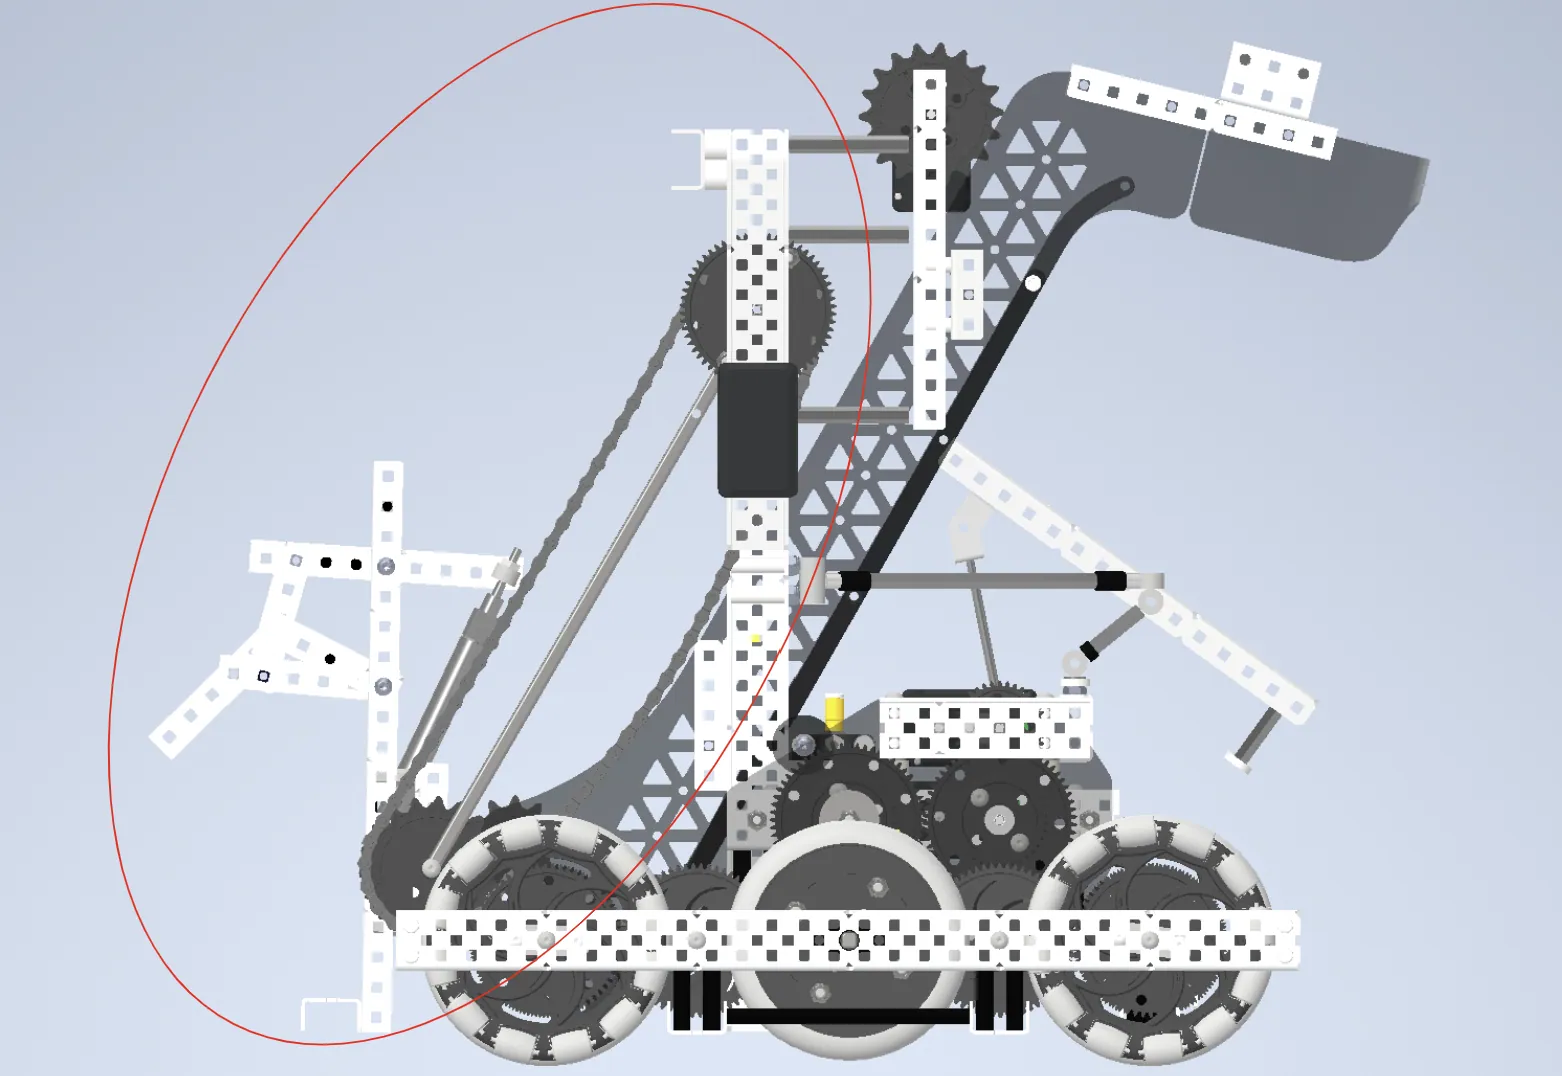
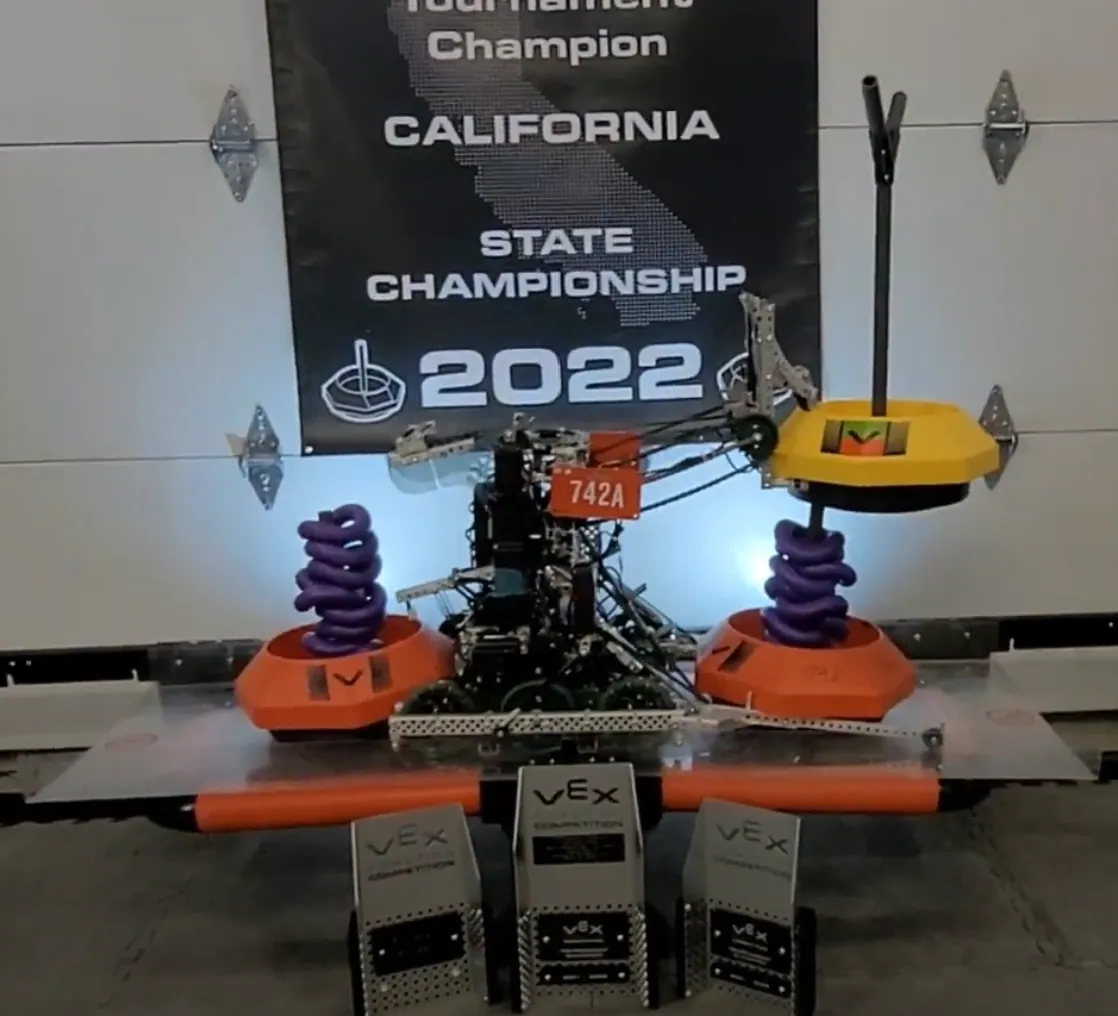
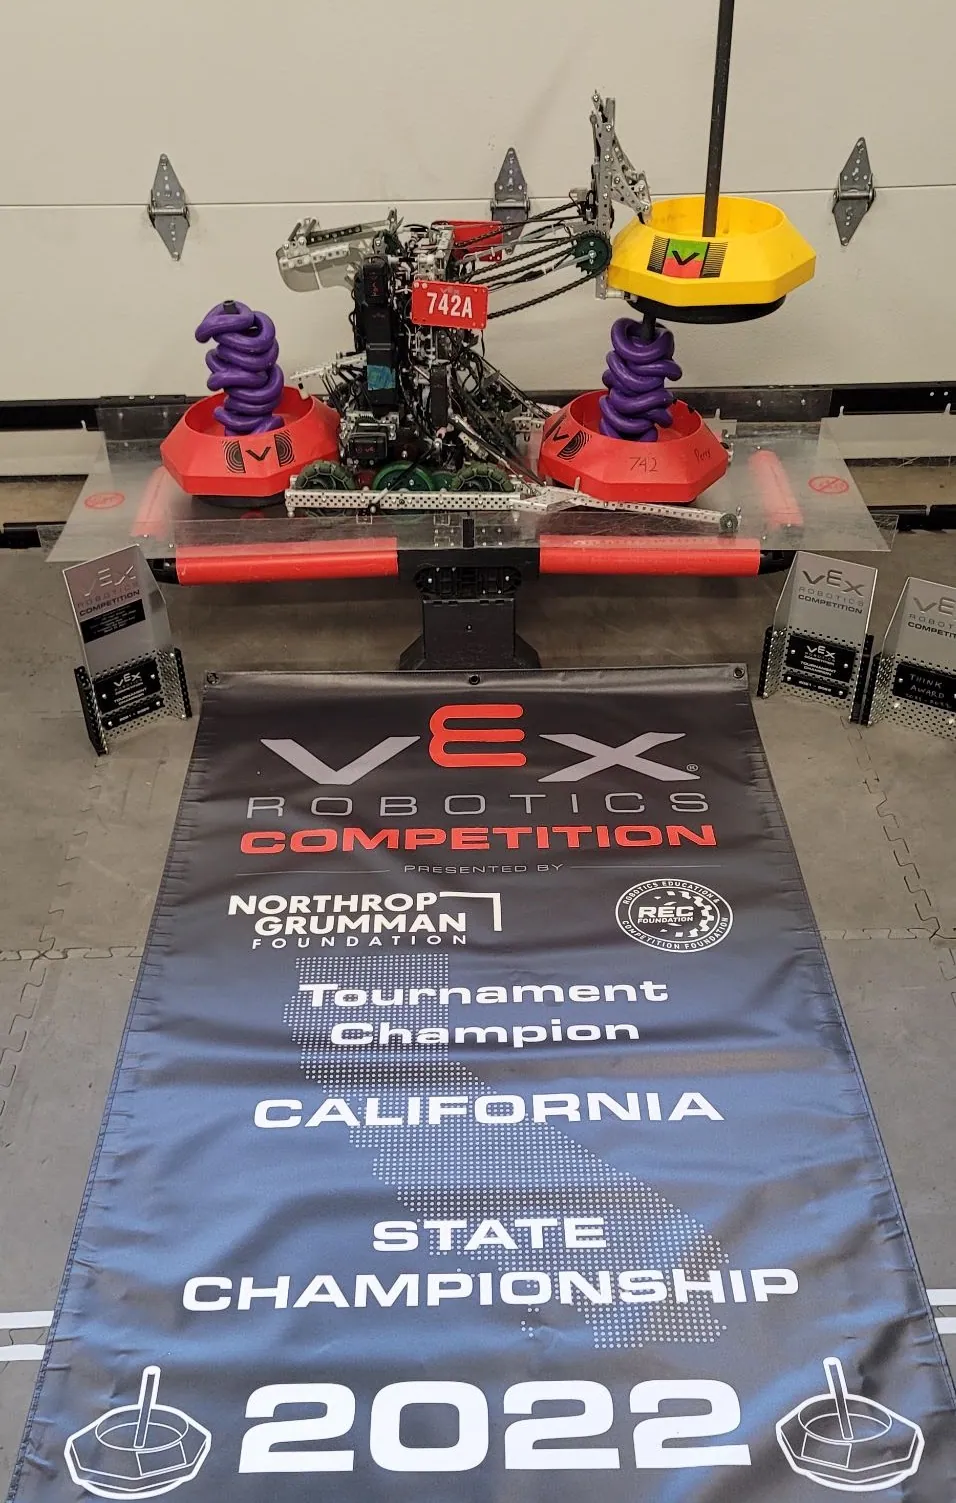
A 15 lb robot scoring rings, manipulating mobile goals, and climbing the platform. Six-wheel, 6-motor drive with a dual-speed pneumatic transmission shifting between ~200 rpm torque and ~333 rpm speed via a 36T–60T compound pair. The center wheel sits slightly oversized and traction-treaded so the robot pivots about its midpoint.
A single-motor chain lift in lightweight steel covered a full 90°, chain-balanced to hold the end effector perpendicular throughout. An over-center pneumatic clamp on hand-fabricated aluminum gussets locked onto mobile goals under defensive pressure; a drop-down fork clamp at the base carried three goals at once.
The shifting system was one of the first successful implementations in the VEX community that season. Won California State and the California SkillsUSA Robotics Championship.
Why robotics education
Automation is going to disrupt labor. Robotics education answers it by reaching students early, through something they actually want to do.
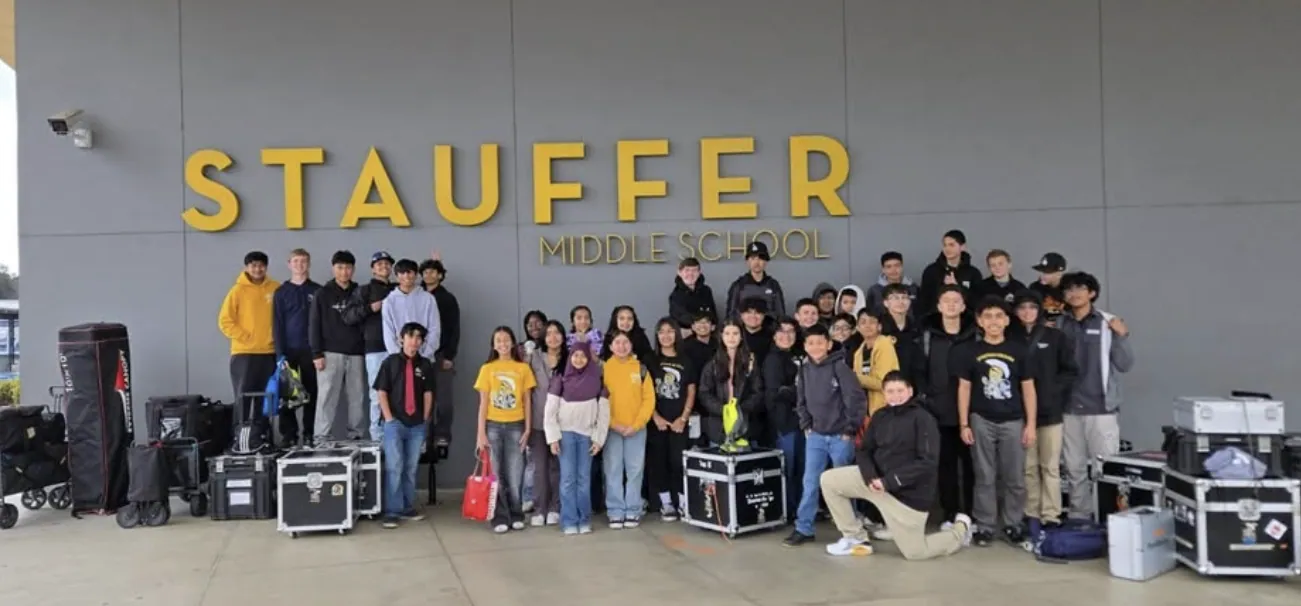
PerryBotics mentors middle schools in the DUSD and TUSD regions annually (200+ students in two years), and volunteers at local championships as judges, scorers, and referees.
Gallery
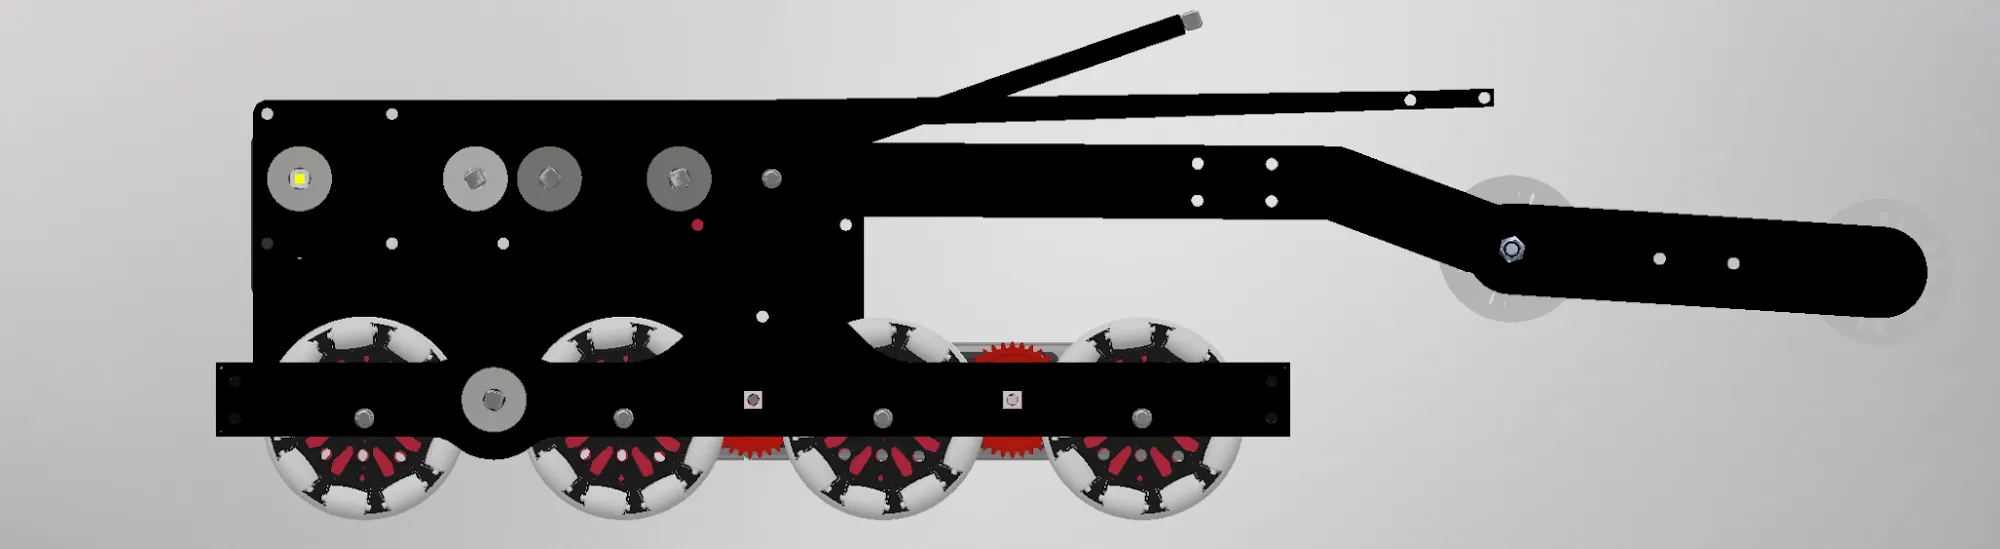
CAD and master sketches
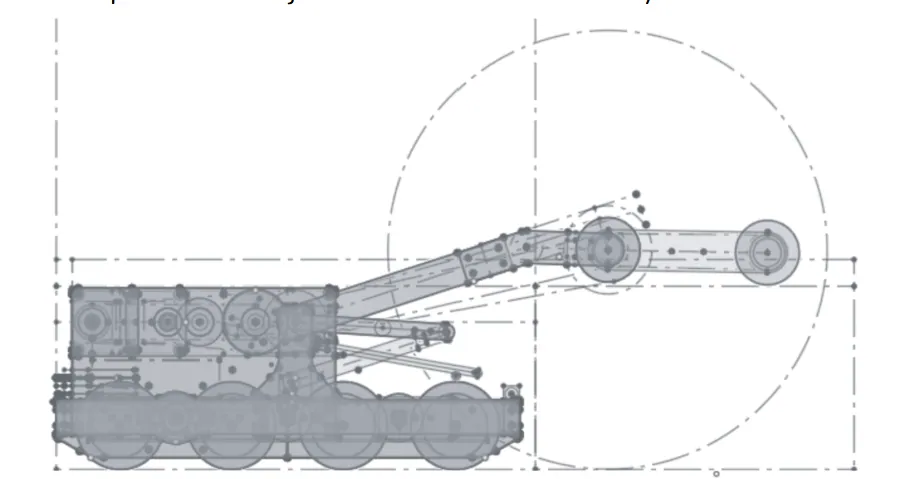
Every robot started as a dimensioned master sketch.
Designing the 2024 robot
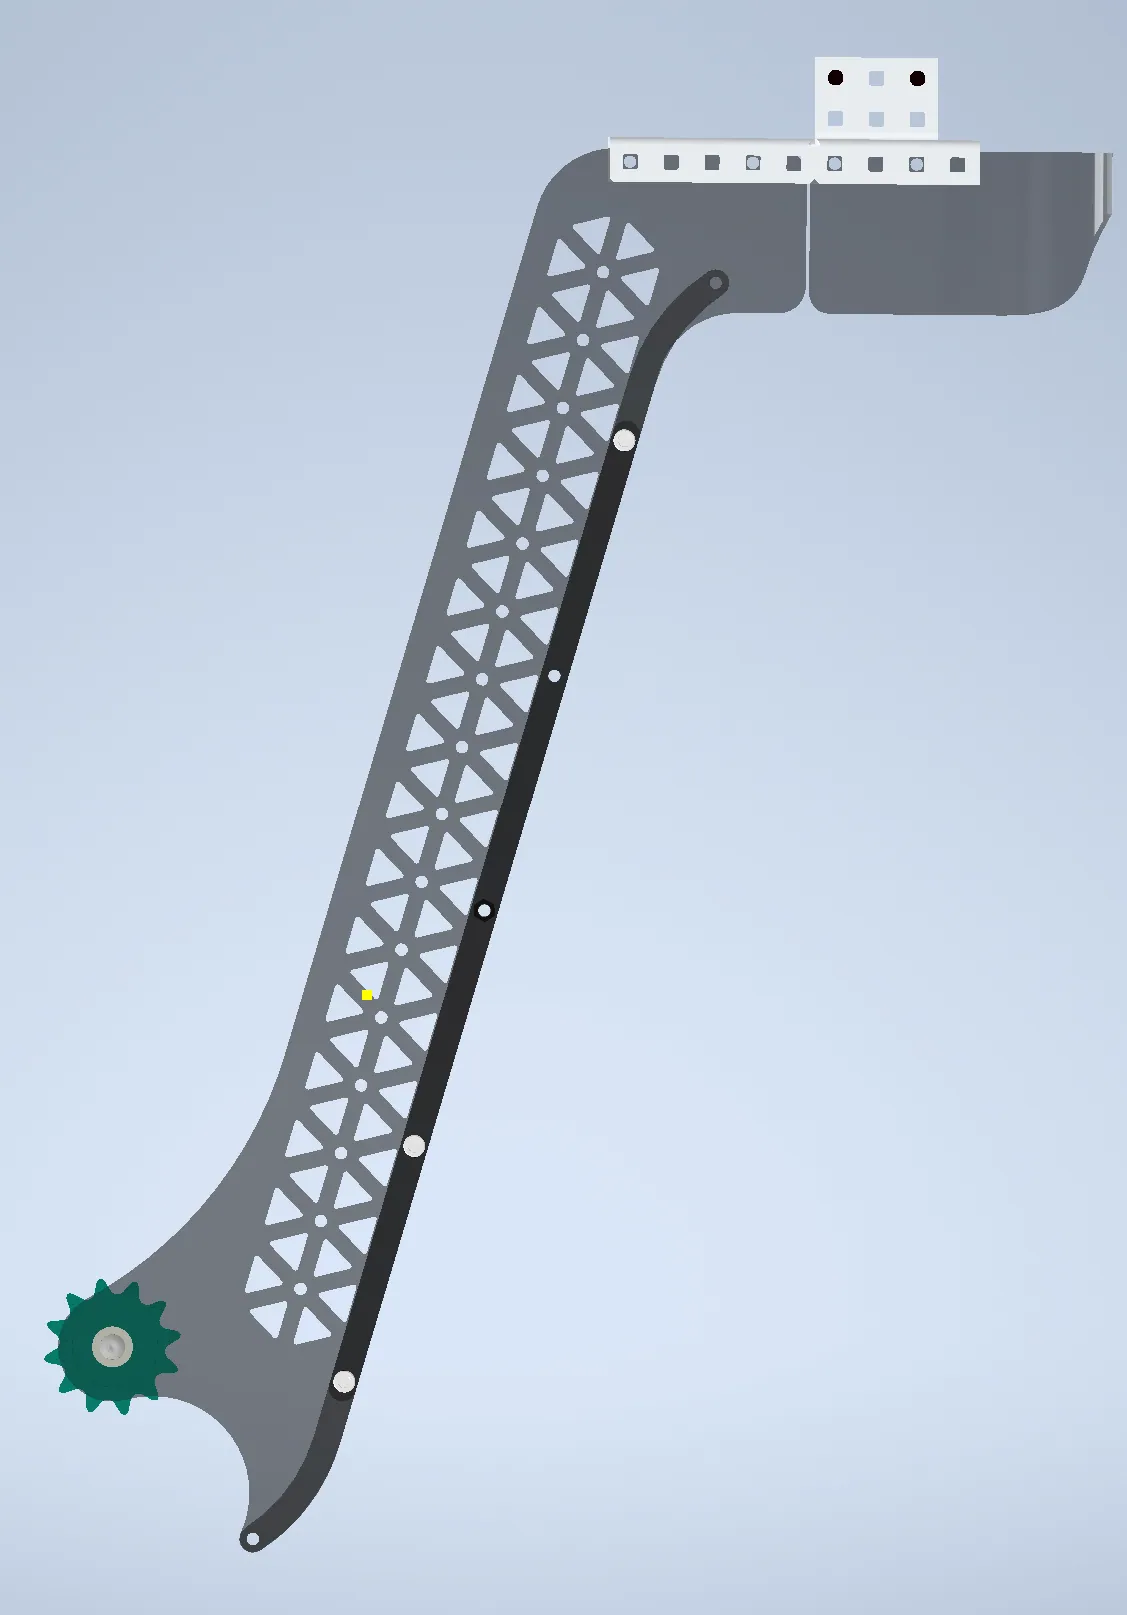
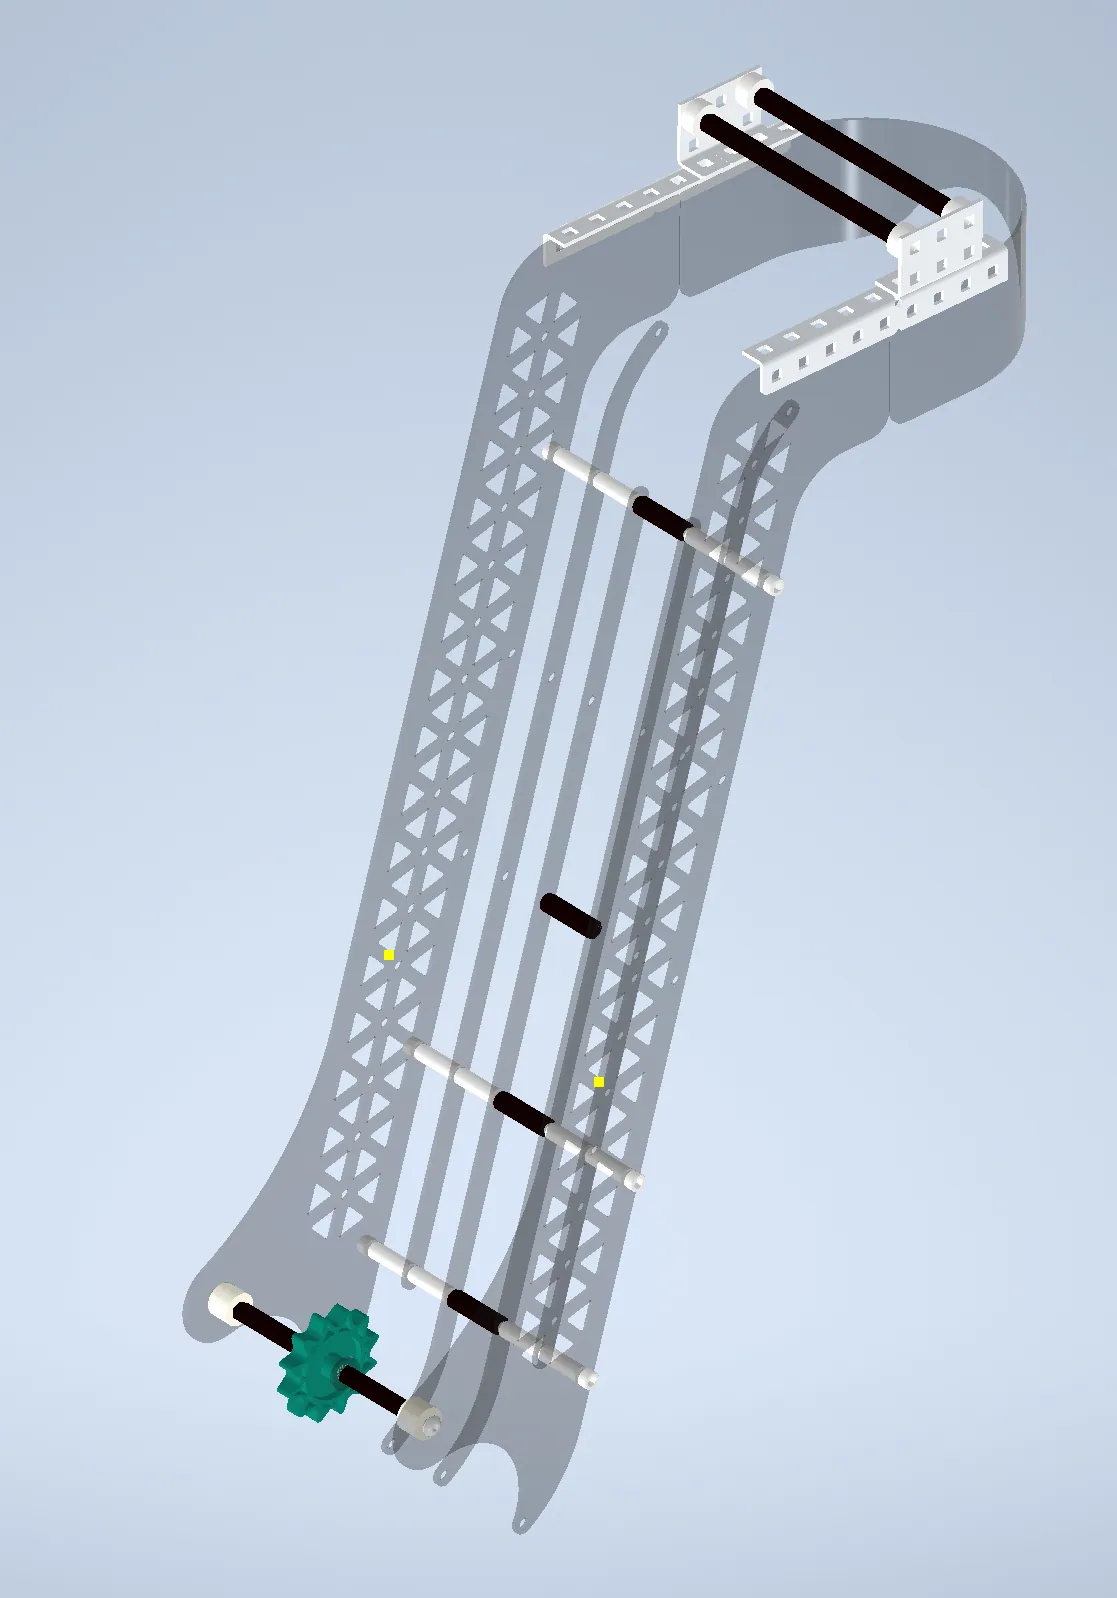
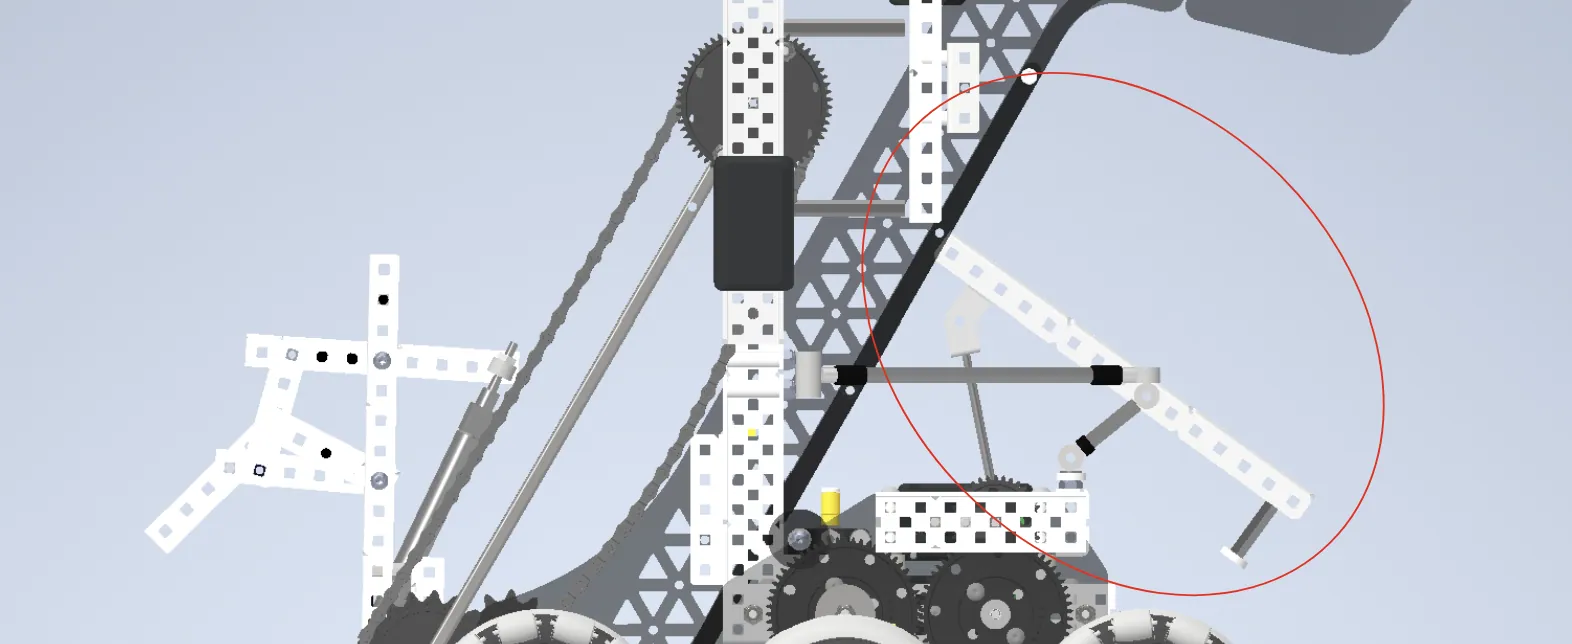
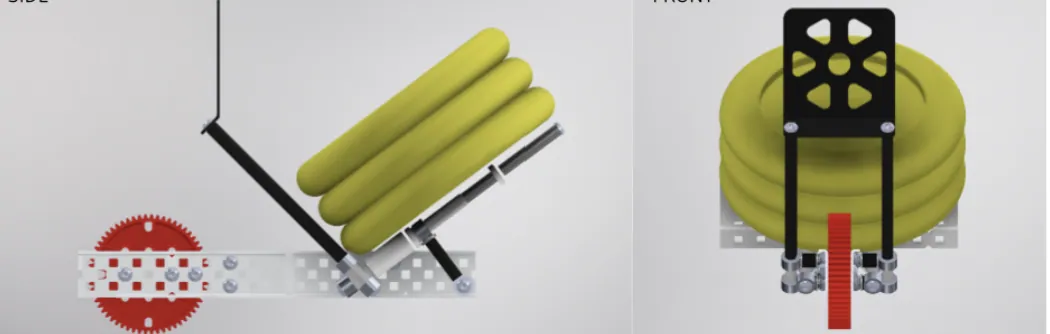
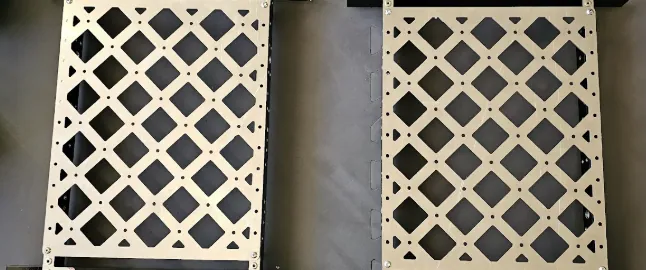
Wings, catapult, and the lattice arms that carry them.
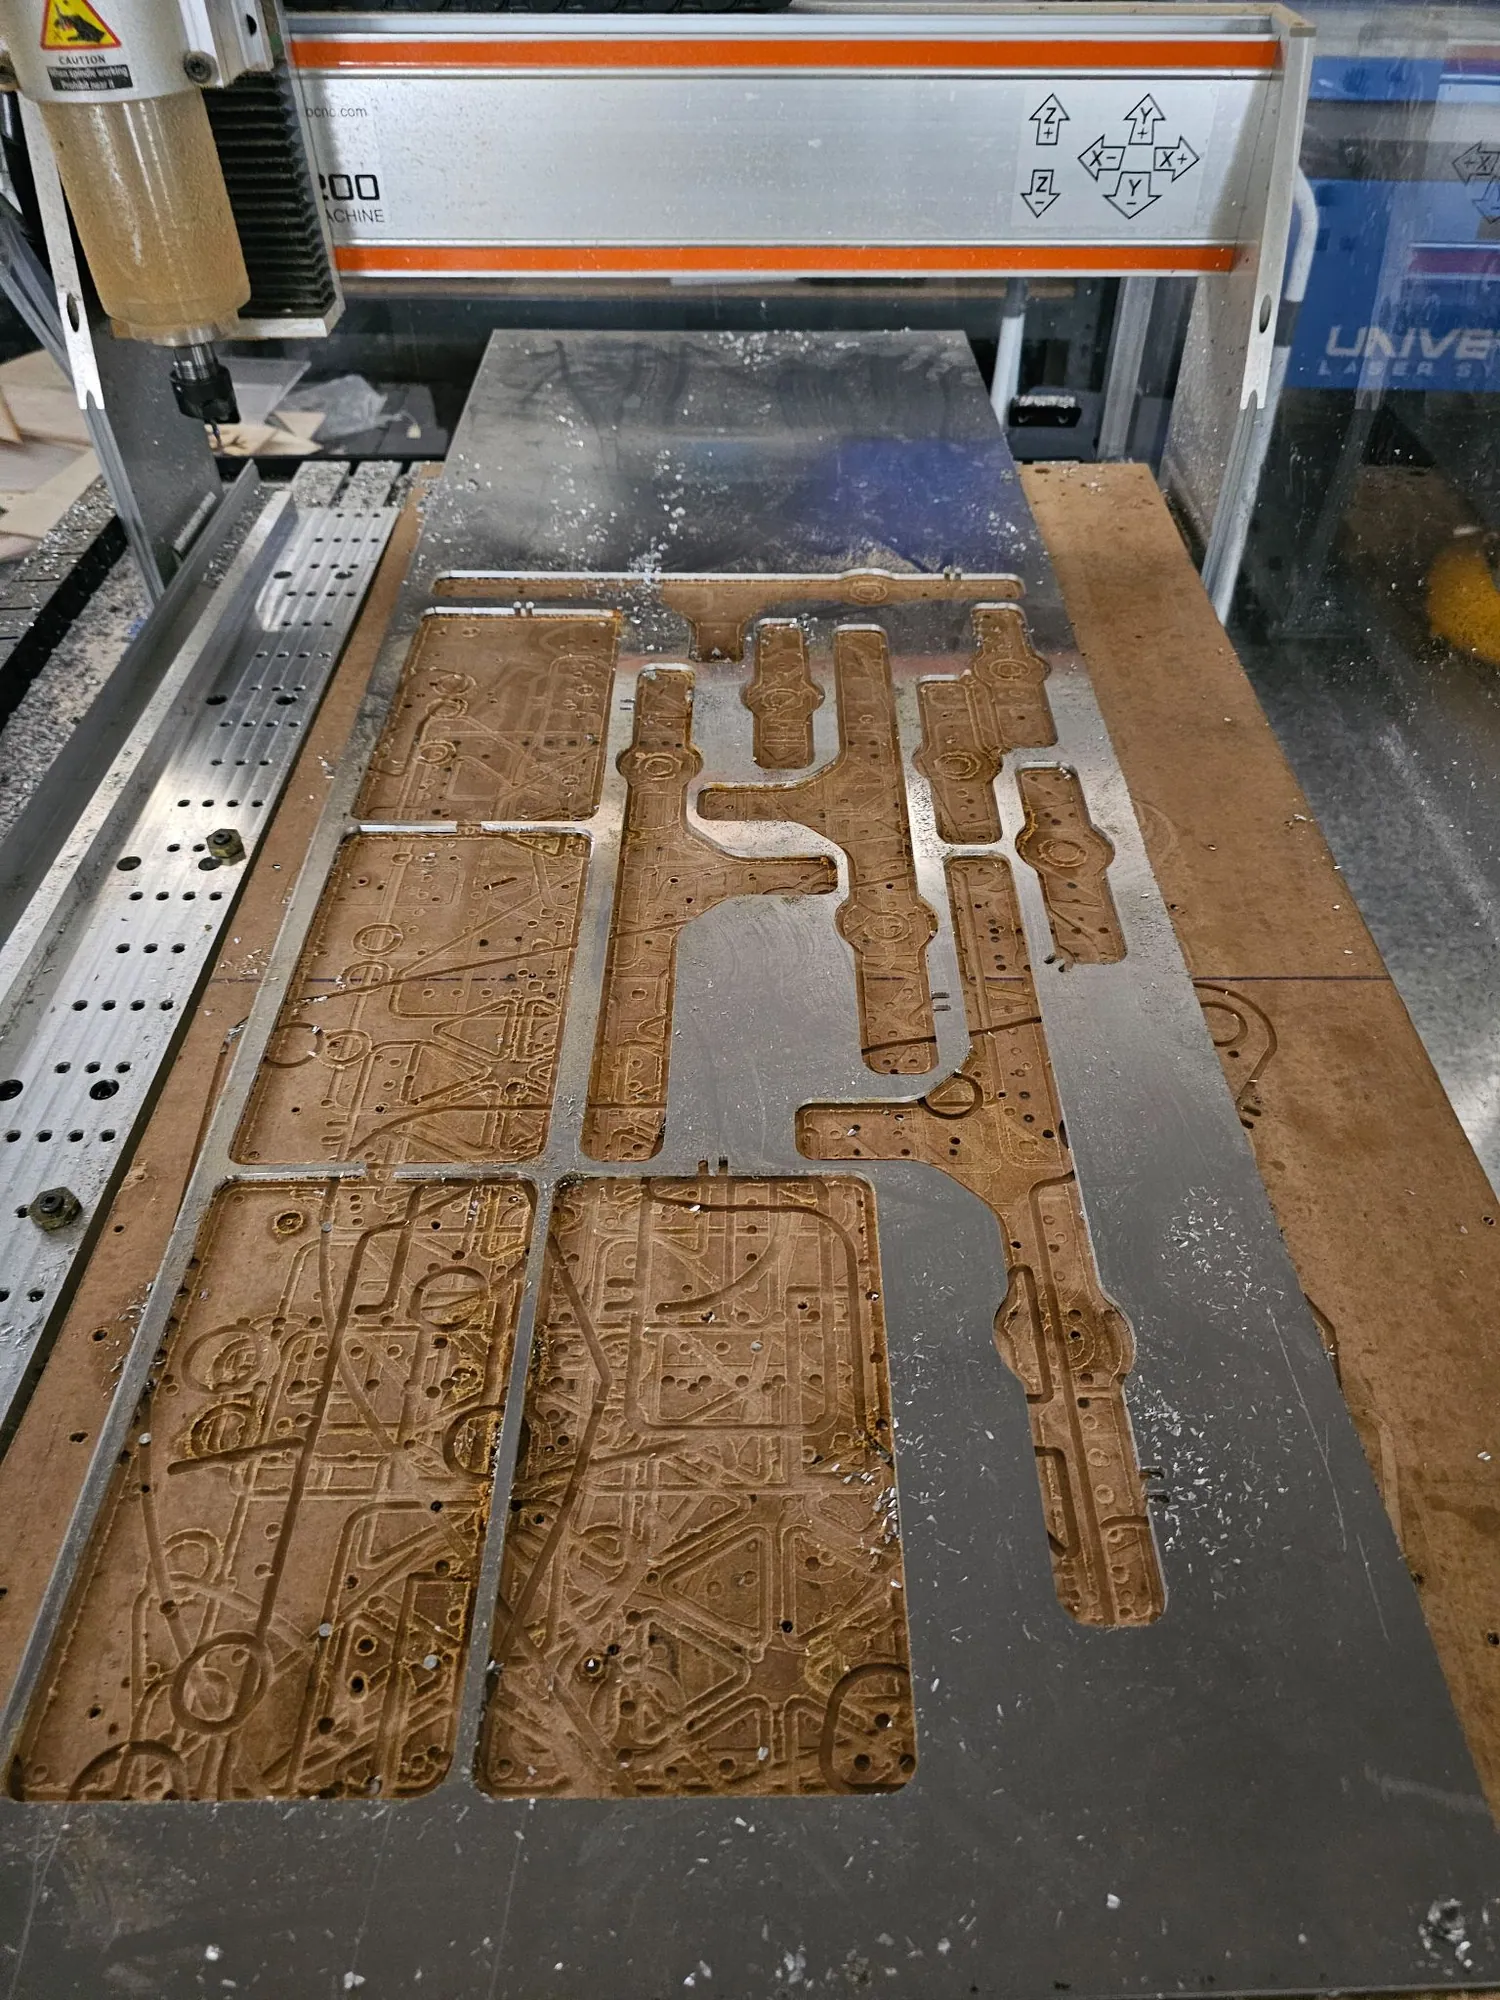
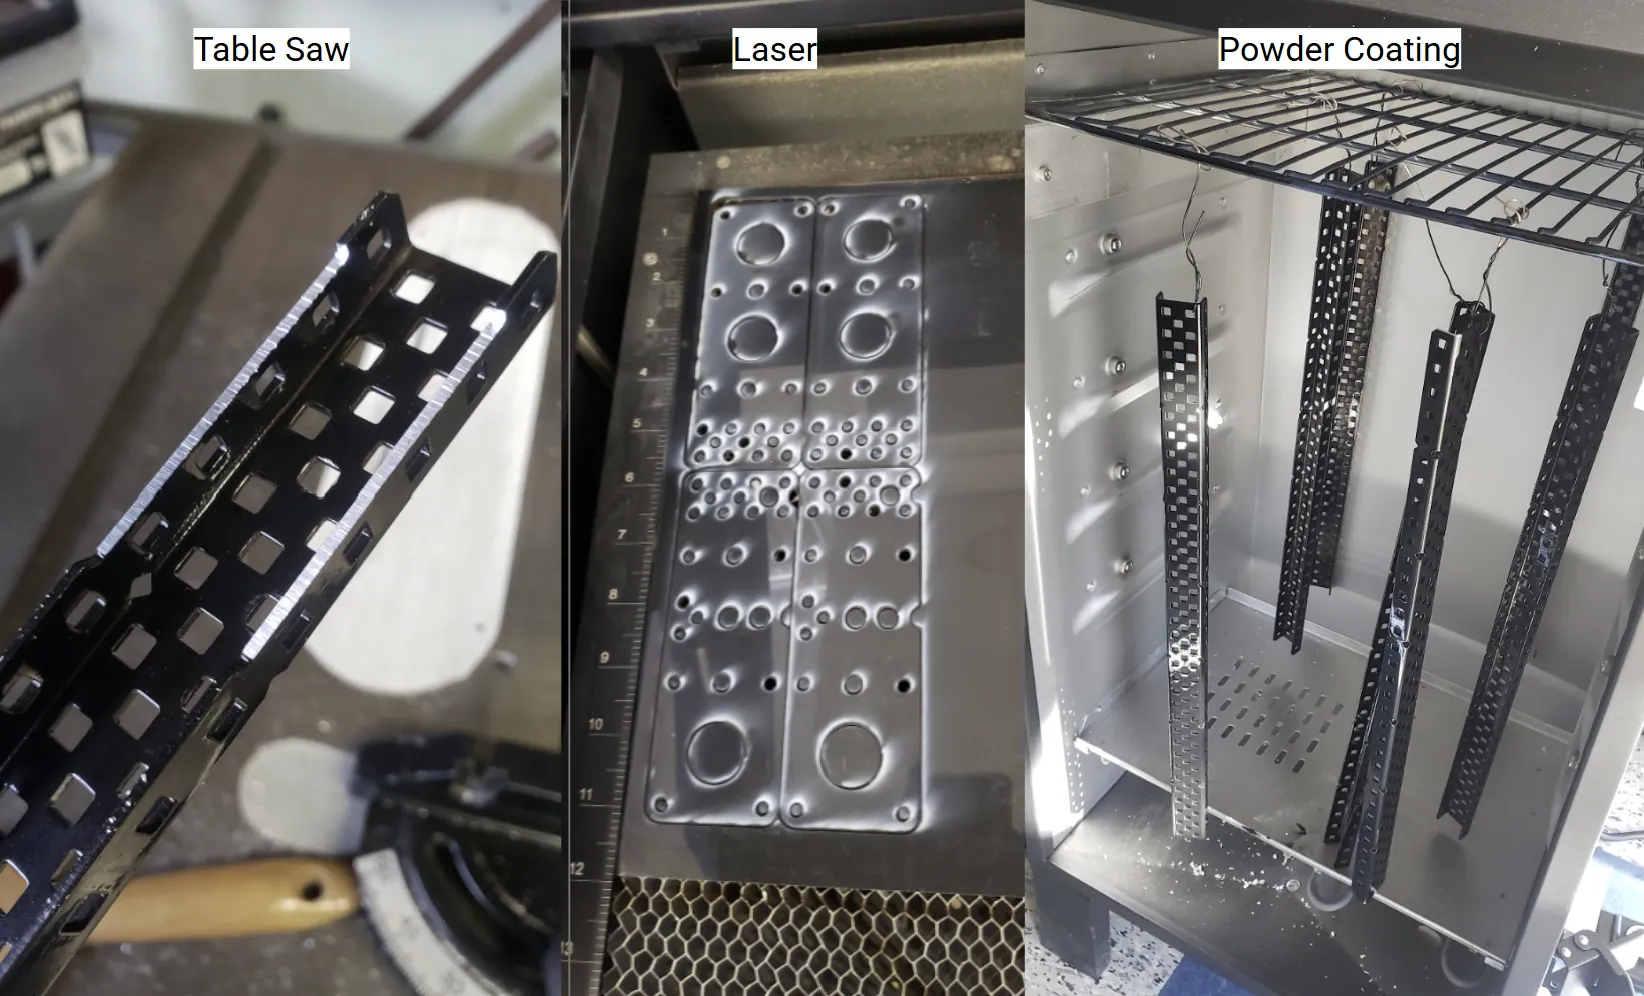
Making the parts
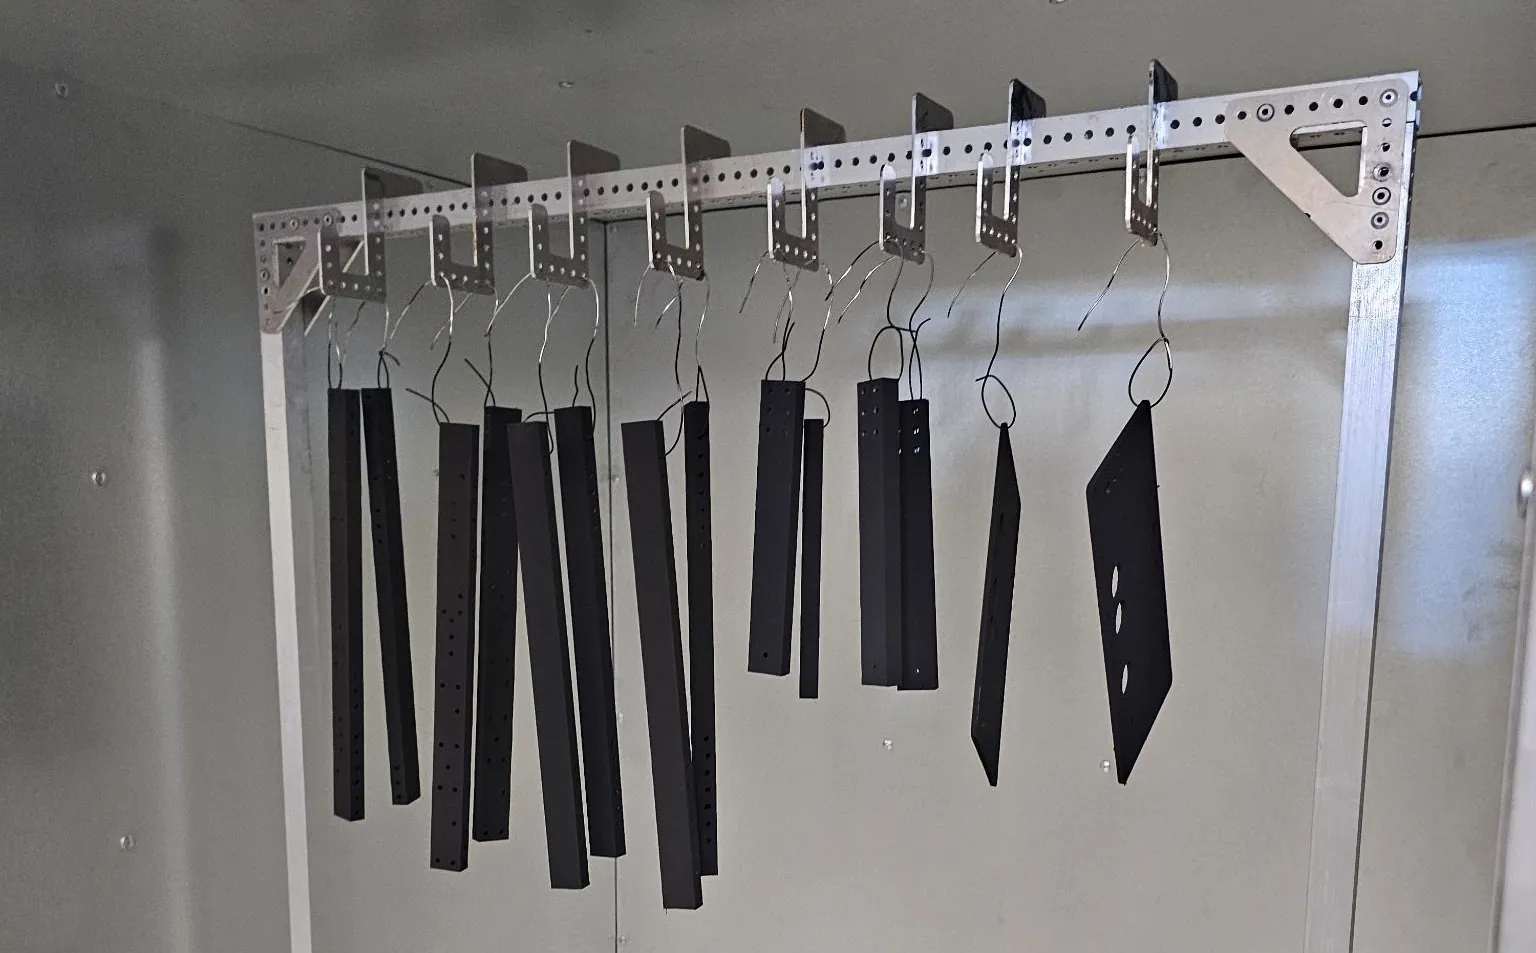
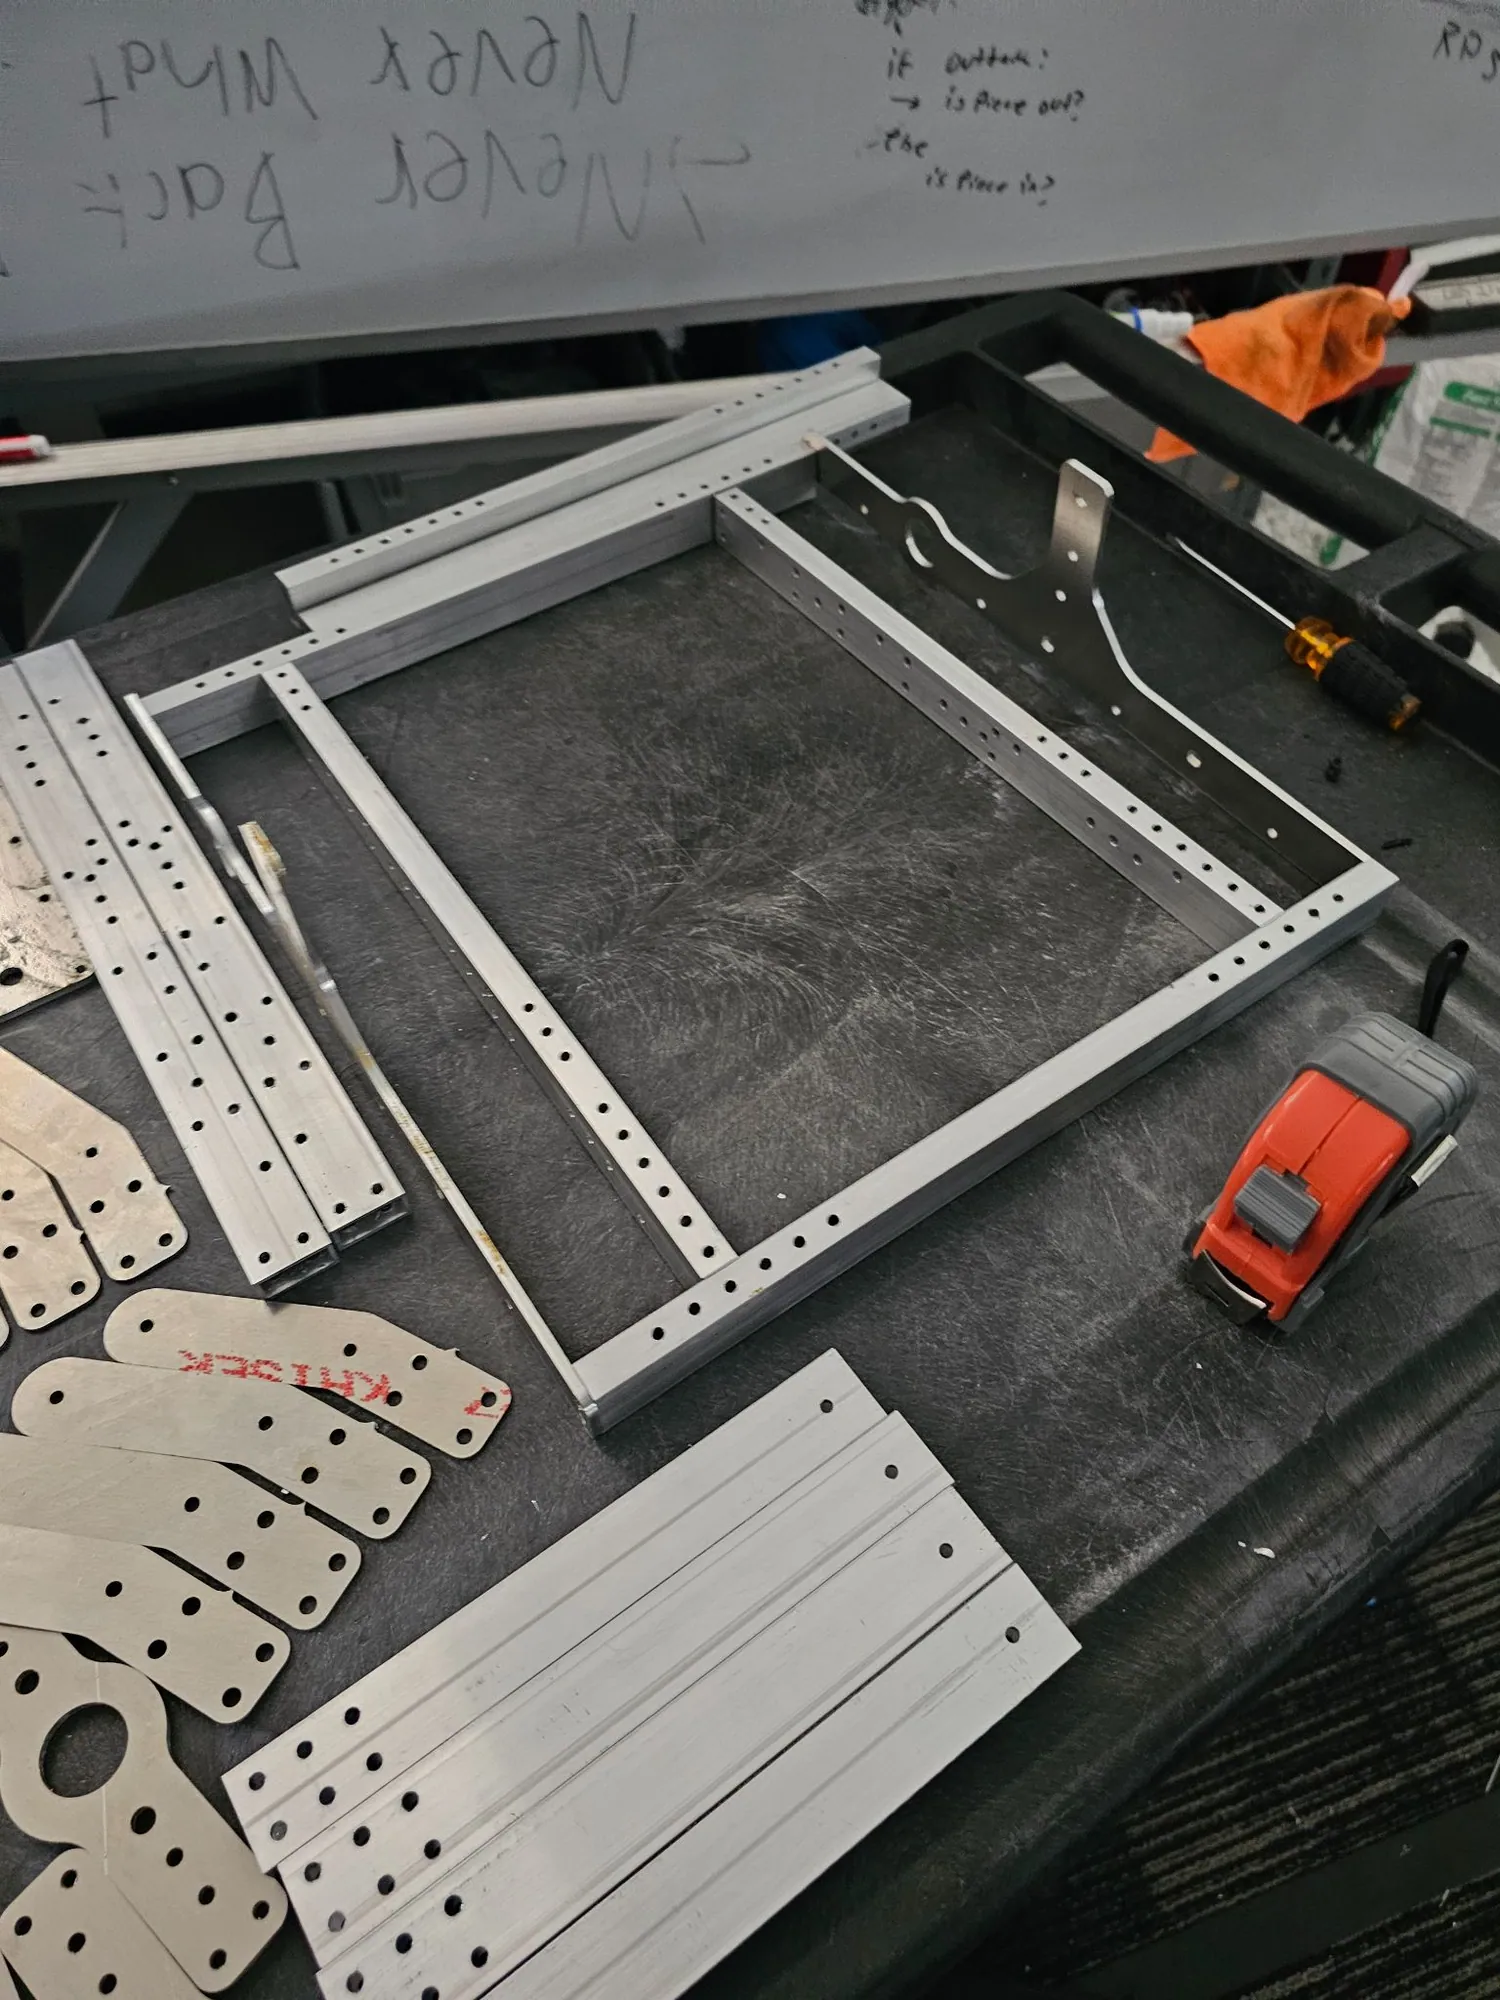
Router, table saw, laser, powder coat, then assembly.
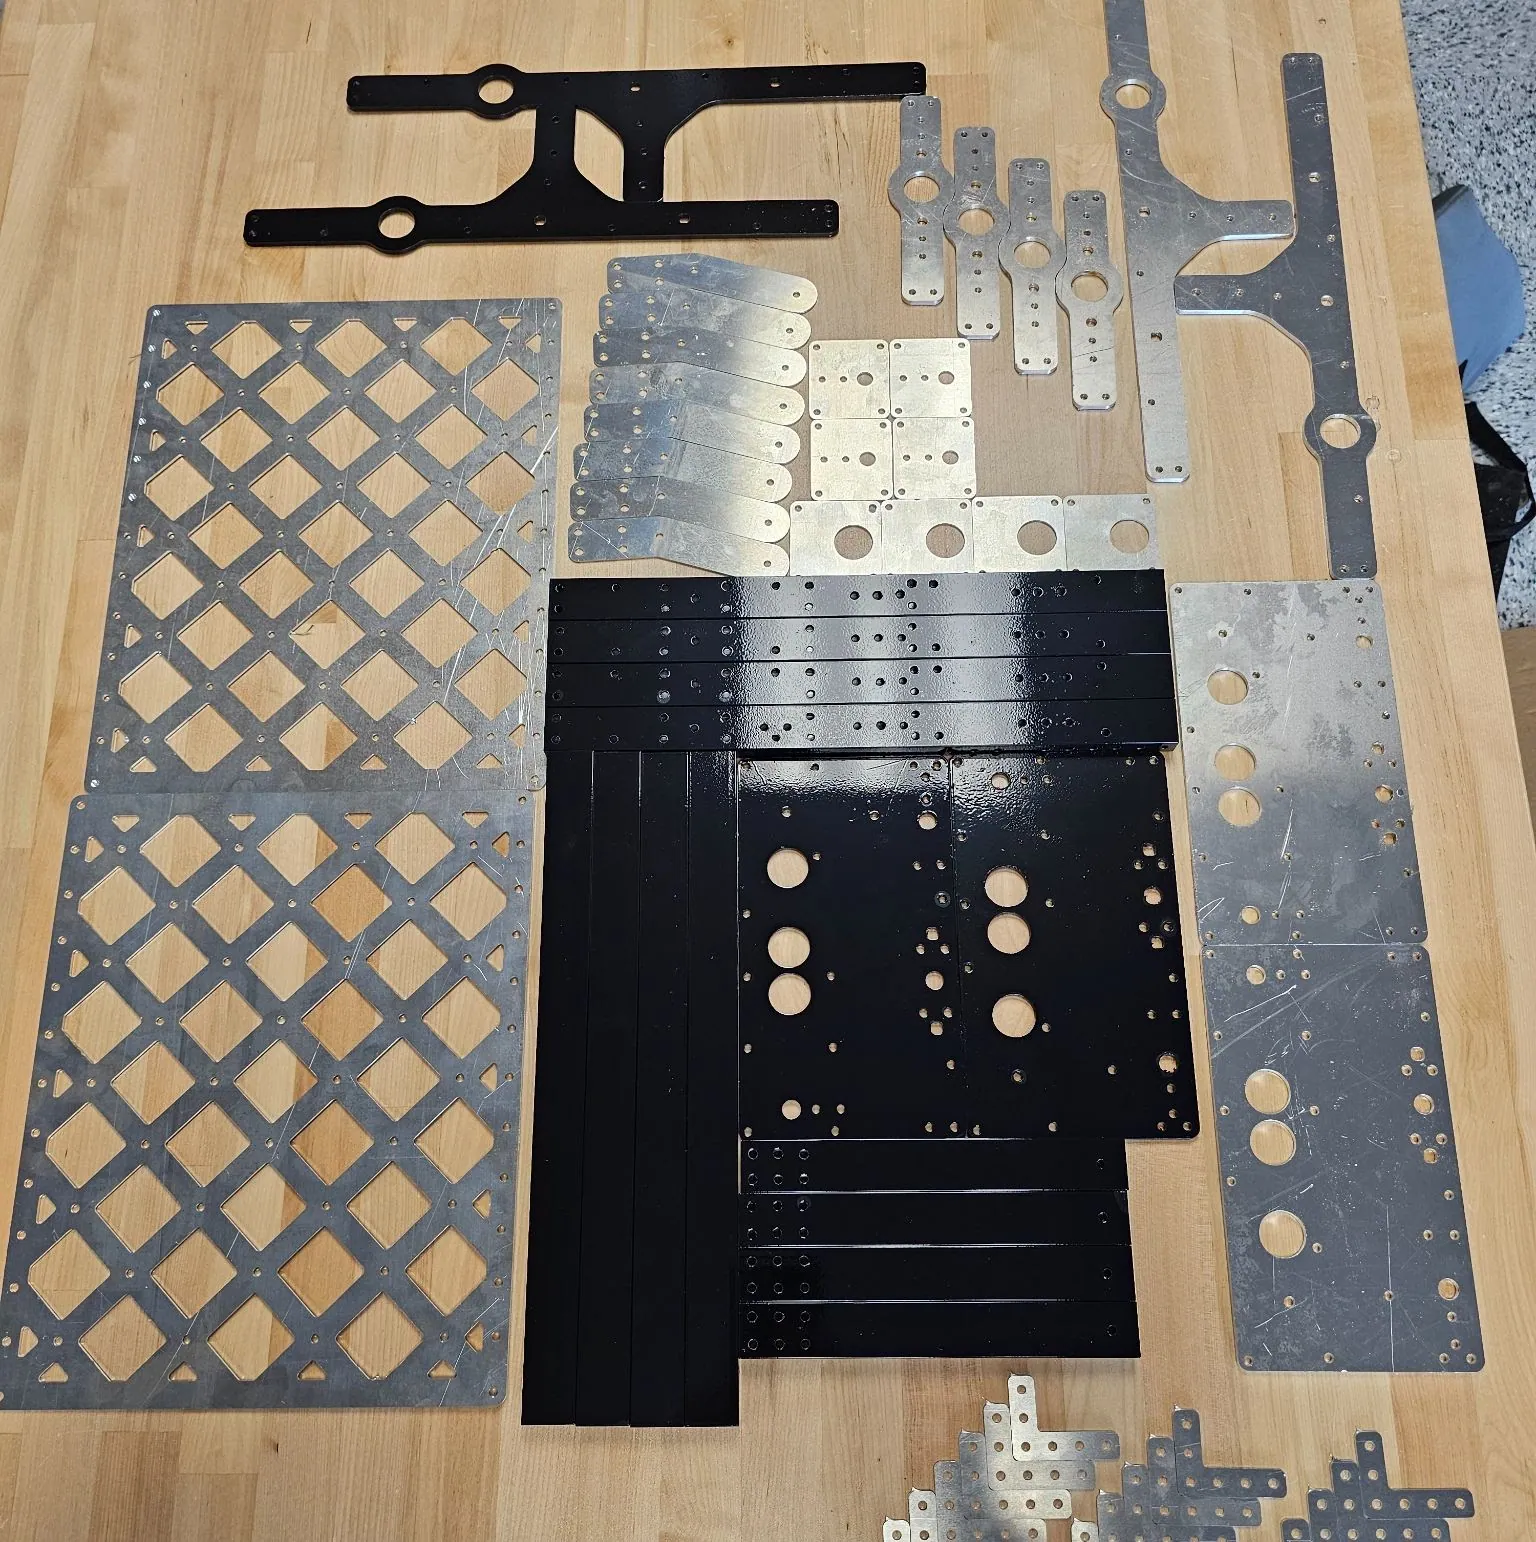
The 2024 robot
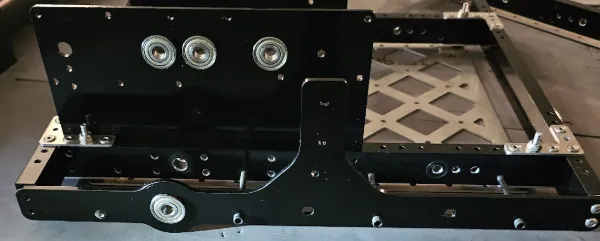
Deck and intake, built.
UC San Diego