Yonder Robotics · 2025
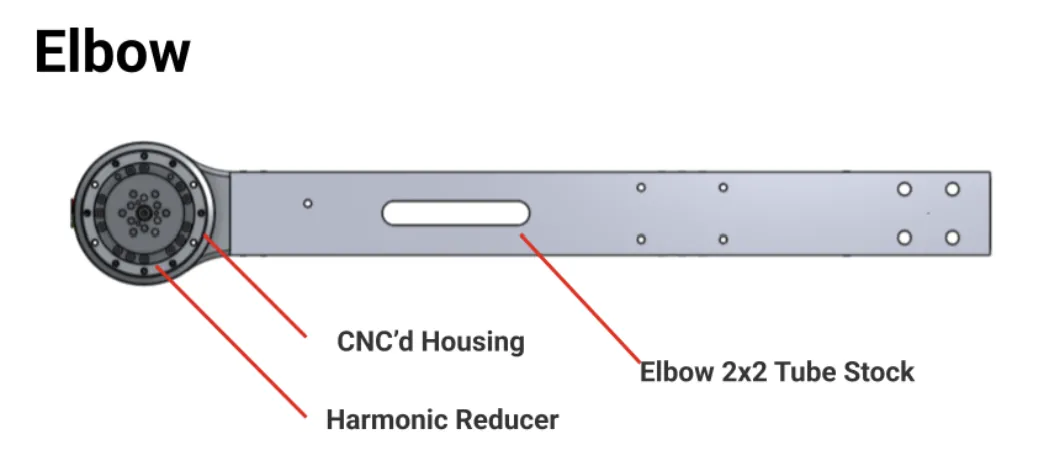
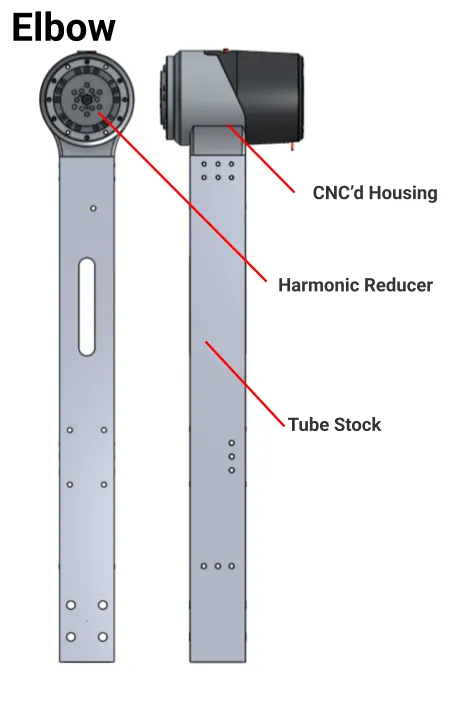
Elbow
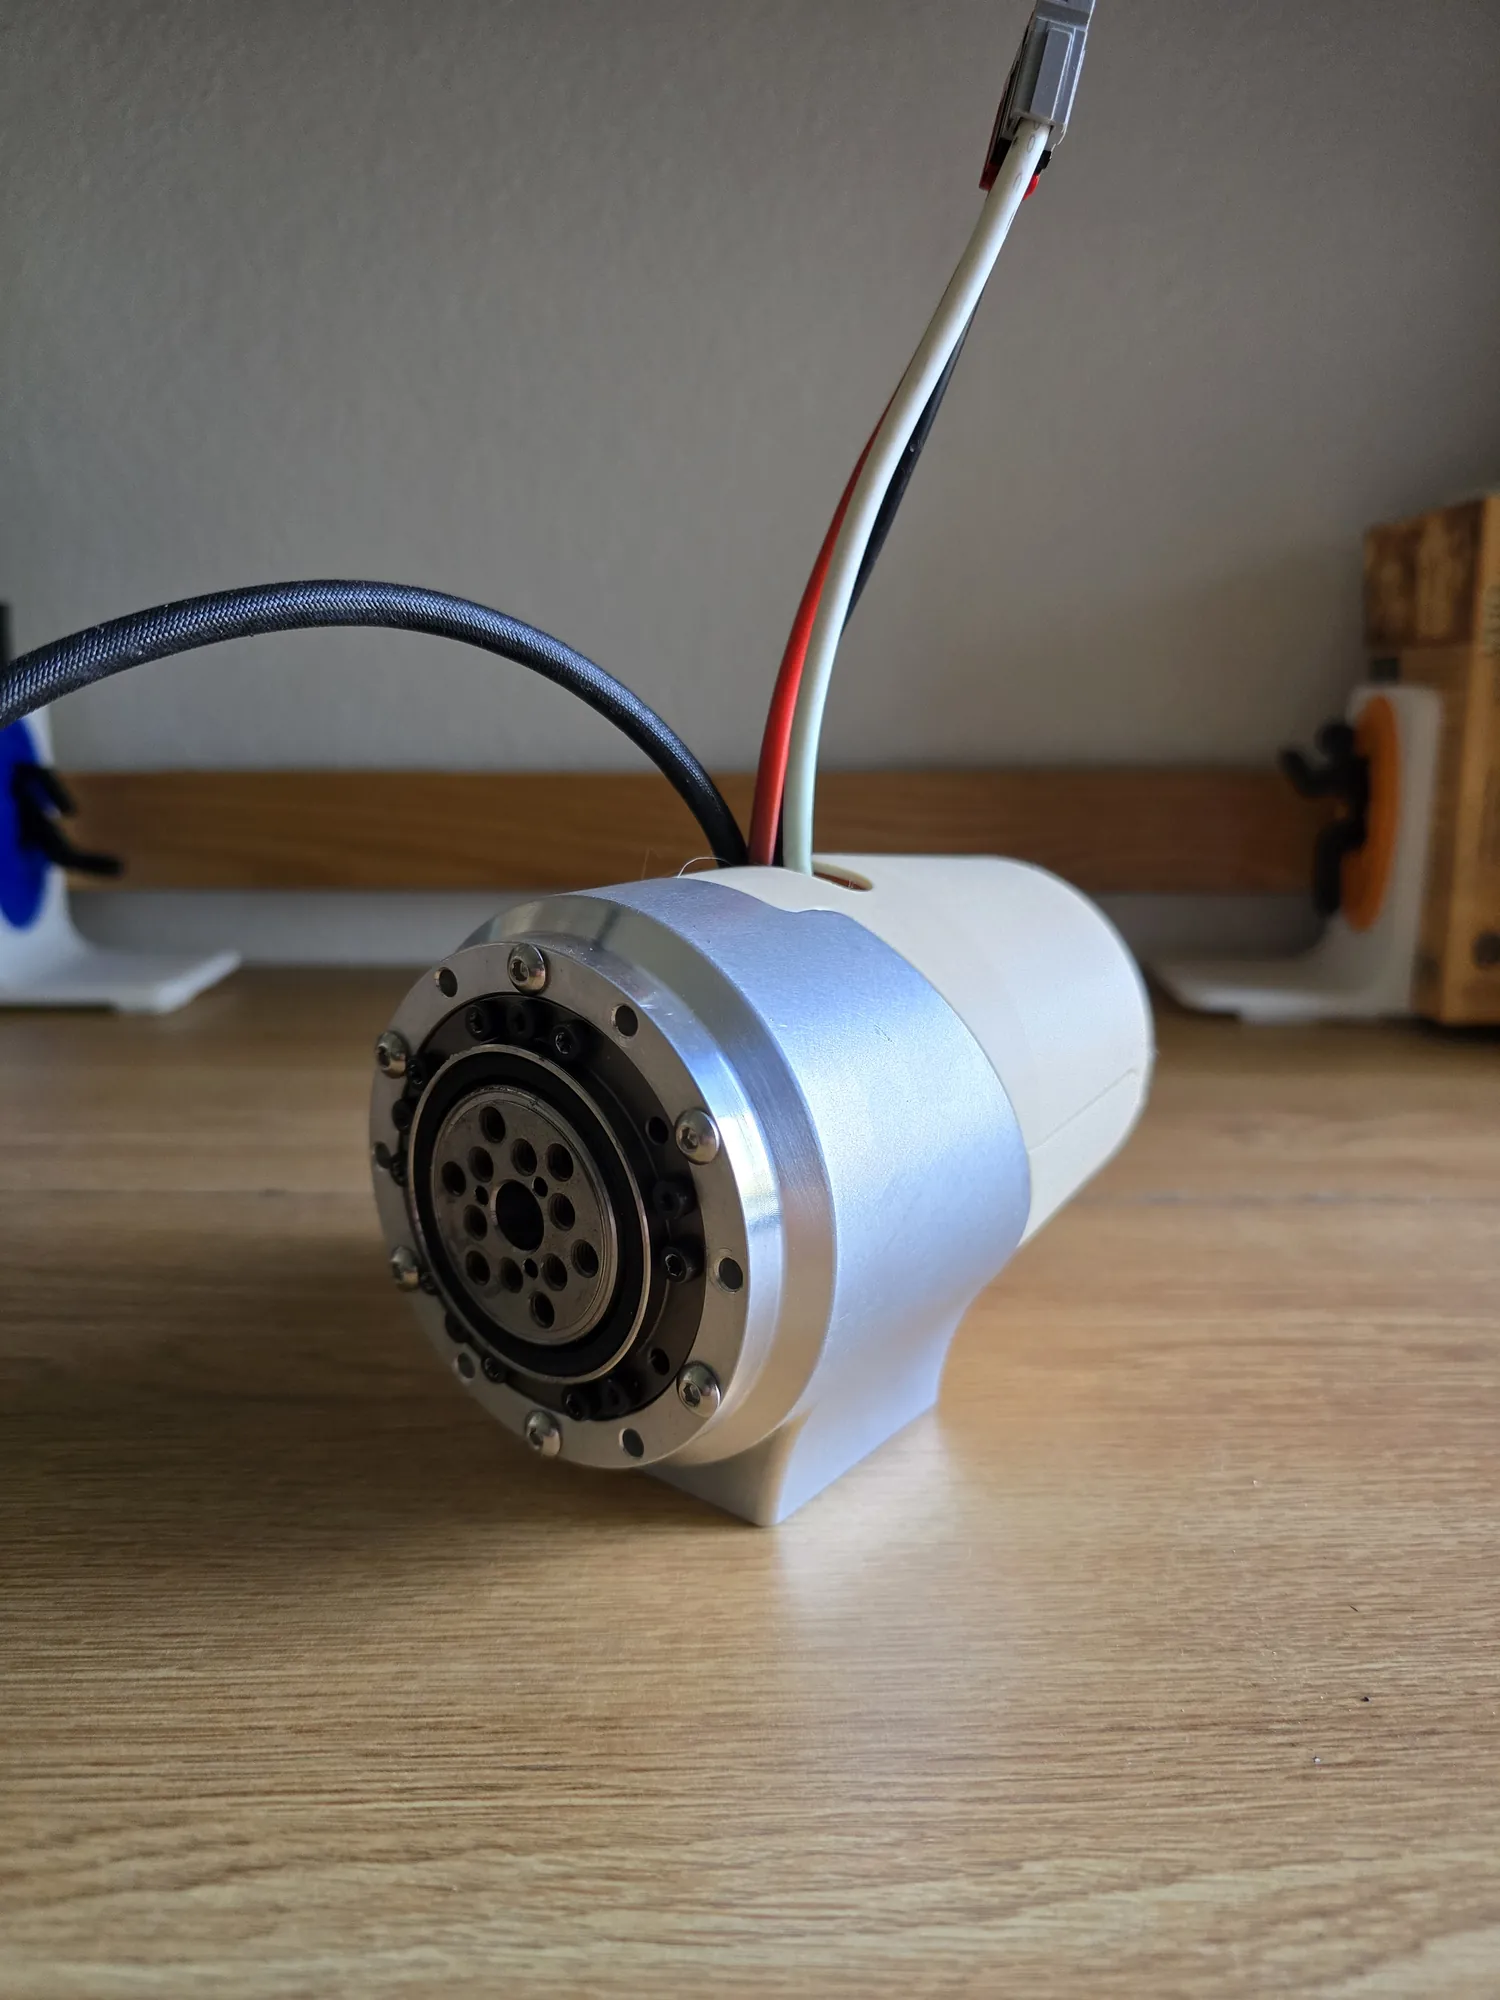
A compact motor module developed as the MVP for ARM 3.0's modular joint architecture. A NEO 1.1 brushless motor through a Harmonic Drive 71-100 reducer gives 110 Nm rated torque under an ODrive, with the housing and structure machined from 6061, so the machining workflow got validated alongside the part.
Why build one joint first
This module was the test article for ARM 3.0's Master Validation Plan: build a single integrated joint, and use it to measure manufacturing cost, assembly complexity, and real-world performance before committing the whole arm to contract manufacturing.
It worked as intended. Tolerance, integration, and manufacturability problems surfaced on one part instead of six, which is the cheapest place to find them. Technical and financial risk both came down, and what was left was a joint architecture that scales.
 03
The module
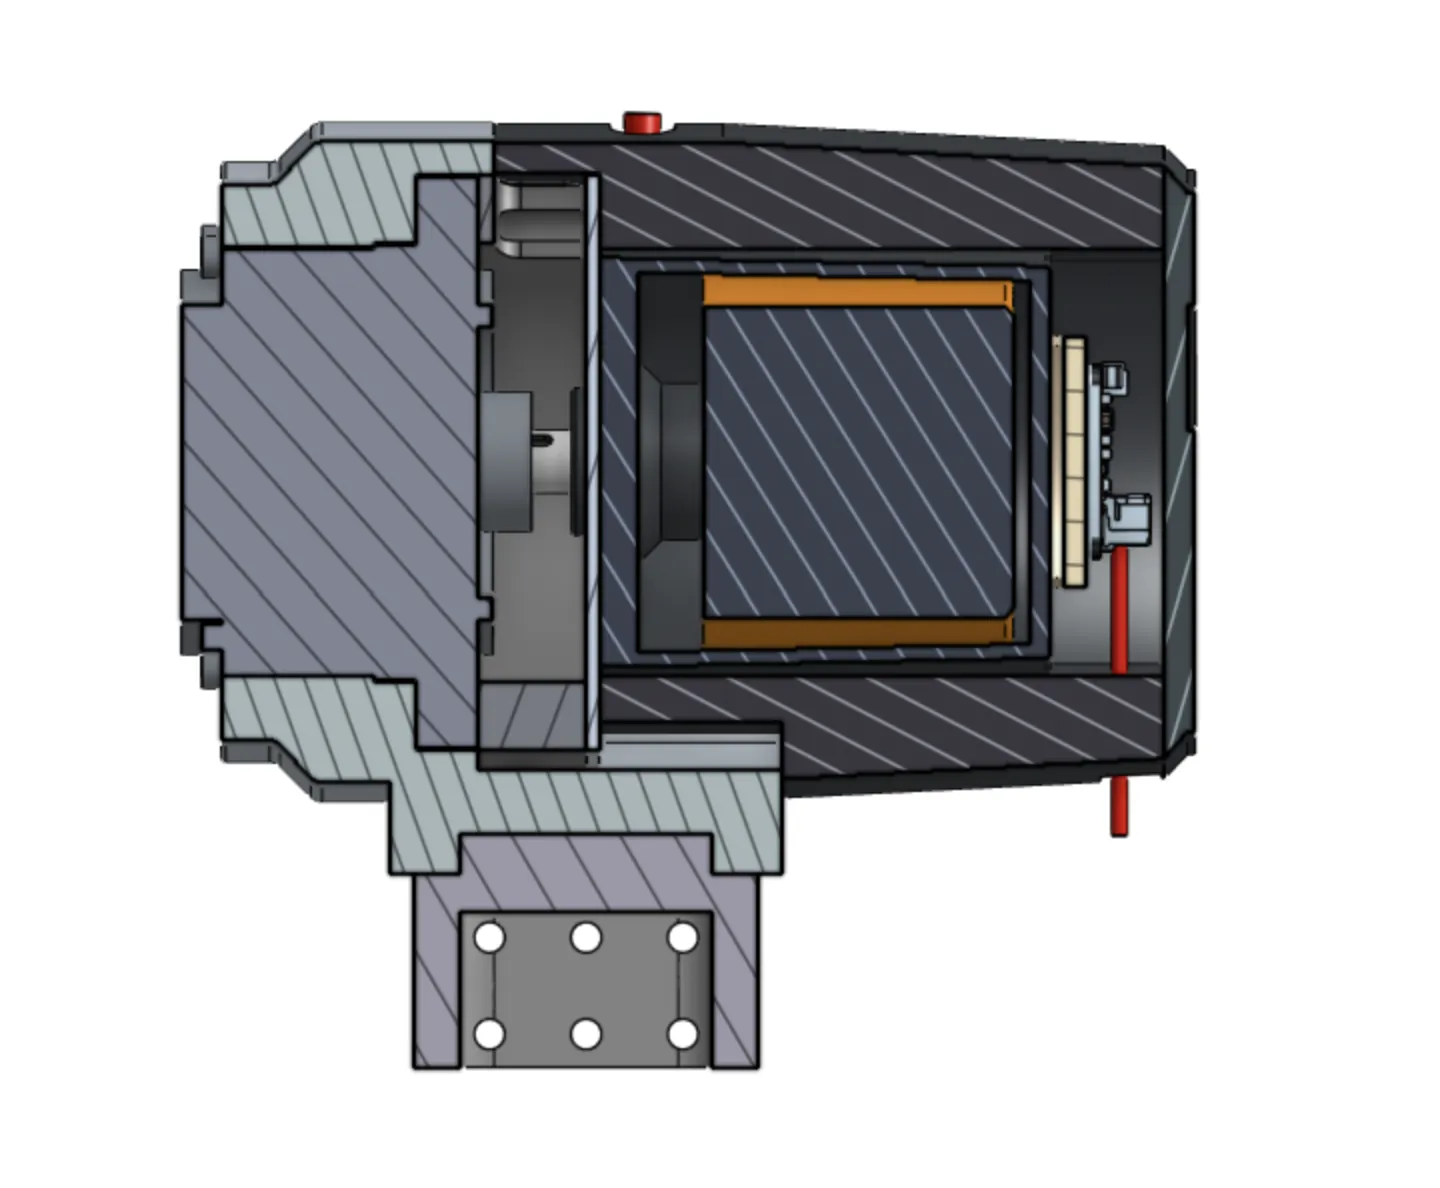
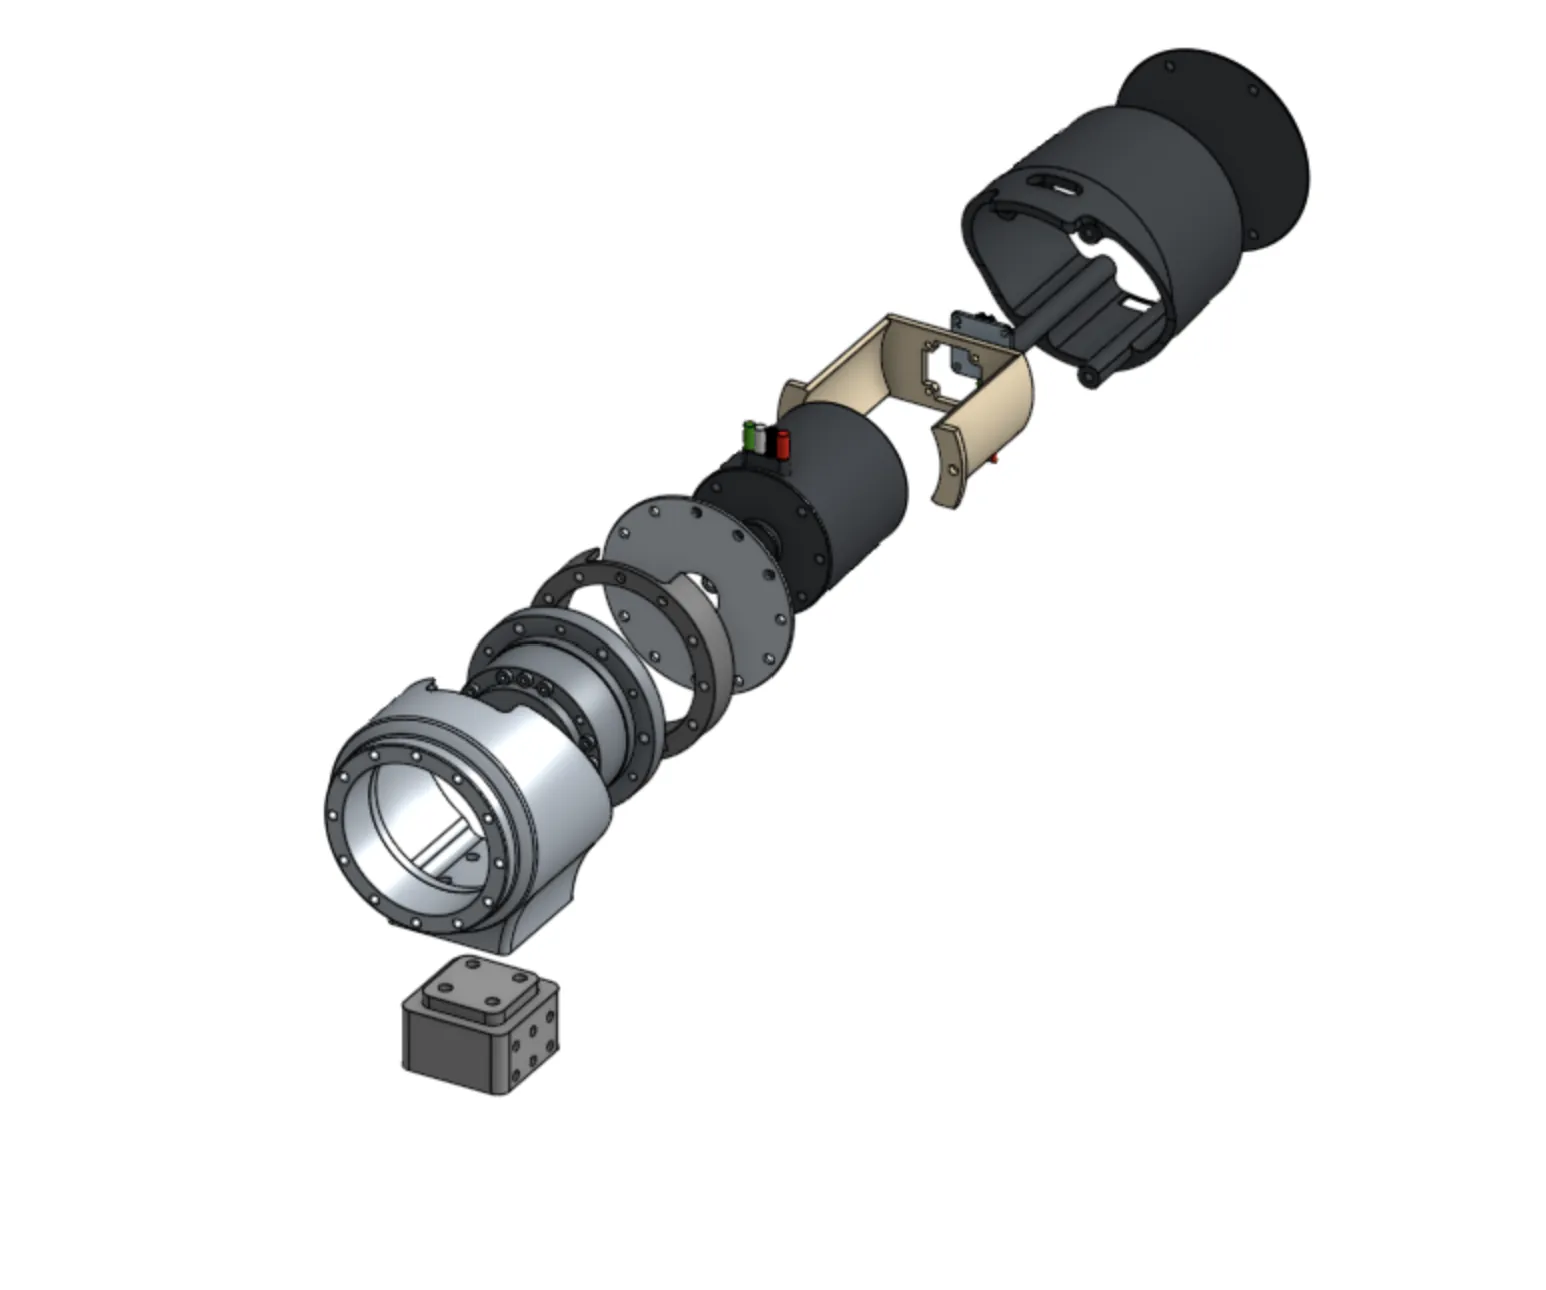
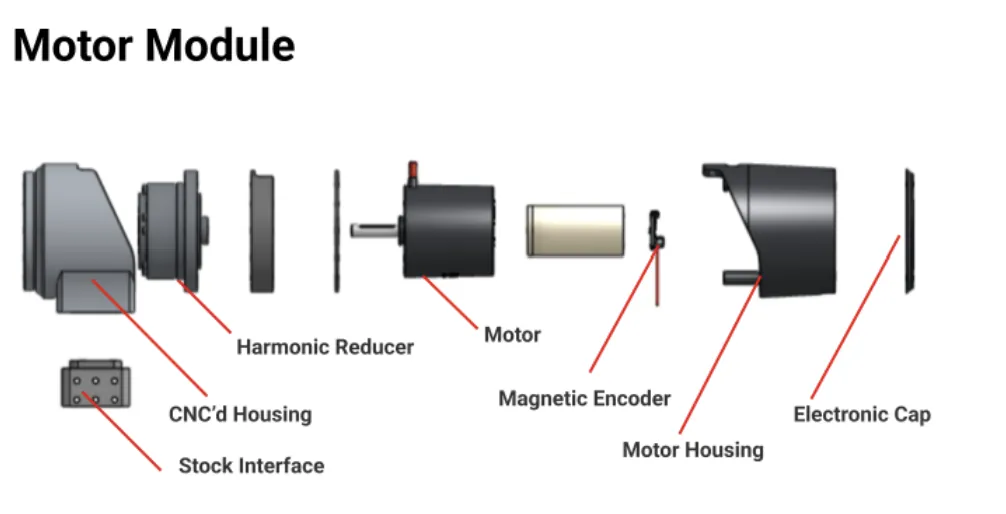
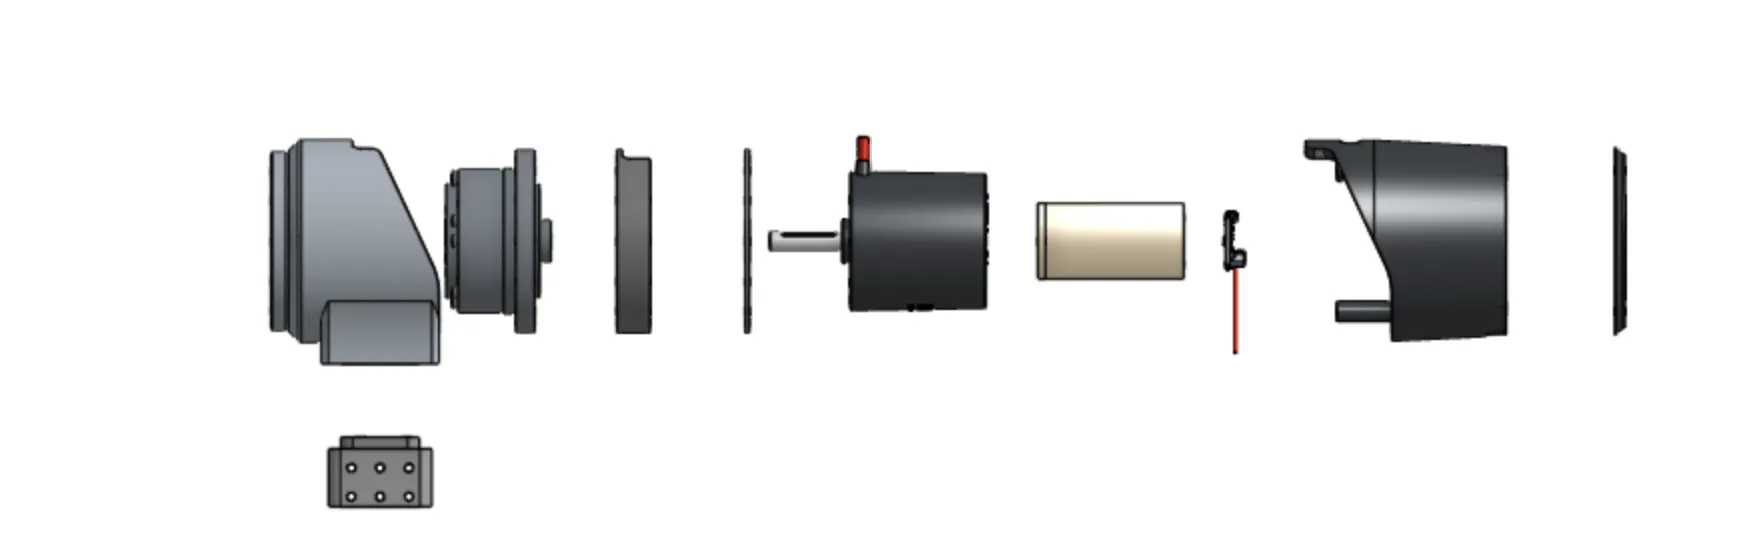
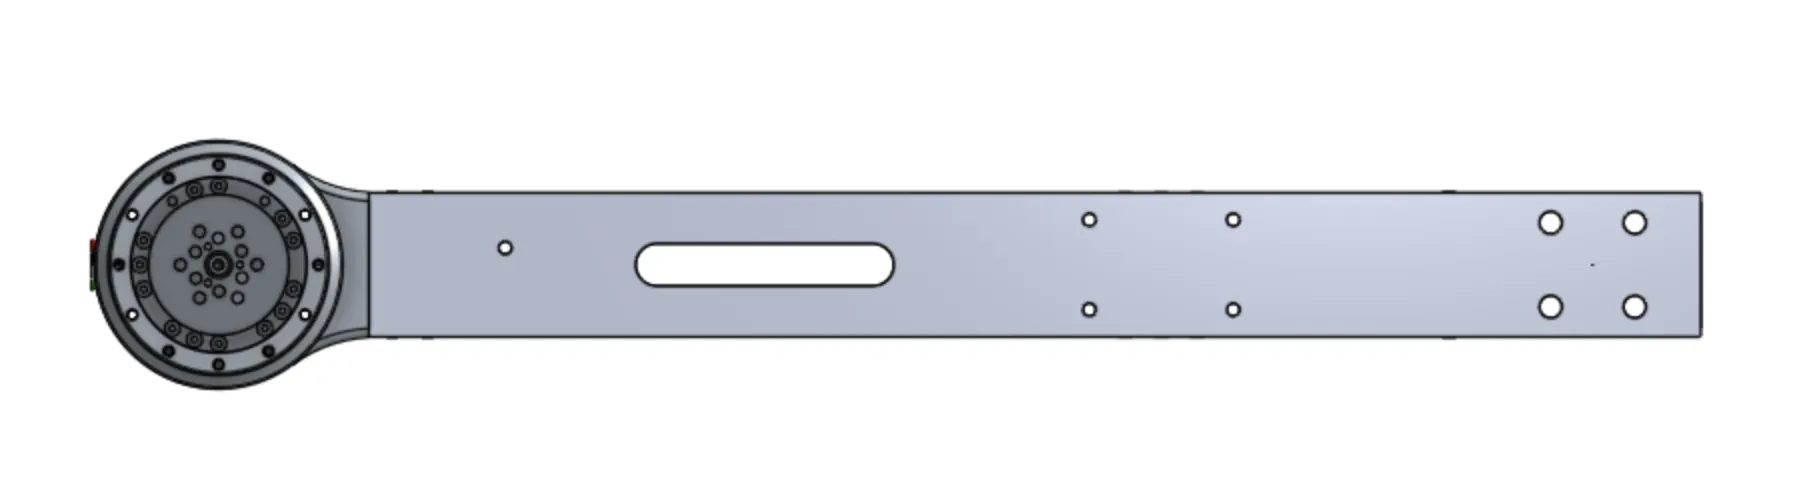
Motor, harmonic reducer, magnetic encoder, and electronics cap stack into a CNC'd housing that bolts to 2×2" tube stock at a stock interface. The reducer does the work: 110 Nm rated at the output with the motor staying small enough to sit inside the joint envelope rather than hanging off it.
The same module, scaled, is what the shoulder, elbow, and wrist all became.
Gallery
Inside the module
Stock interface, harmonic reducer, motor, encoder, cap.
Built and fitted
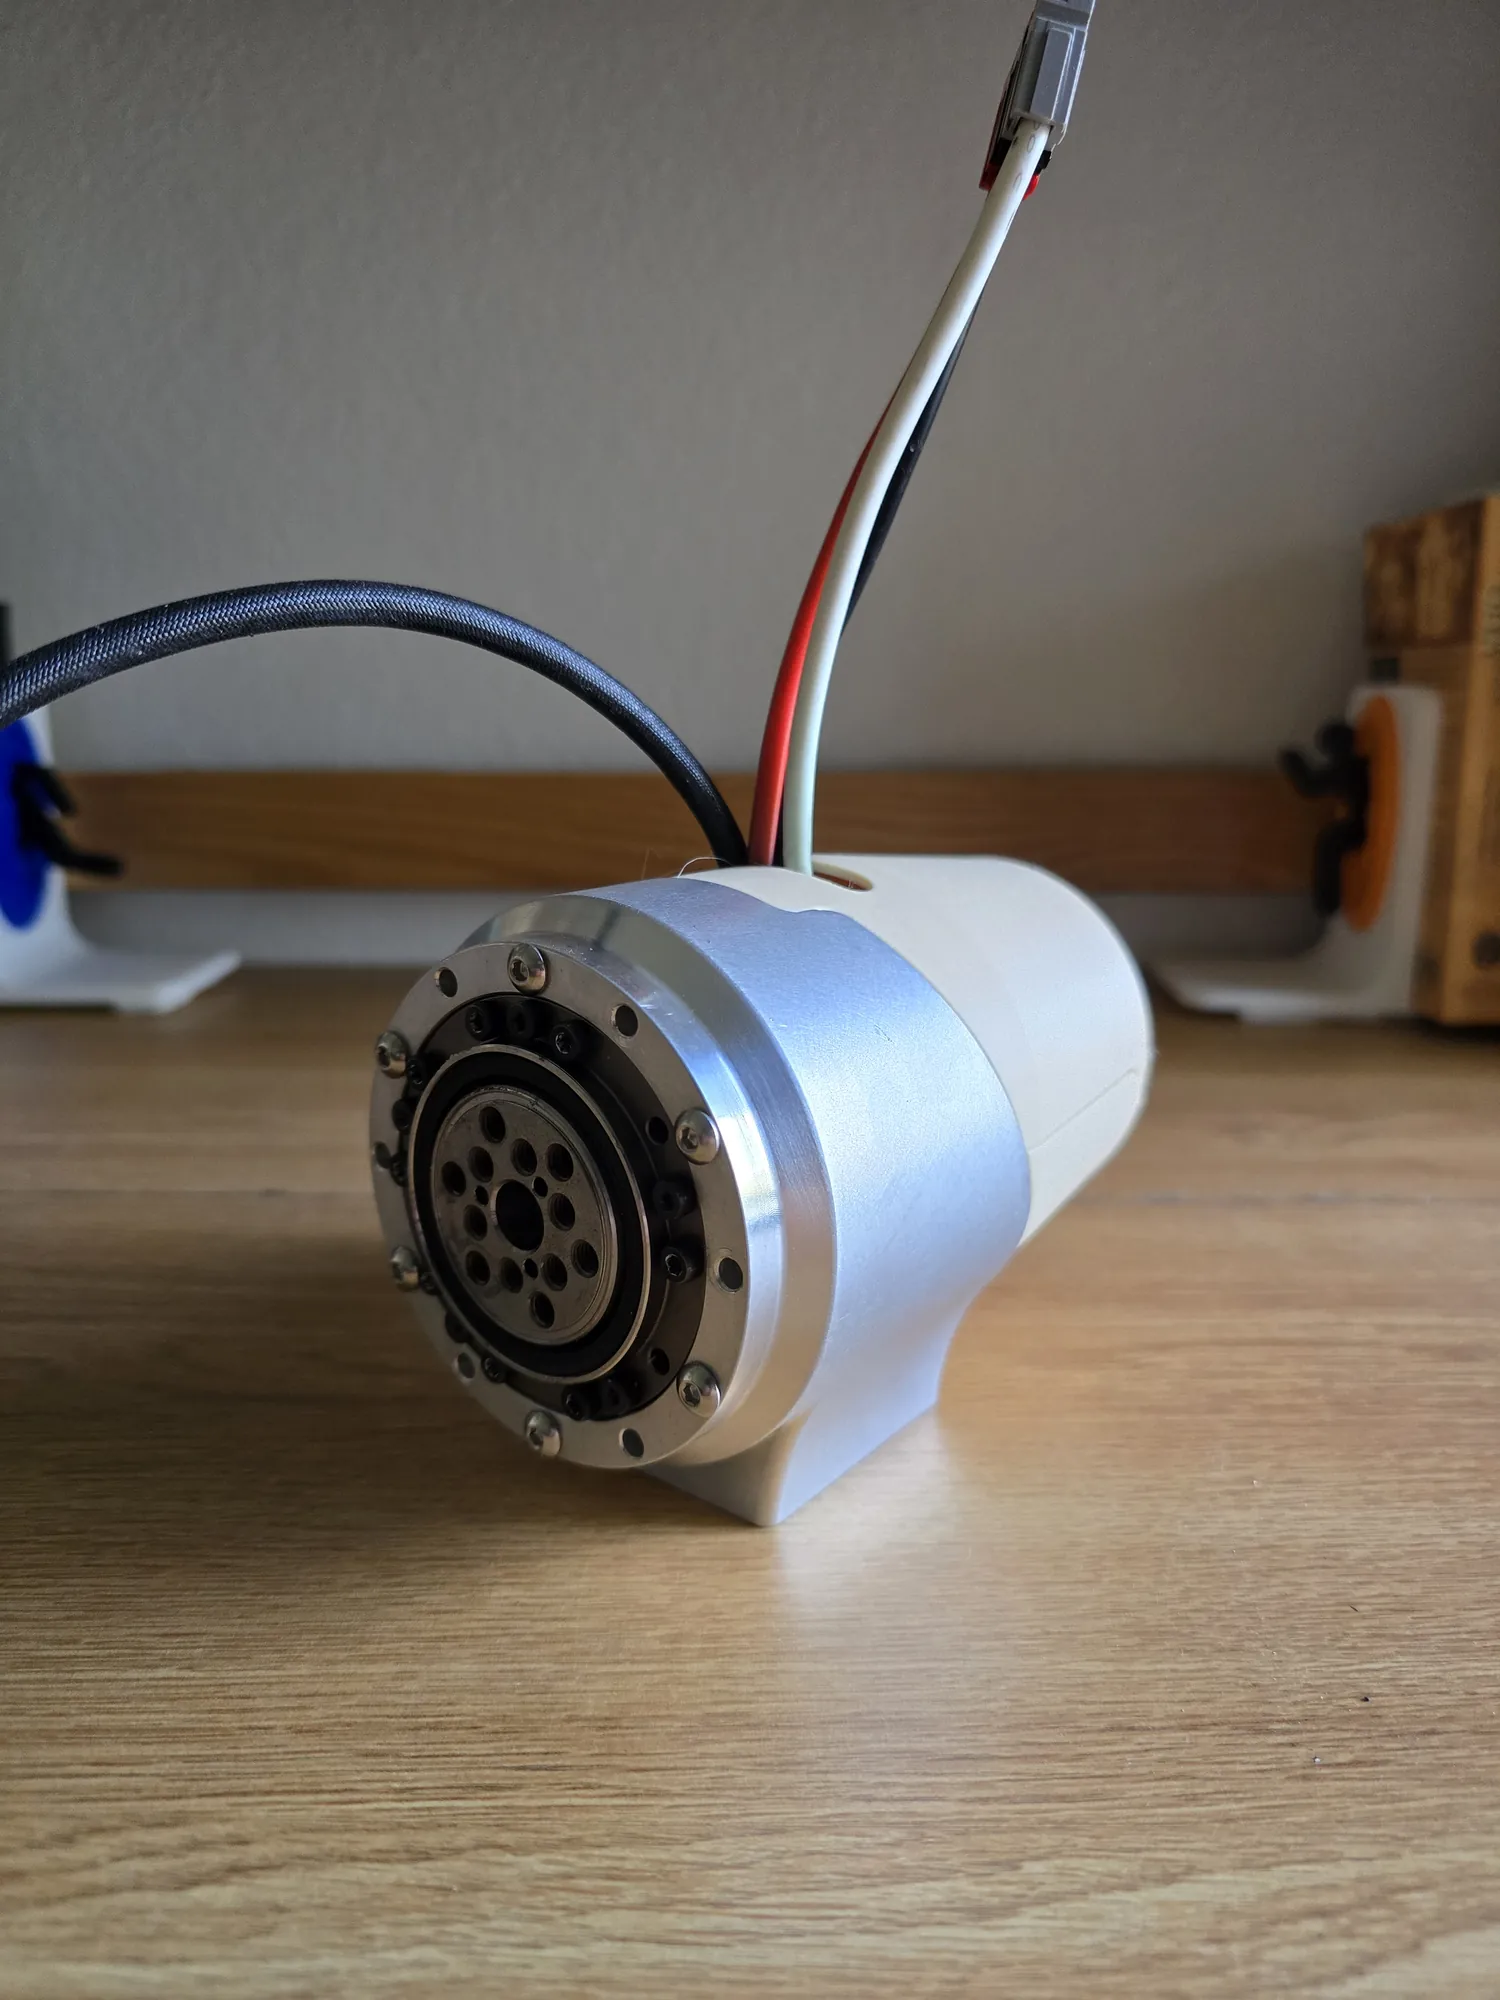
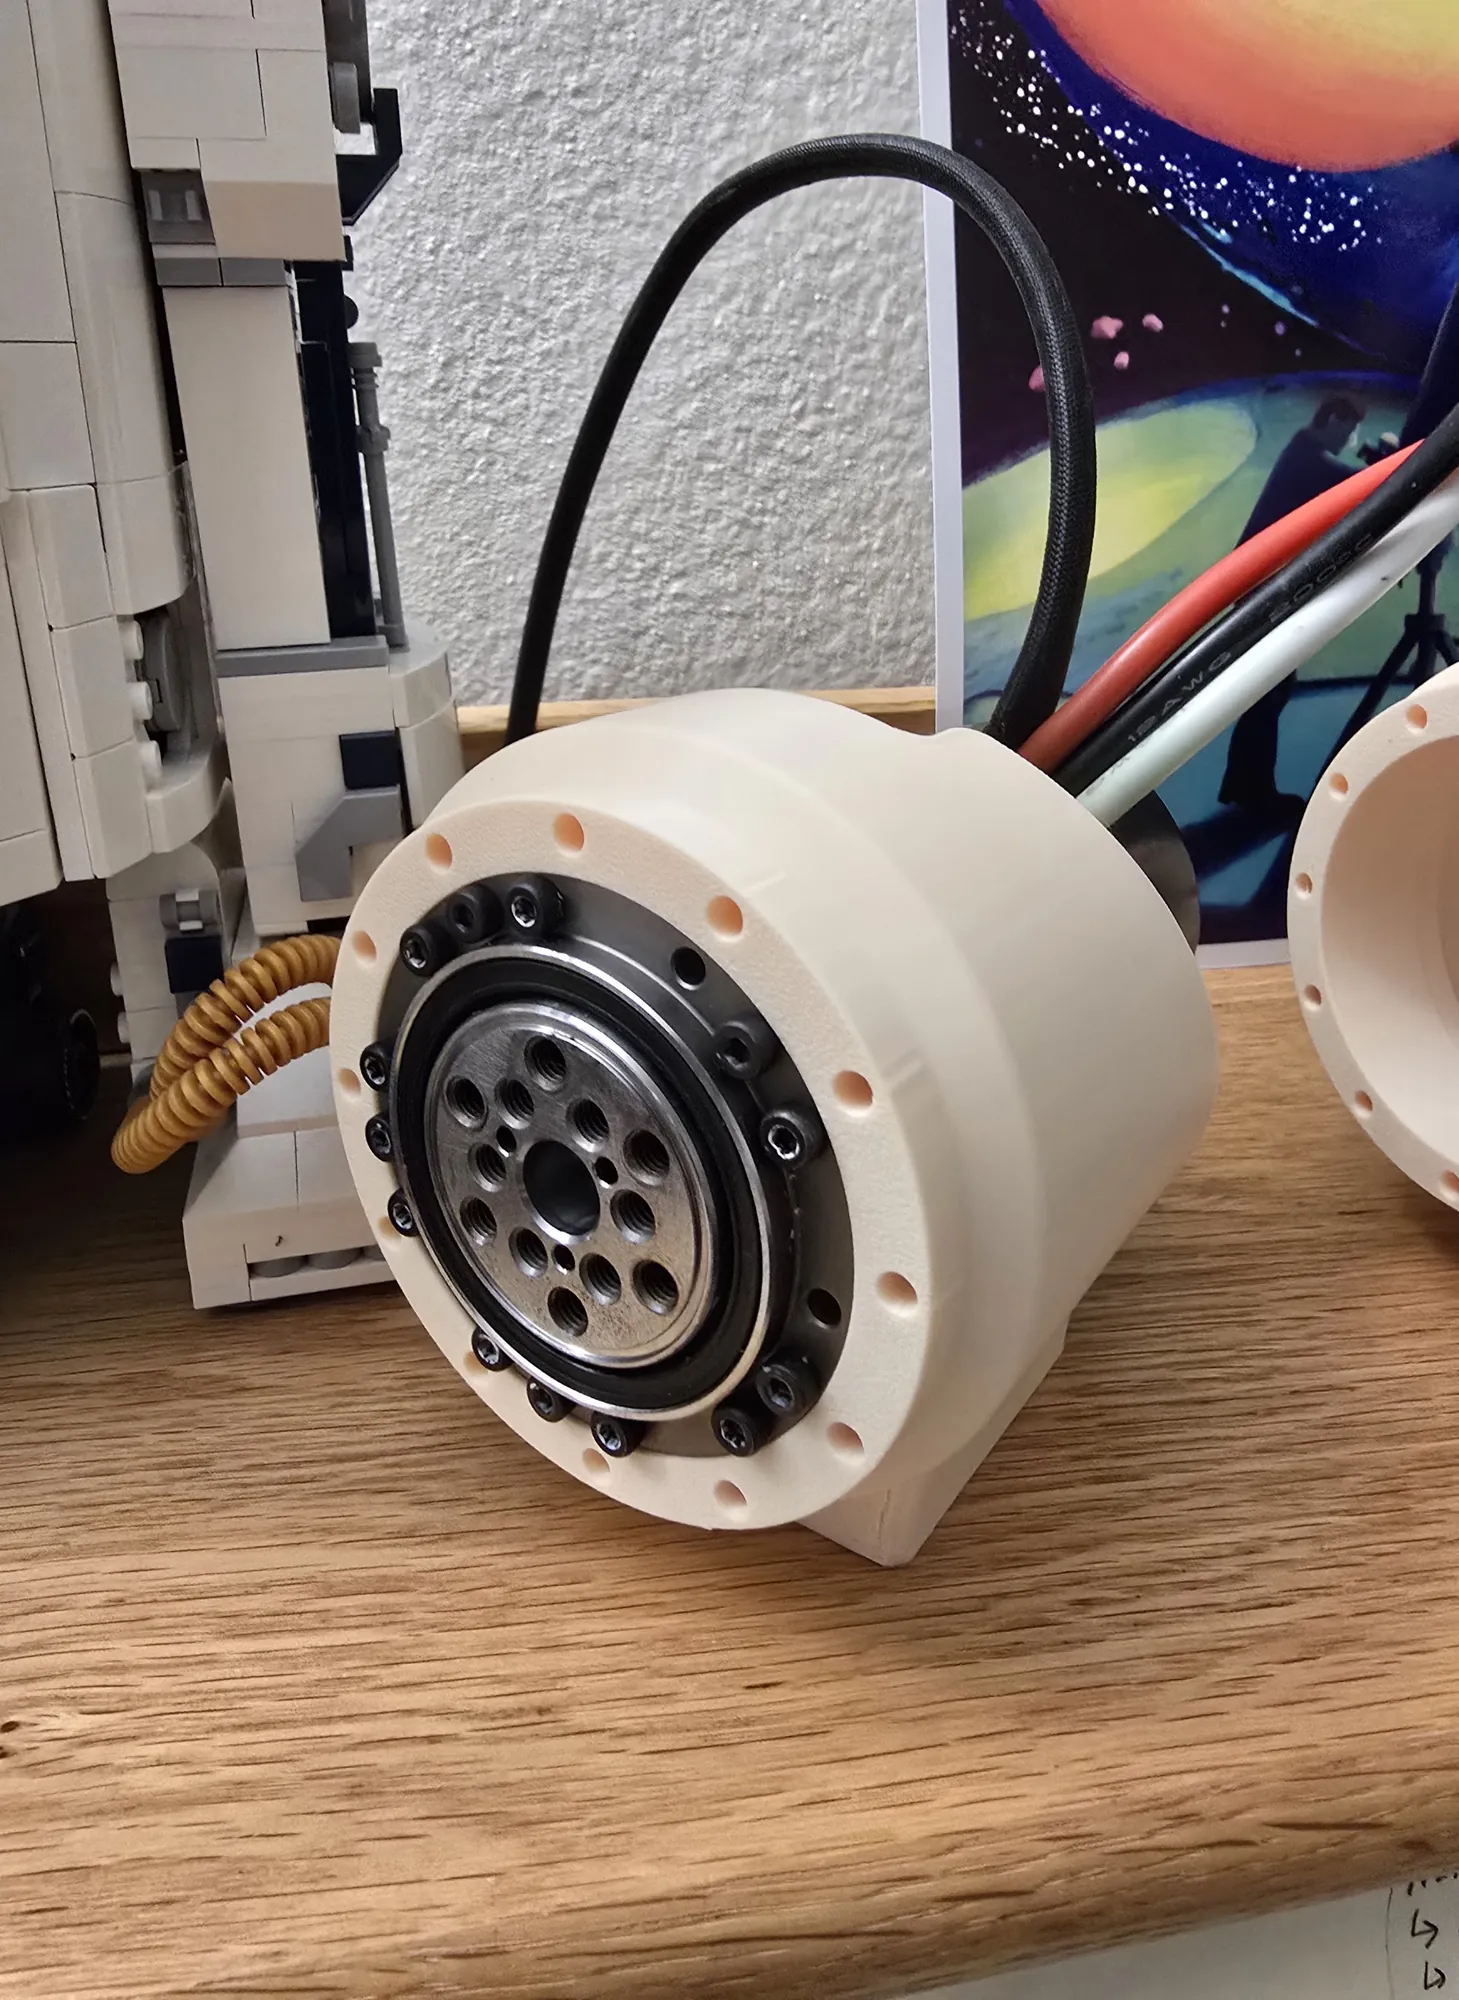
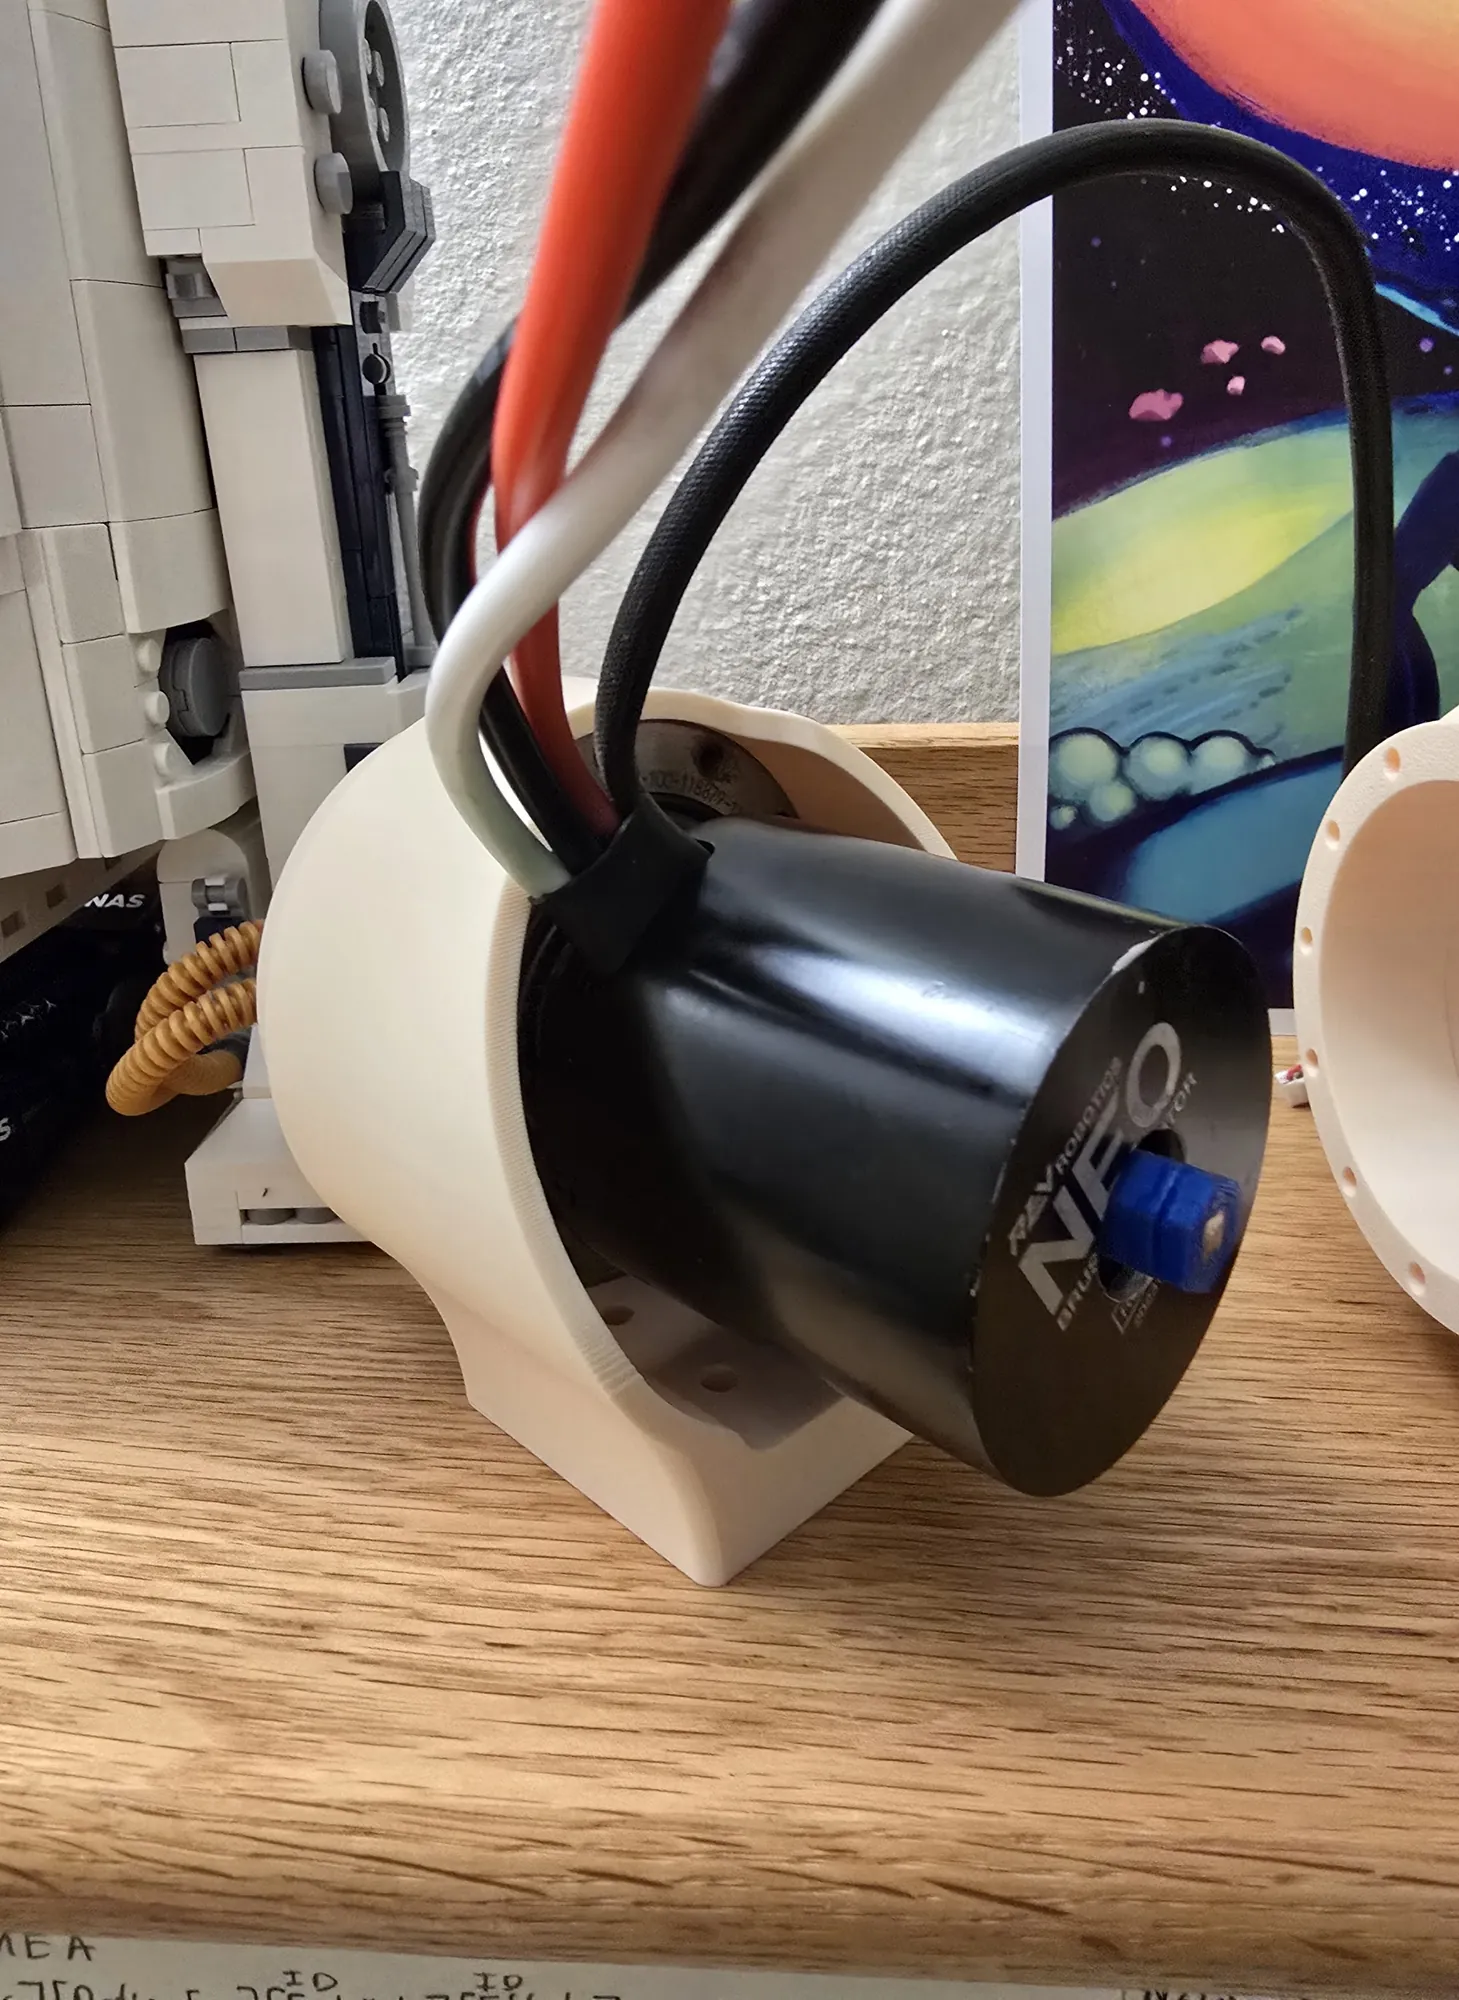
Machined housing, printed motor housing, NEO 1.1.
Renders and toolpaths
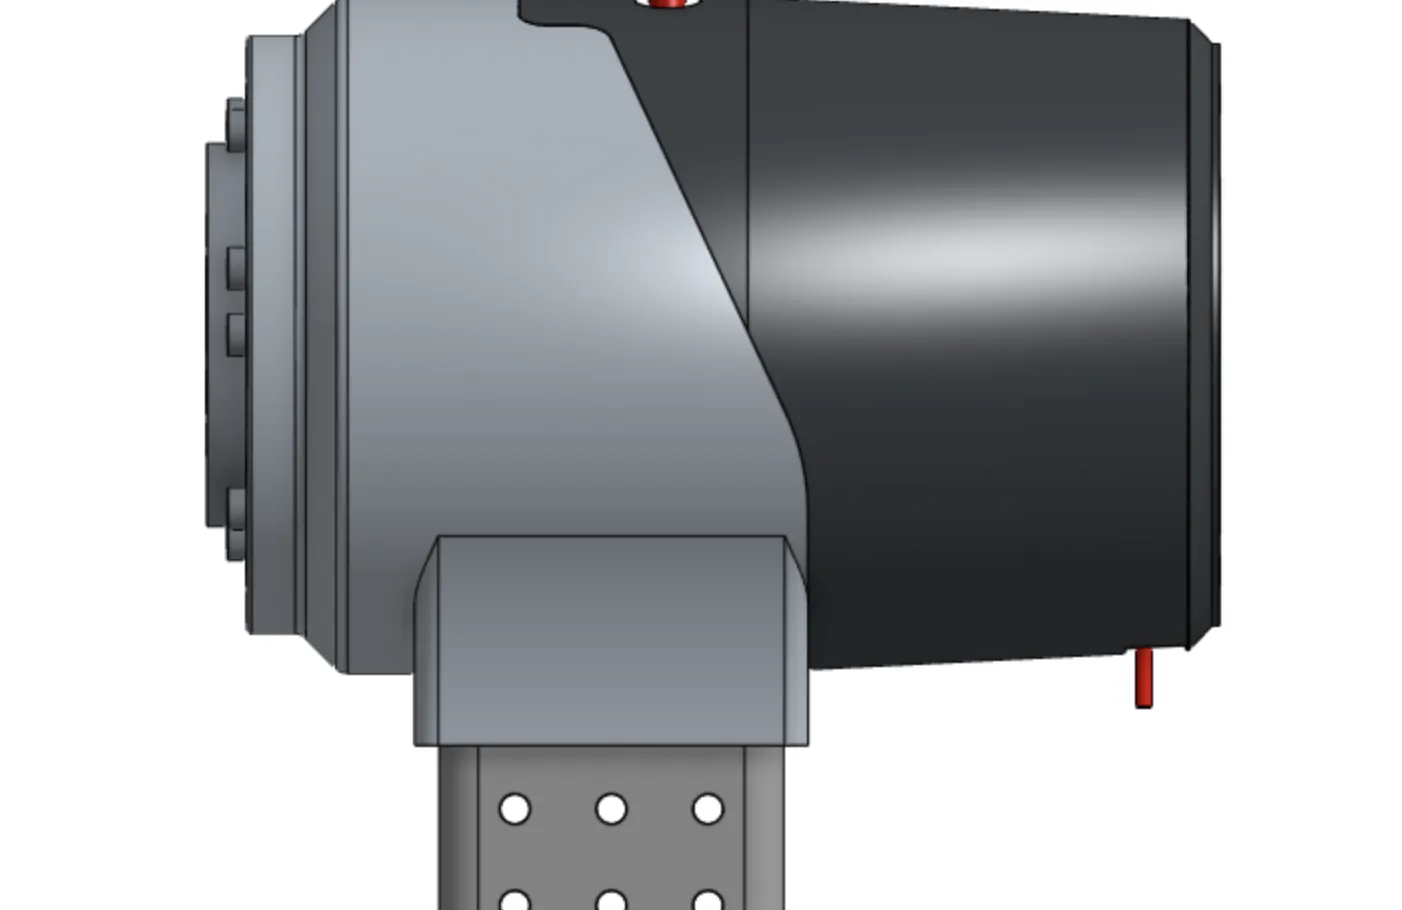
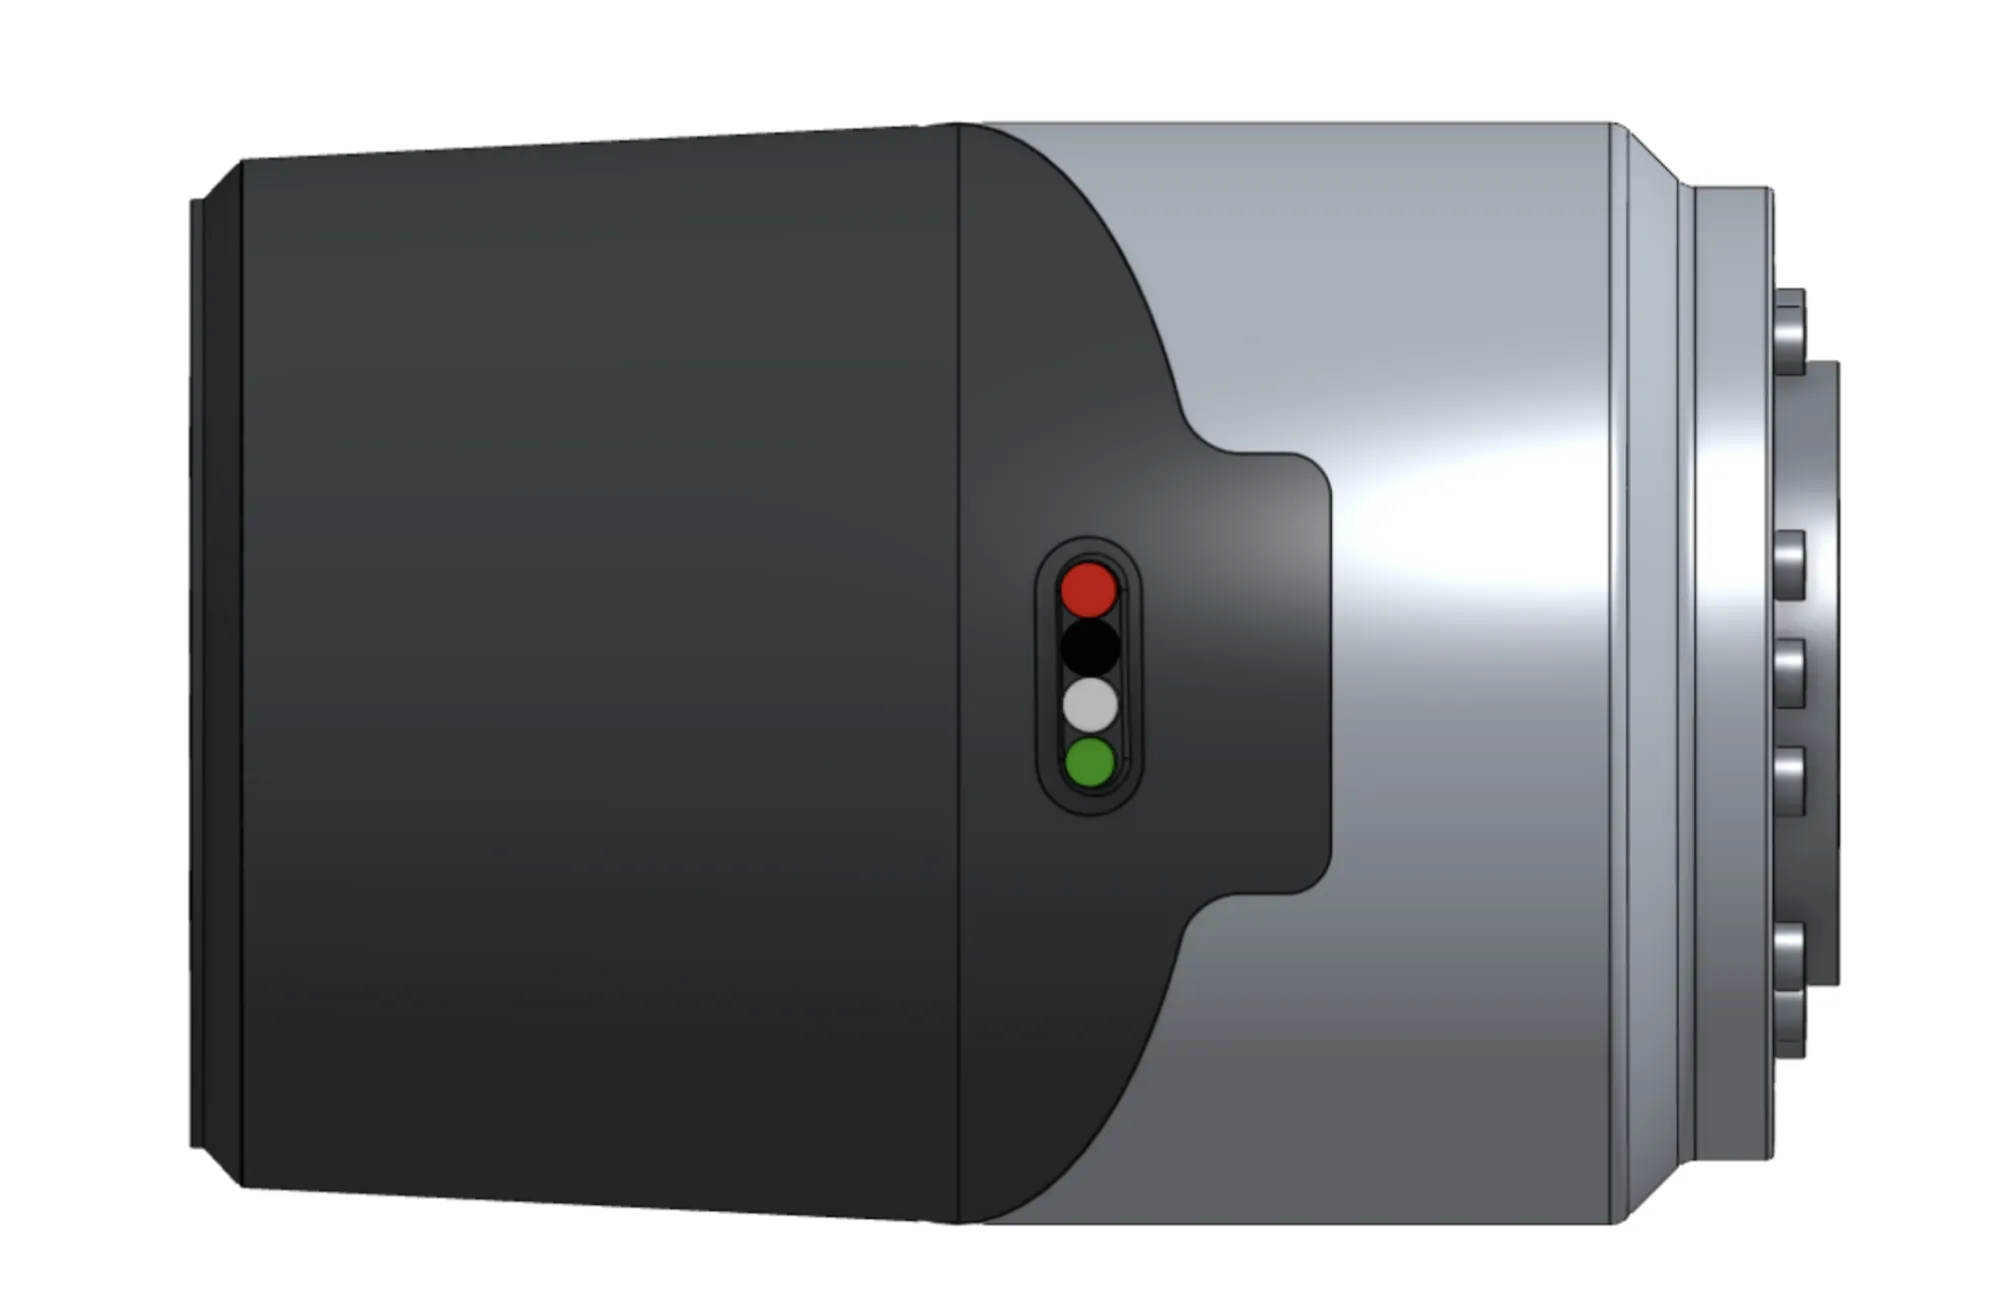
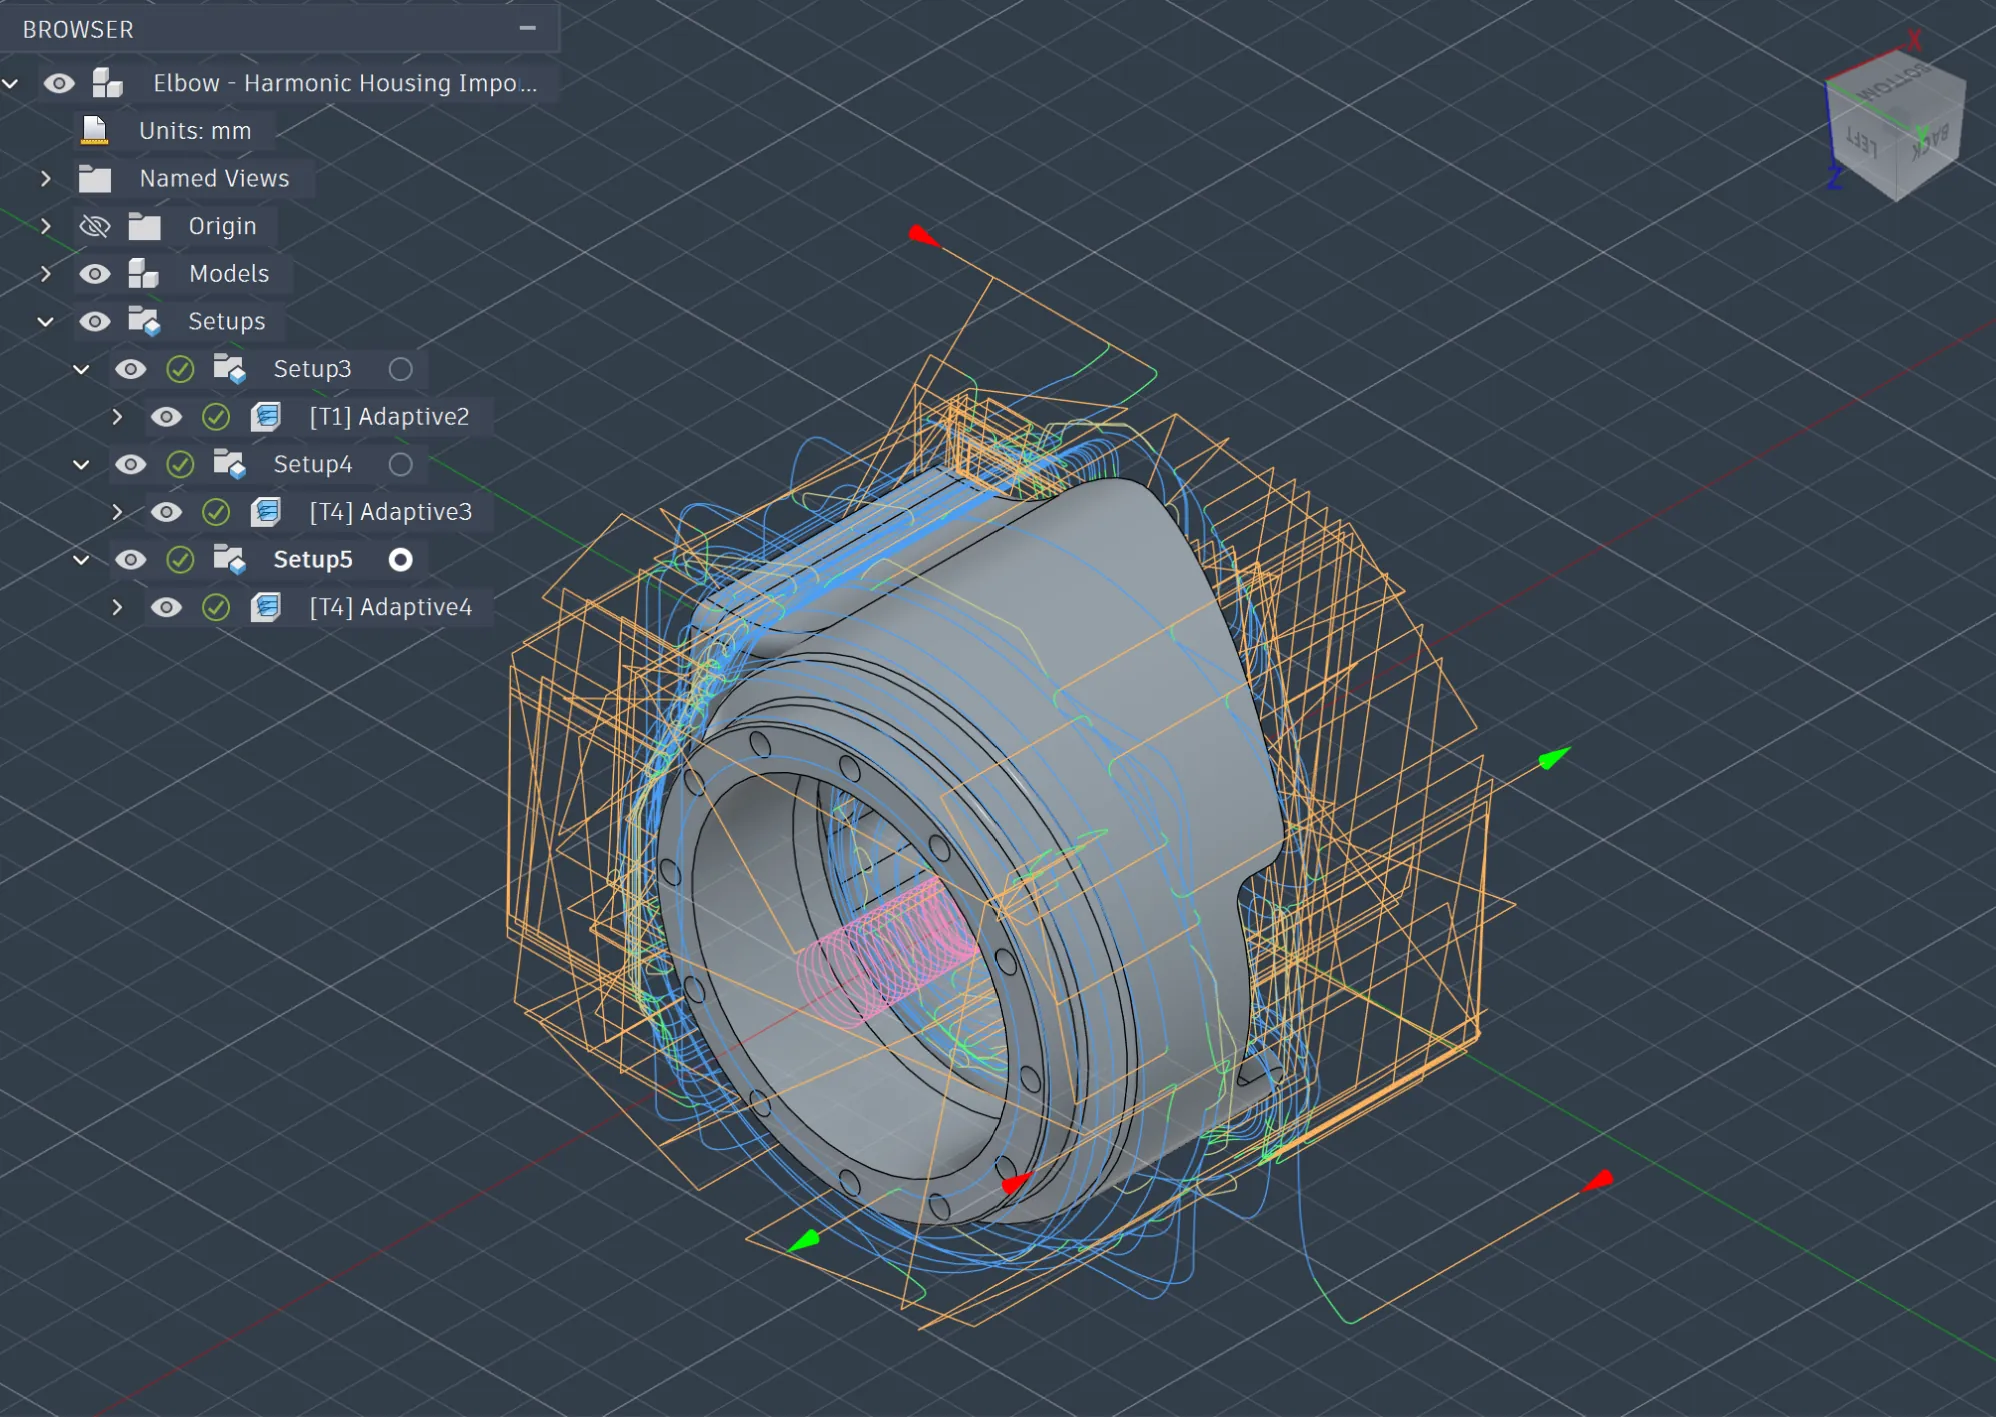
What it looks like finished, and how it got cut.
Yonder Robotics