Skip to content
All work

Yonder Robotics · 2026

Sample Drill

An auger sample drill and the two-stage elevator that deploys it. The problem isn't drilling; it's returning a clean subsurface sample without the surface debris the auger necessarily cuts through on the way down.

Drill motor
NEO 550
Reduction
48:1
Bit speed
Up to ~11,000 rpm free speed
Sample depth
10 cm
Elevator
2-stage cascade, CM AKE60
Stage 1
Chain drive
Stage 2
Low-creep string carriage
Role
Design
OnshapeSolidWorks
01

The self-plugging cache

Spoil separates by depth using geometry alone: no valves, no actuators, no sensing.

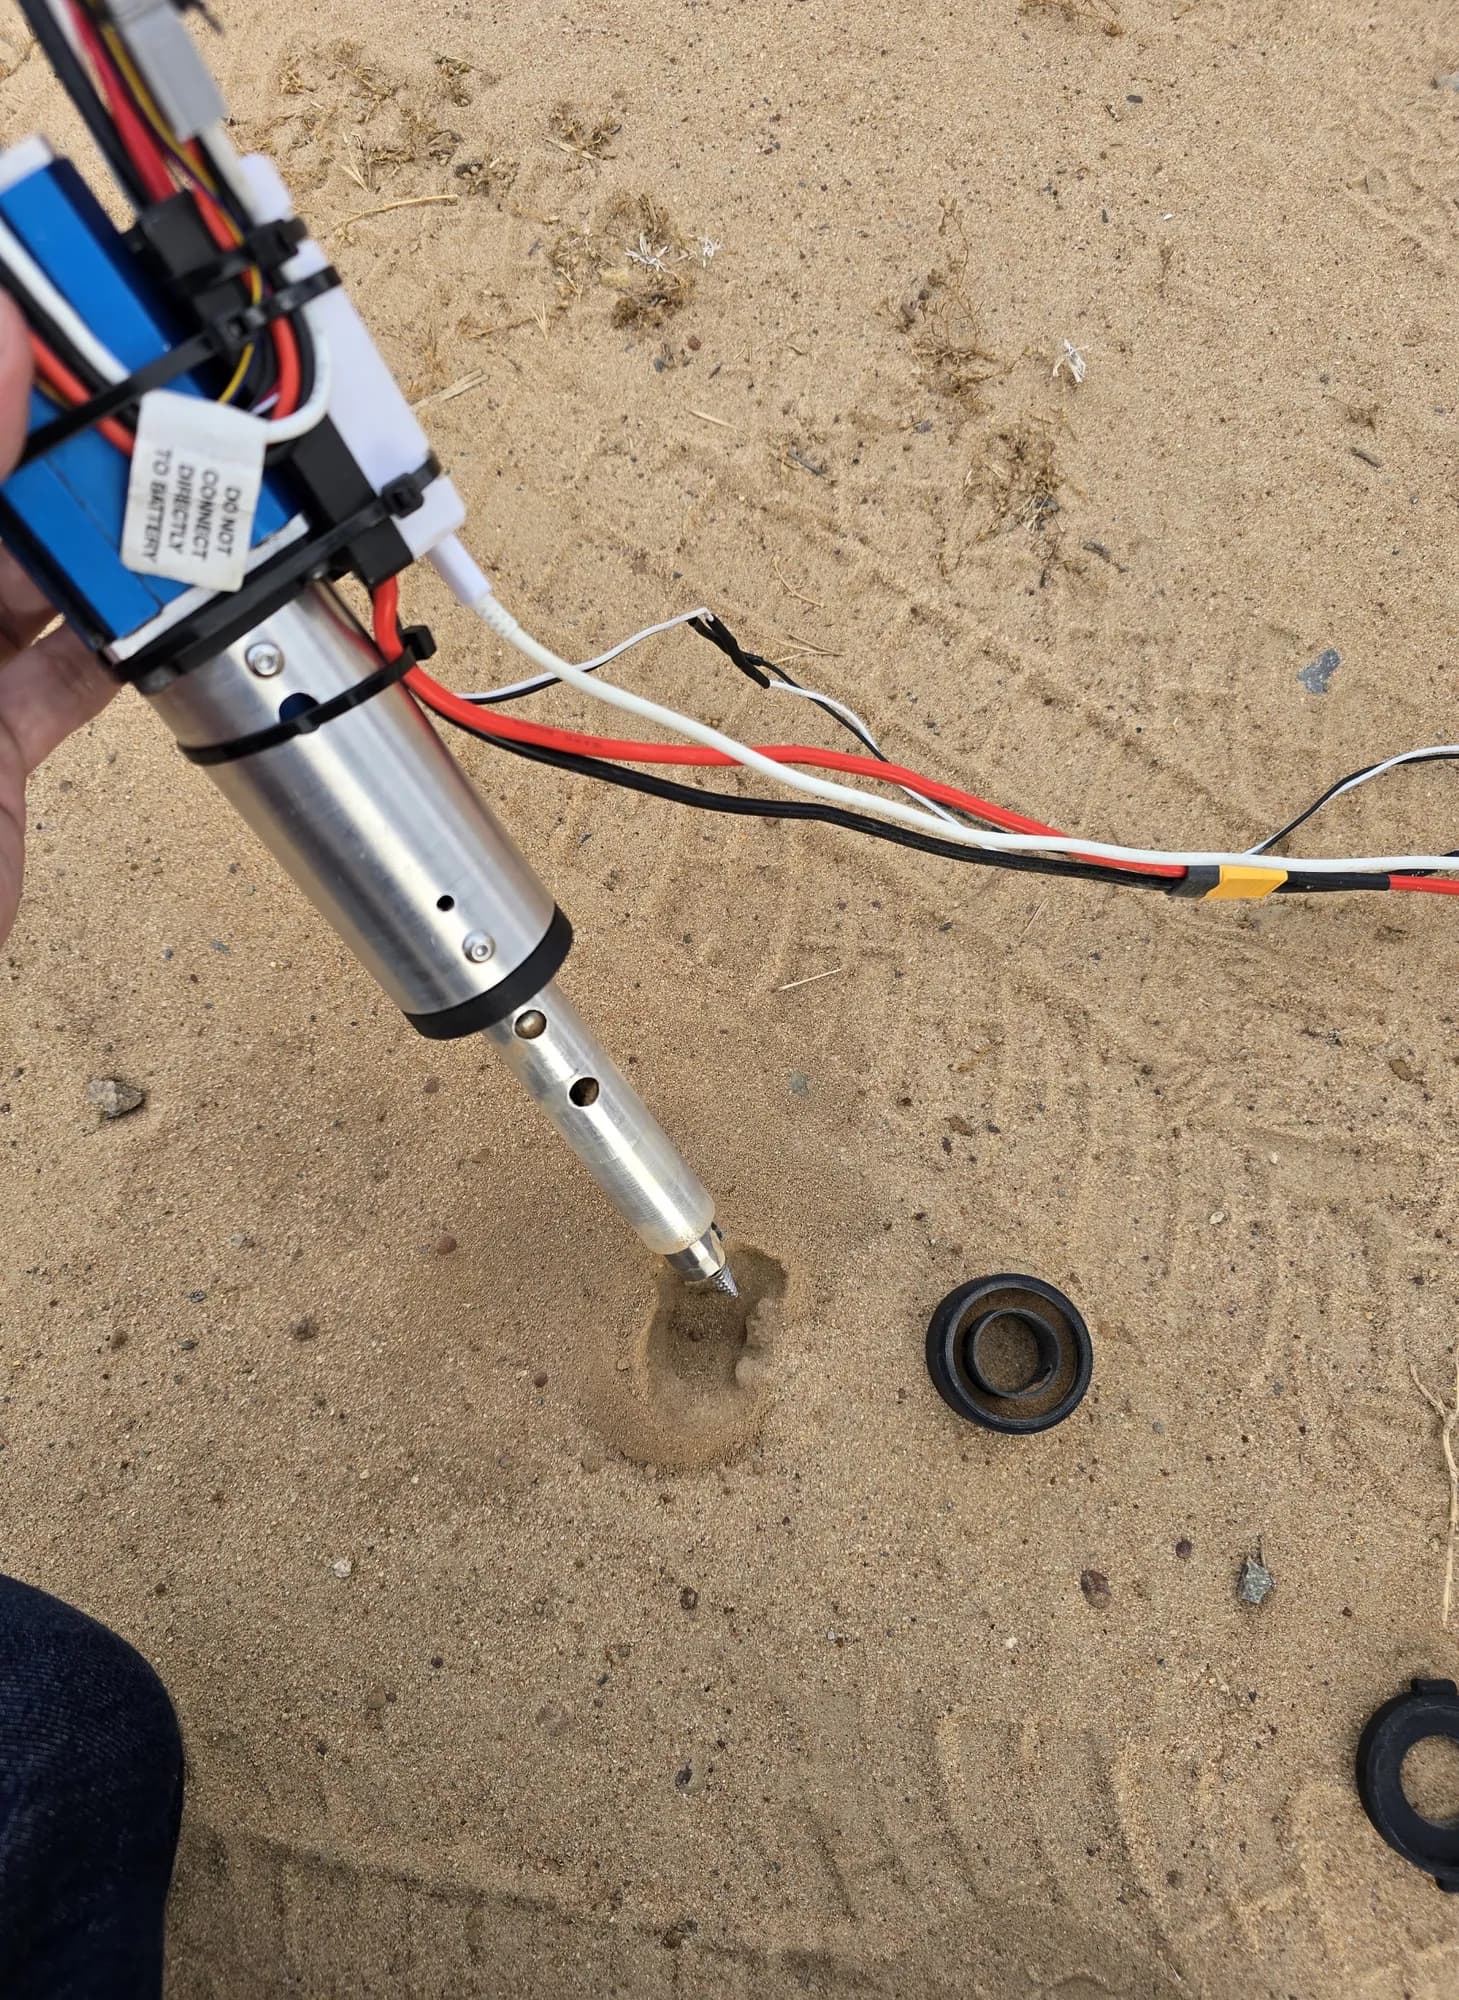
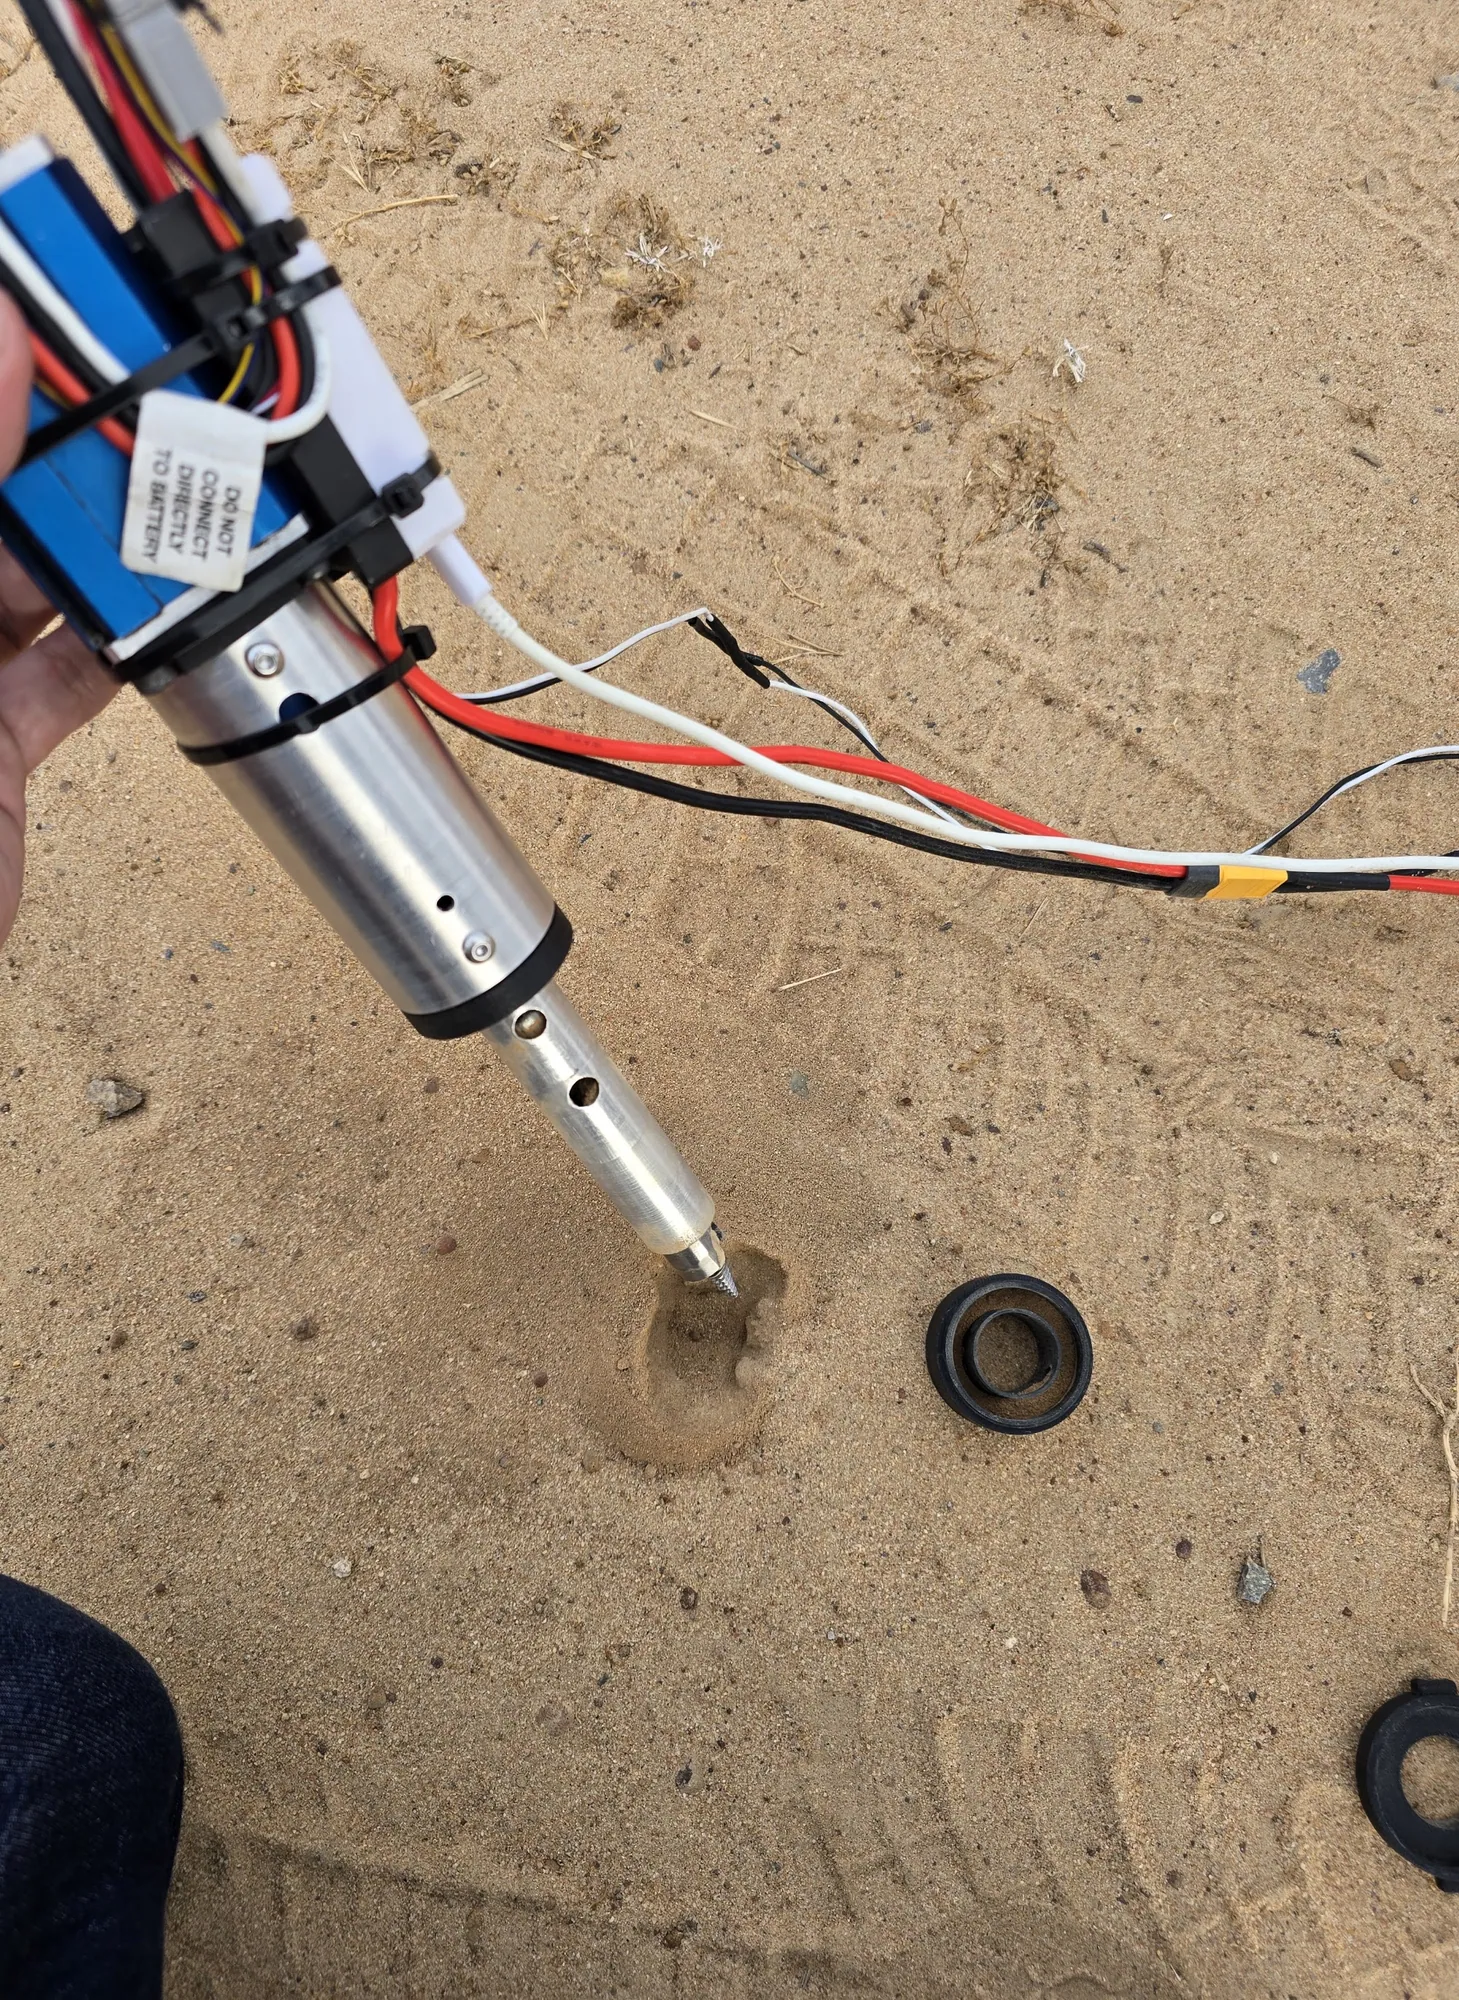
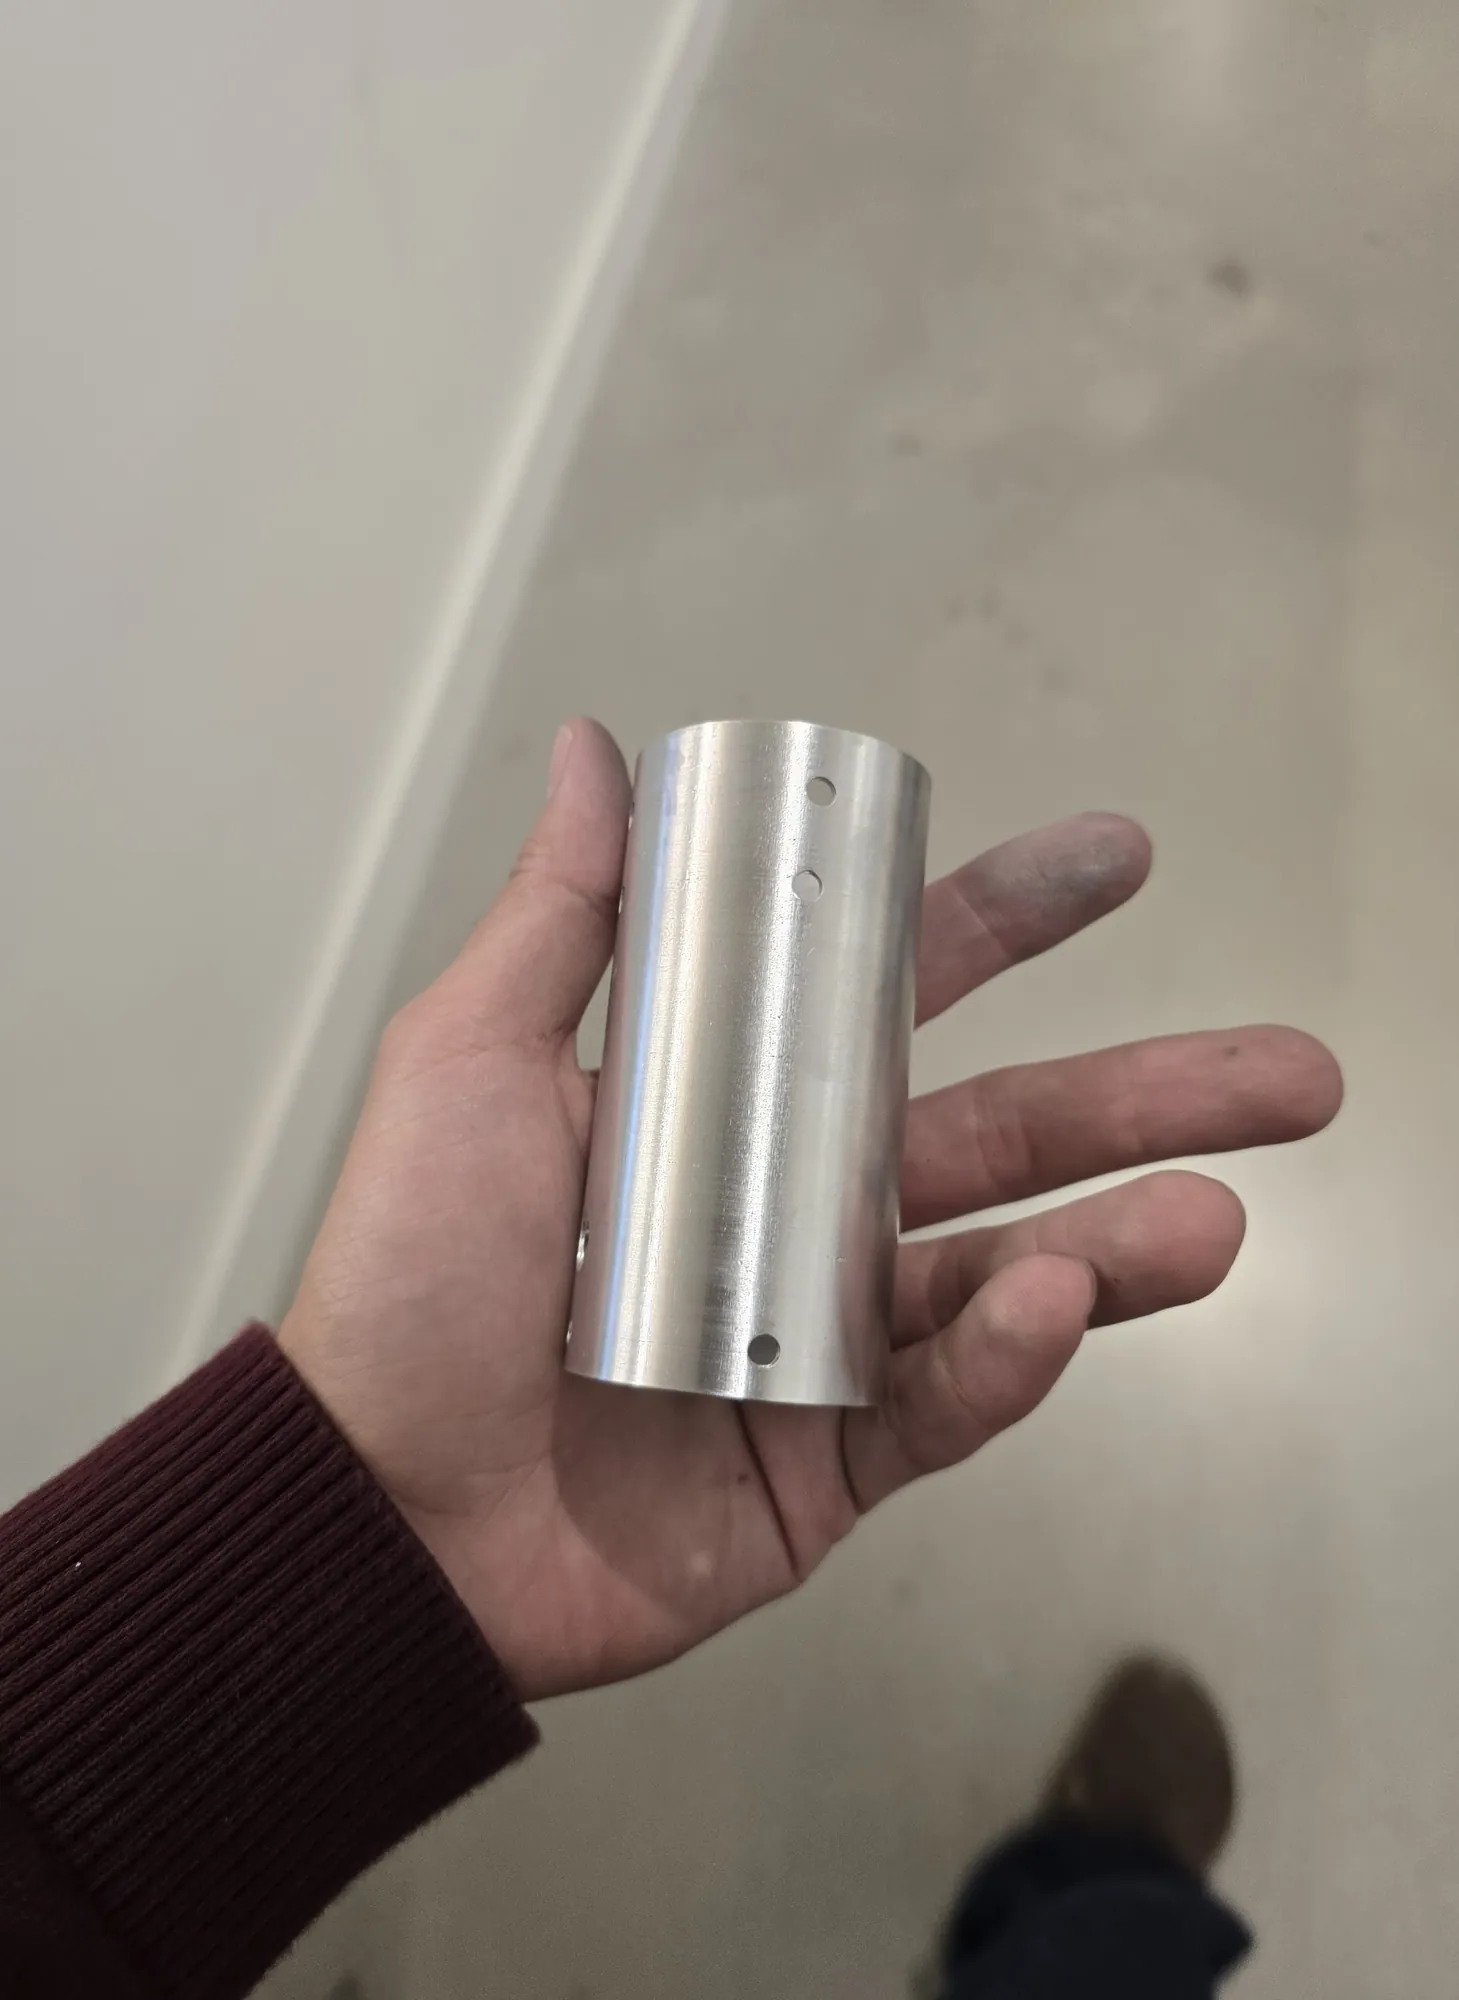
An ejection hole sits 10 cm above ground level. Cutting the top layer, that hole is above the soil line and shallow material throws clear. At a full 10 cm plunge the hole is buried and self-plugs against the surrounding soil. Everything traveling up the auger from that point is subsurface, and all of it is retained.
Auger in the soil, 10 cm down00
Auger in the soil, 10 cm down
Cache tube: the sample rides up the auger into this04
Cache tube: the sample rides up the auger into this
02

Two-stage elevator

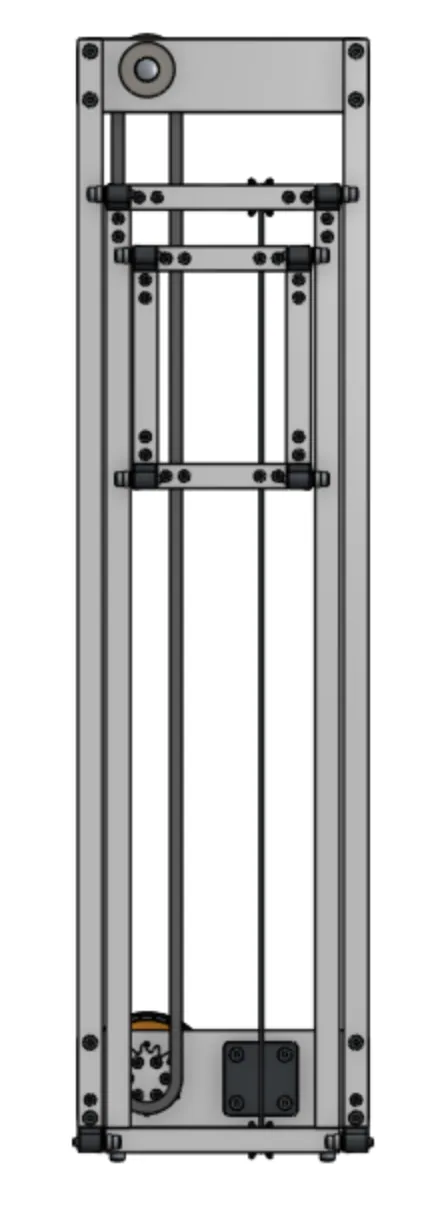
A CM AKE60 drives a primary chain stage into a low-creep string carriage stage.

It has to do two contradictory things well: push the drill into the ground under load, and retract fully above the rover for transport.
Elevator bearing block: 8 mm bearings guiding the tubes11
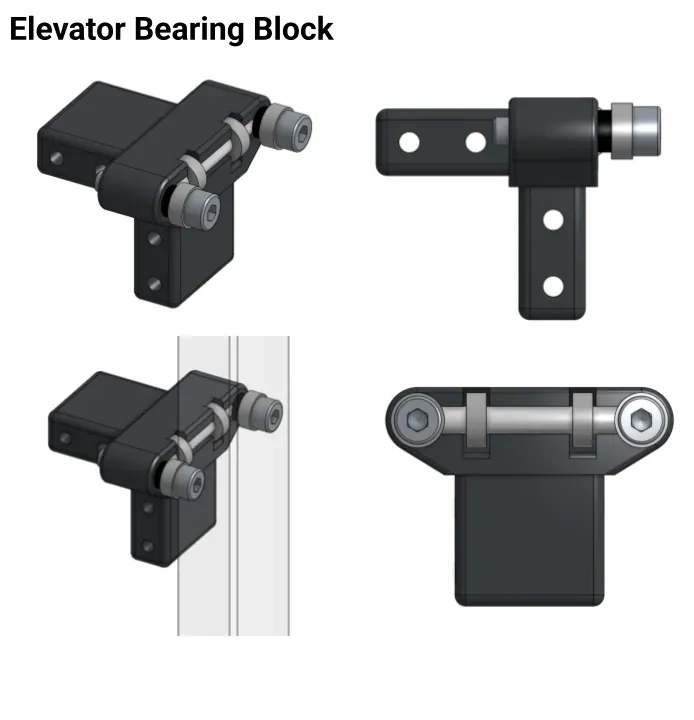
Elevator bearing block: 8 mm bearings guiding the tubes
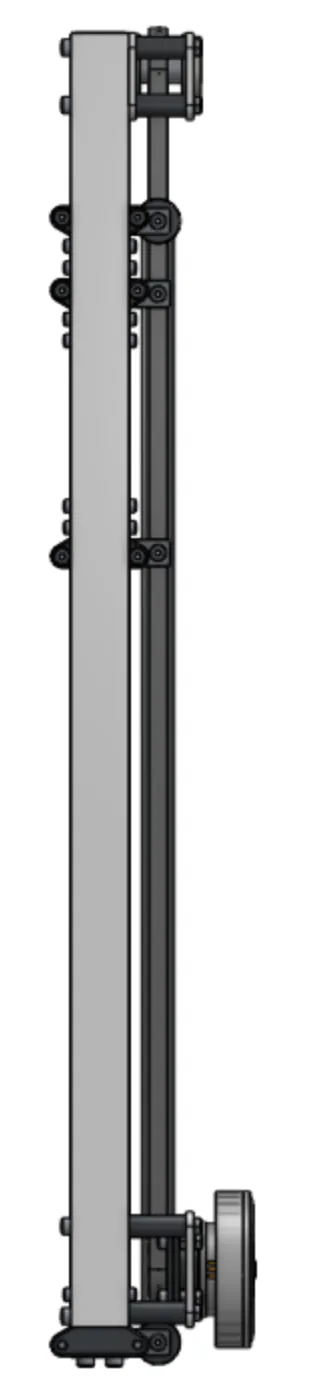
Elevator: two-stage frame, front view08
Elevator: two-stage frame, front view

Gallery

Drill build

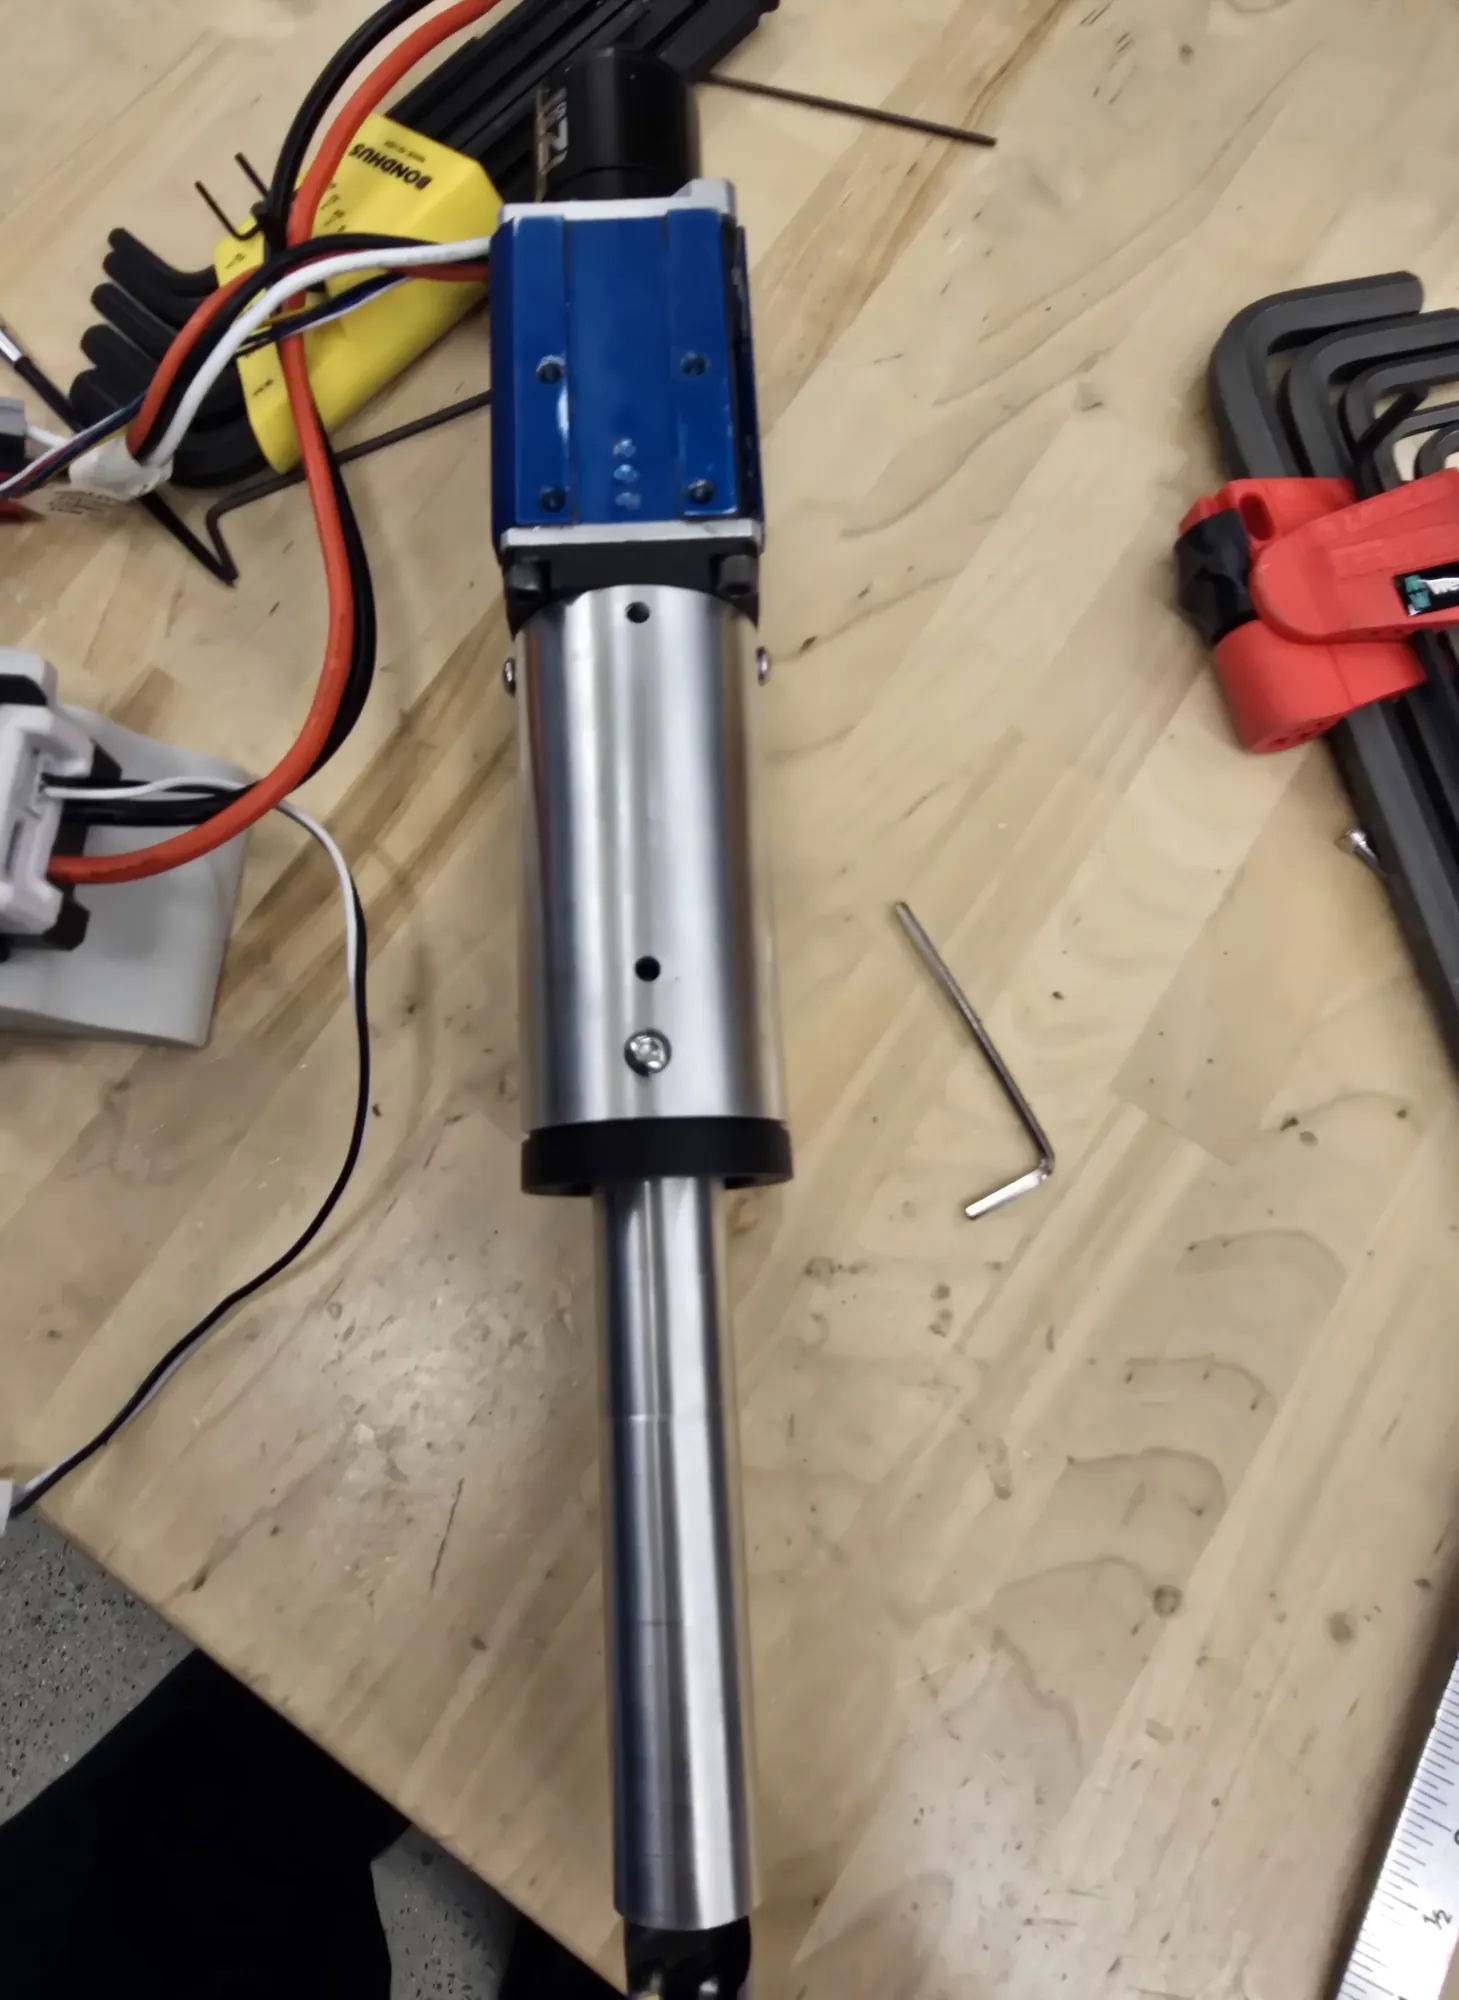
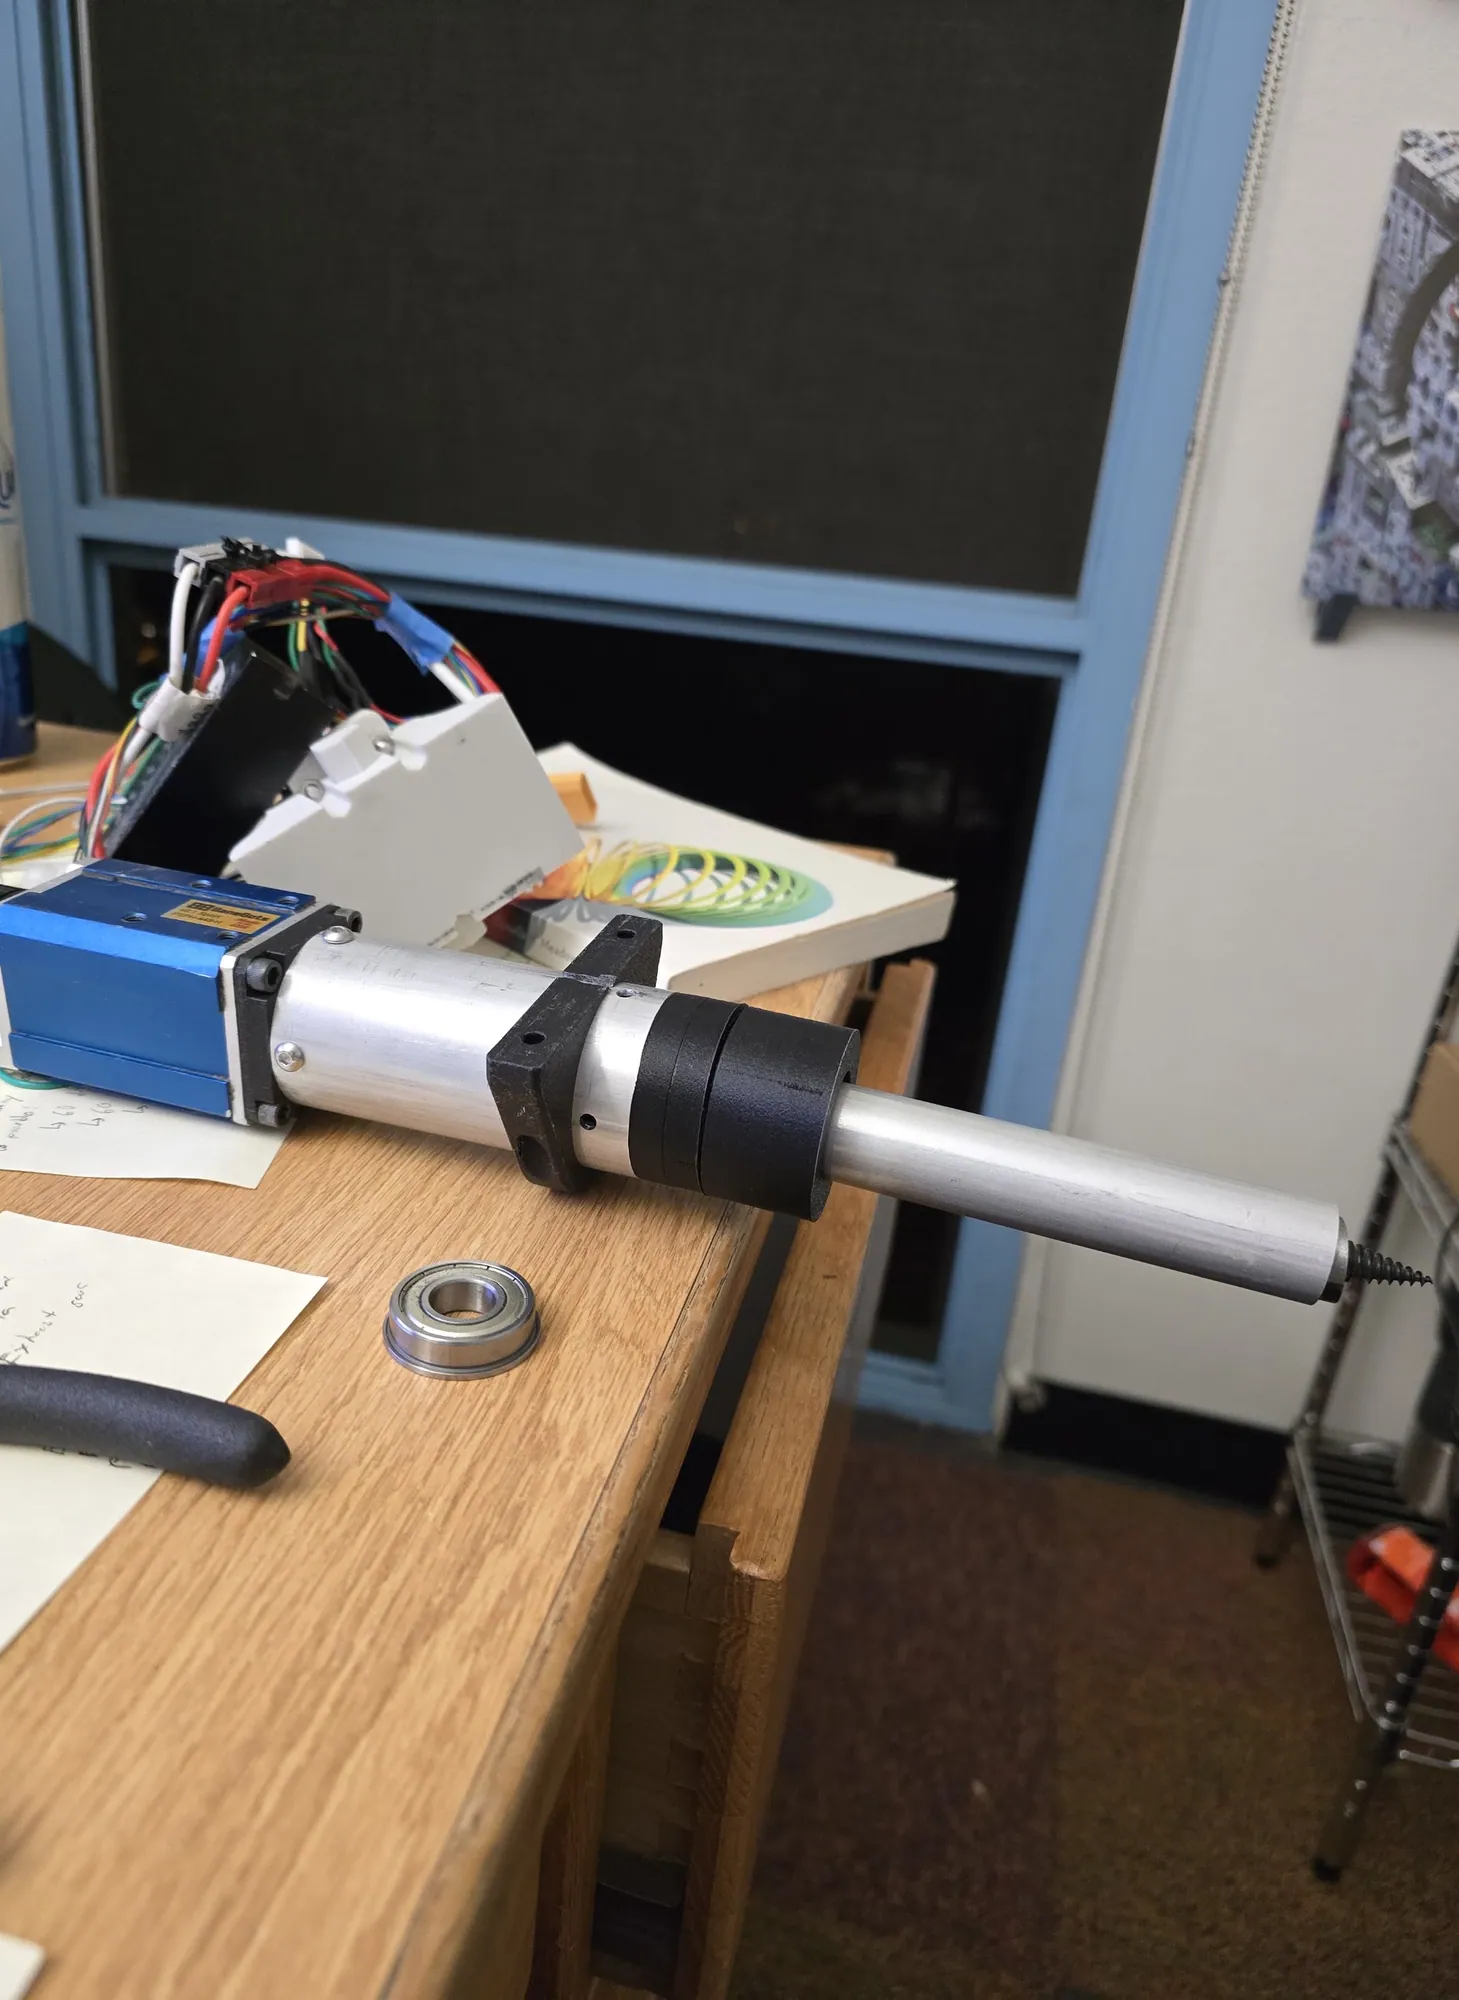
Auger, cache tube, and the NEO 550 gearbox.
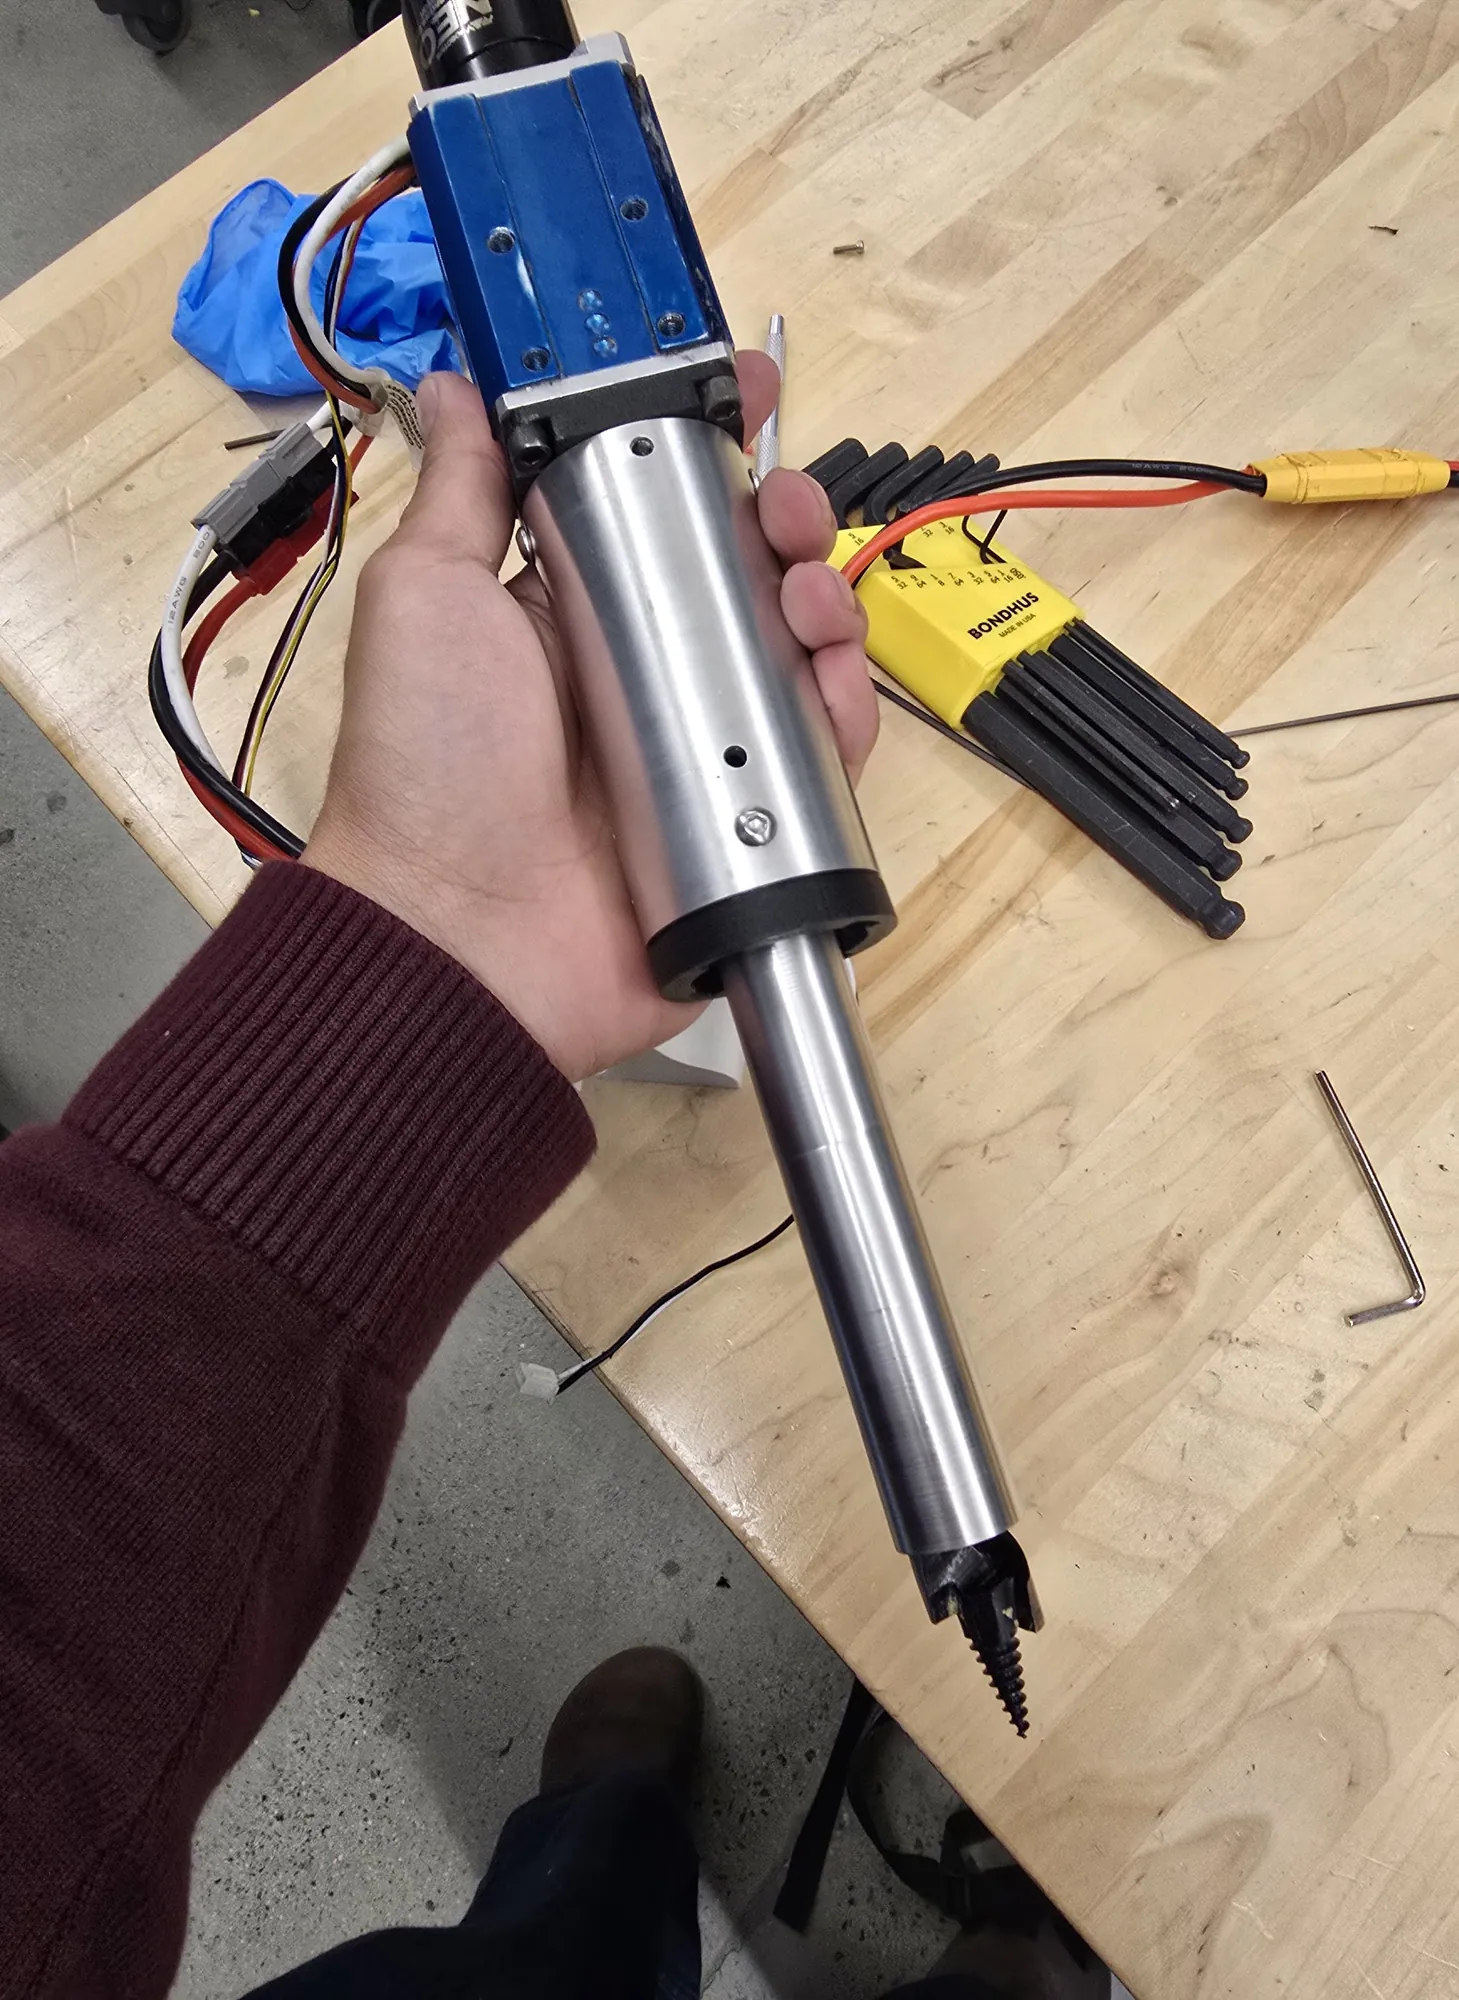
Drill assembly in hand: NEO 550, gearbox, cache tube01
Drill assembly in hand: NEO 550, gearbox, cache tube
Drill on the bench02
Drill on the bench
Drill with the printed cache housing03
Drill with the printed cache housing

Elevator

Two stages: chain first, low-creep cable second.
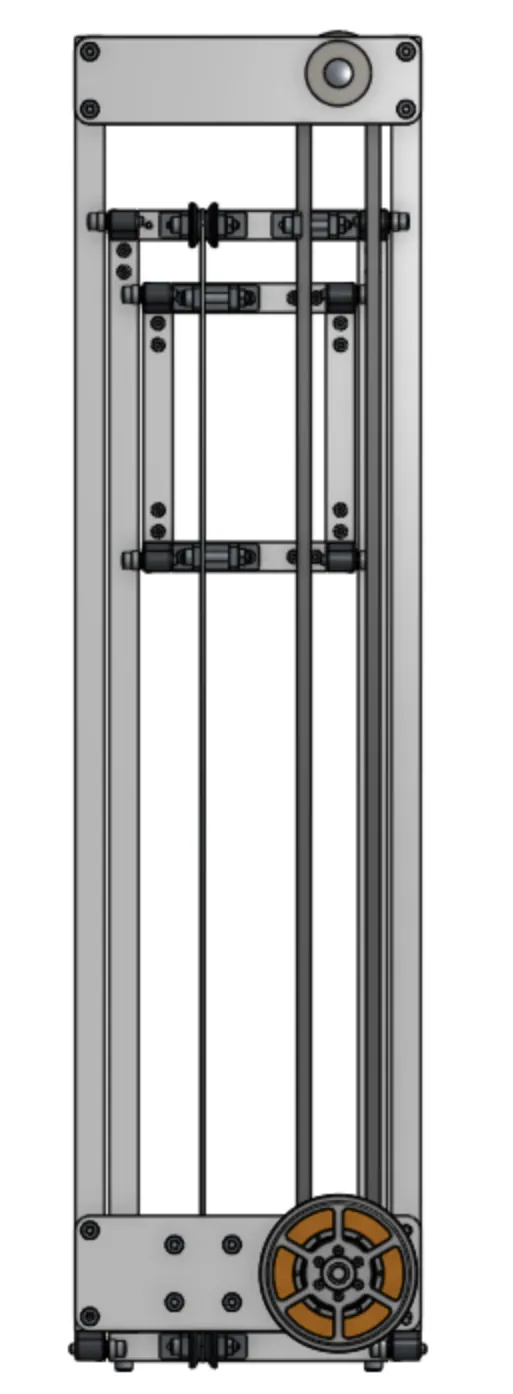
Sprocket and motor at the base of stage one09
Sprocket and motor at the base of stage one
Elevator extended, side view10
Elevator extended, side view
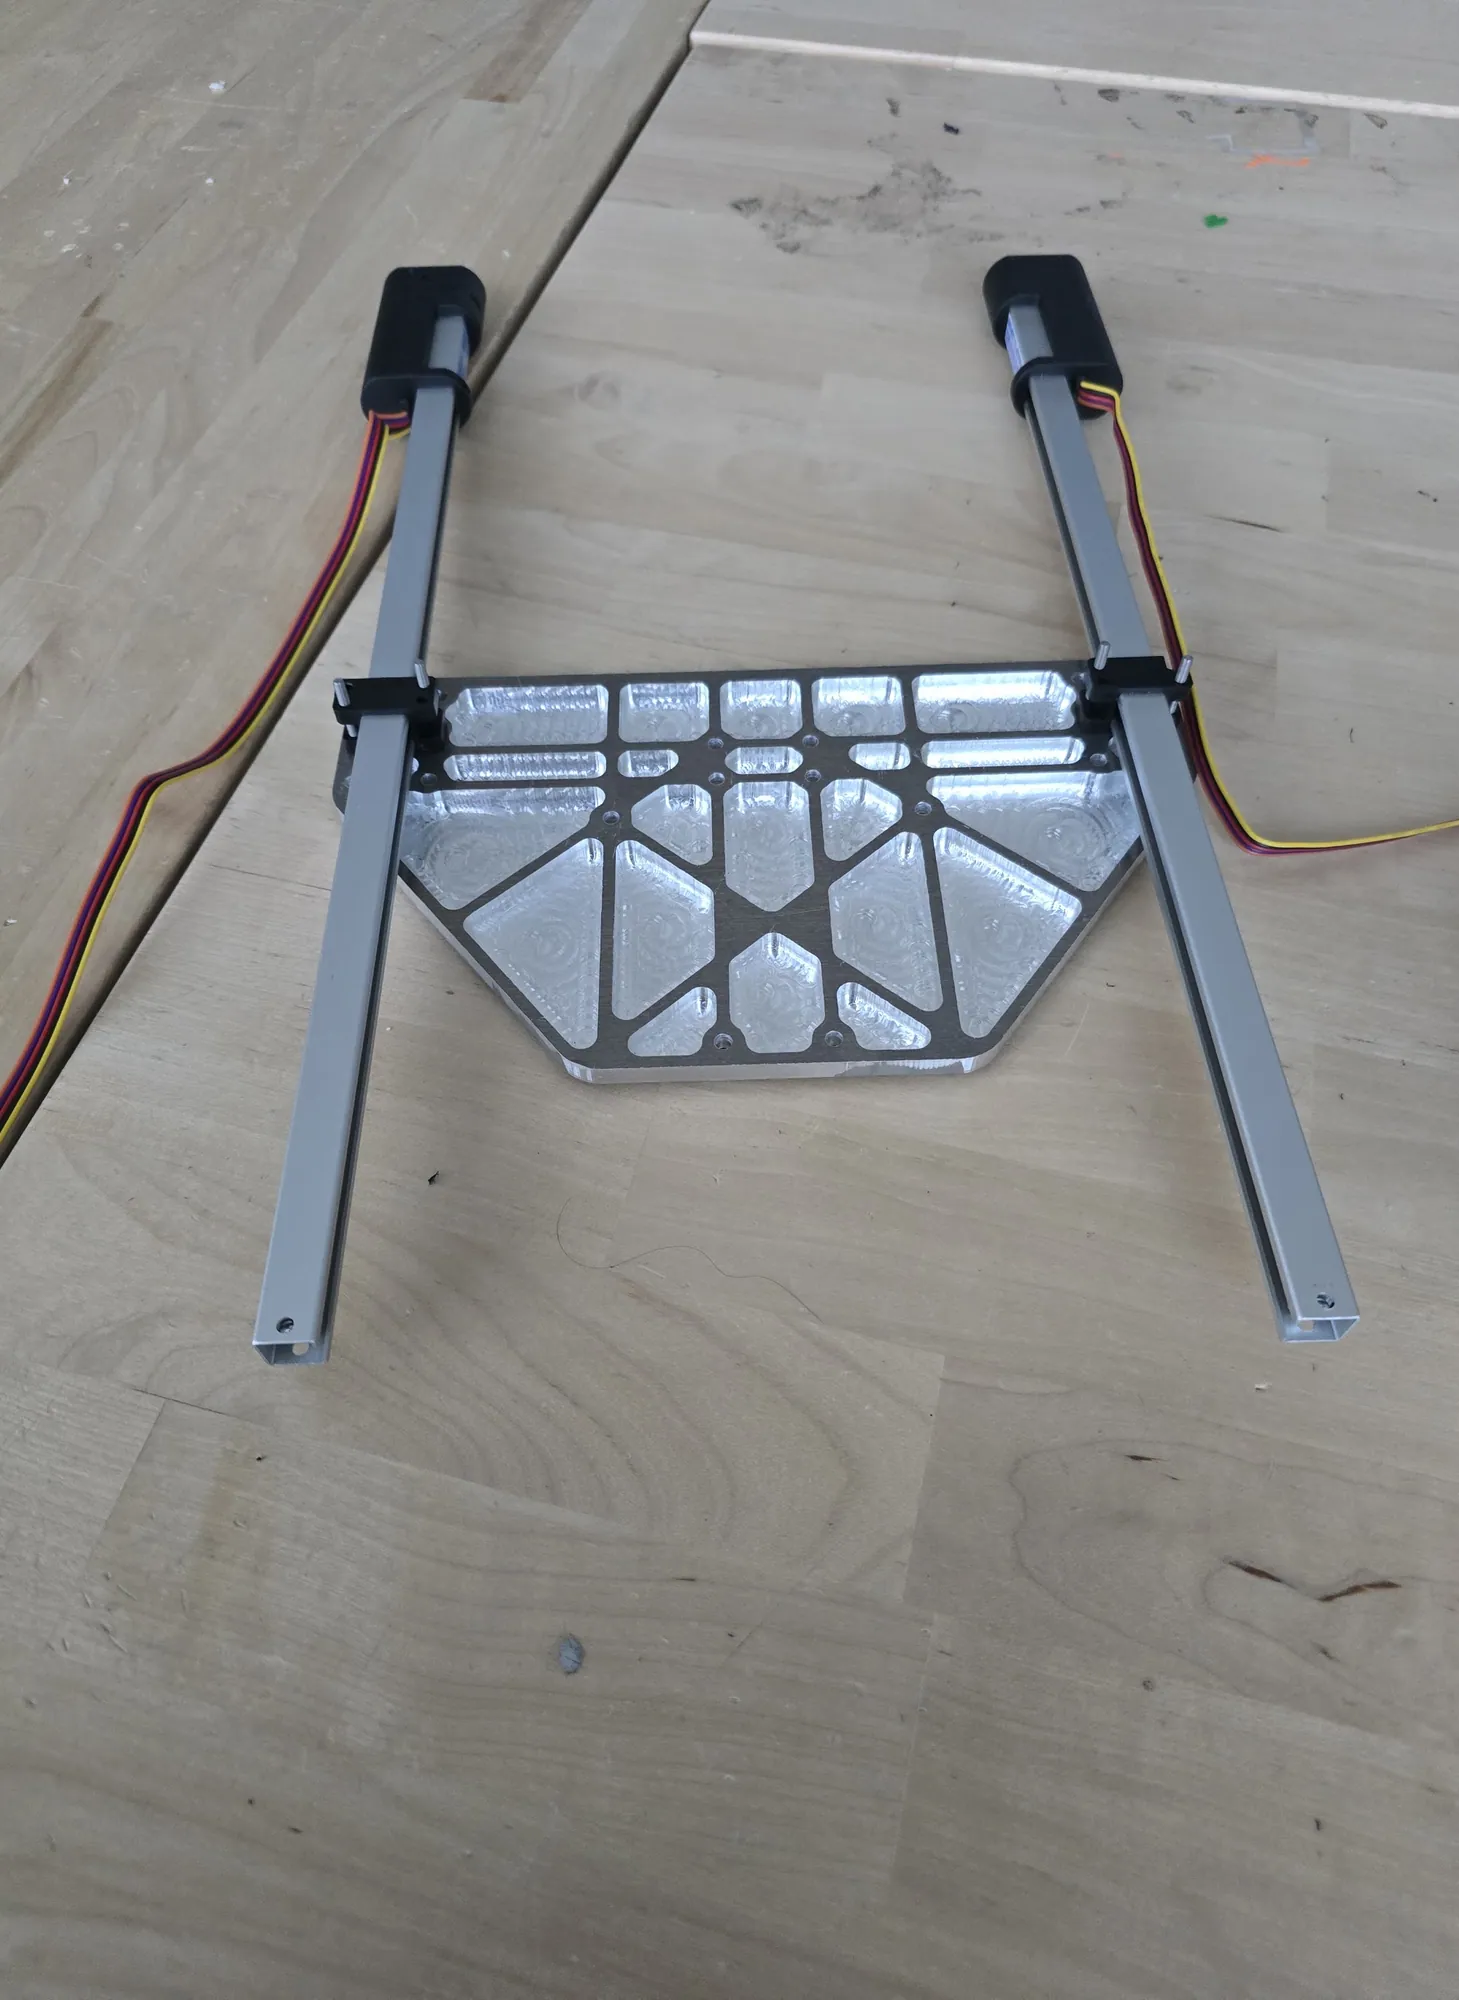
Elevator frame: 1 × 1/2 in tubes and the water-jet lattice carriage05
Elevator frame: 1 × 1/2 in tubes and the water-jet lattice carriage

On the rover

Behind the deck, clear of the arm's workspace.
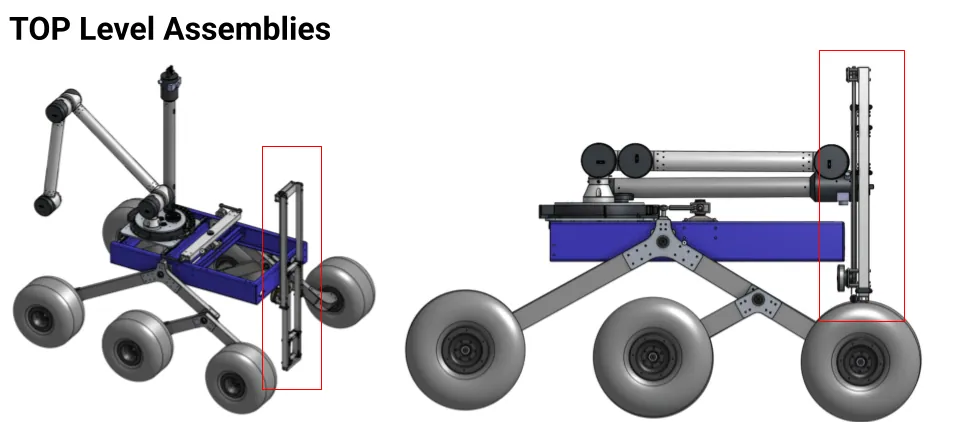
Top level assemblies: where the elevator sits on the rover12
Top level assemblies: where the elevator sits on the rover
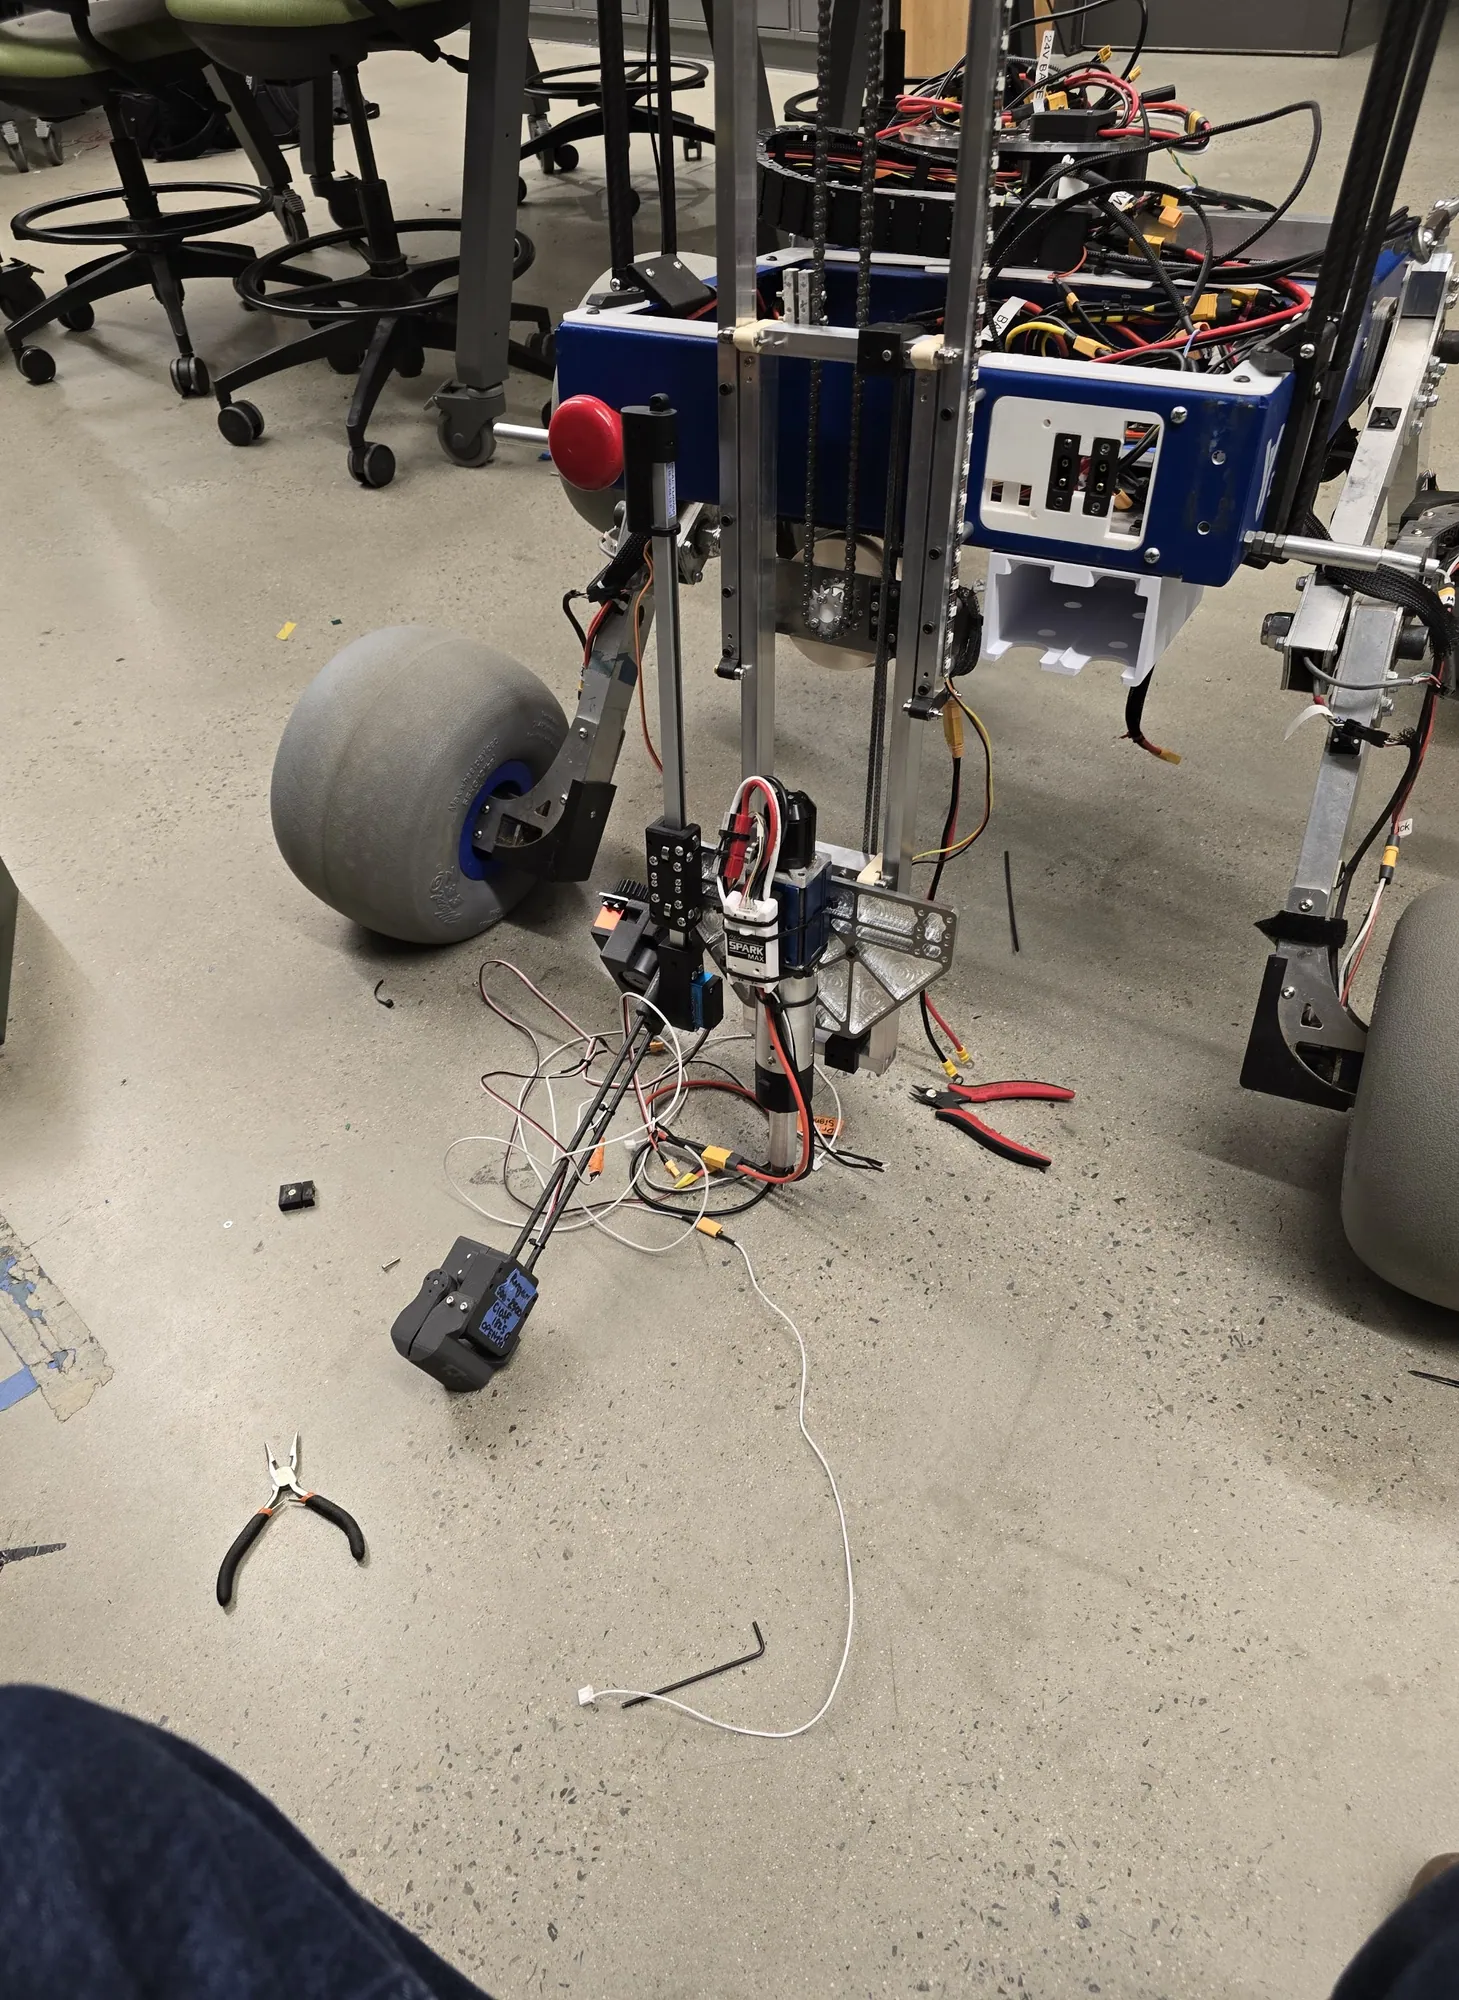
Elevator on the rover in the lab07
Elevator on the rover in the lab
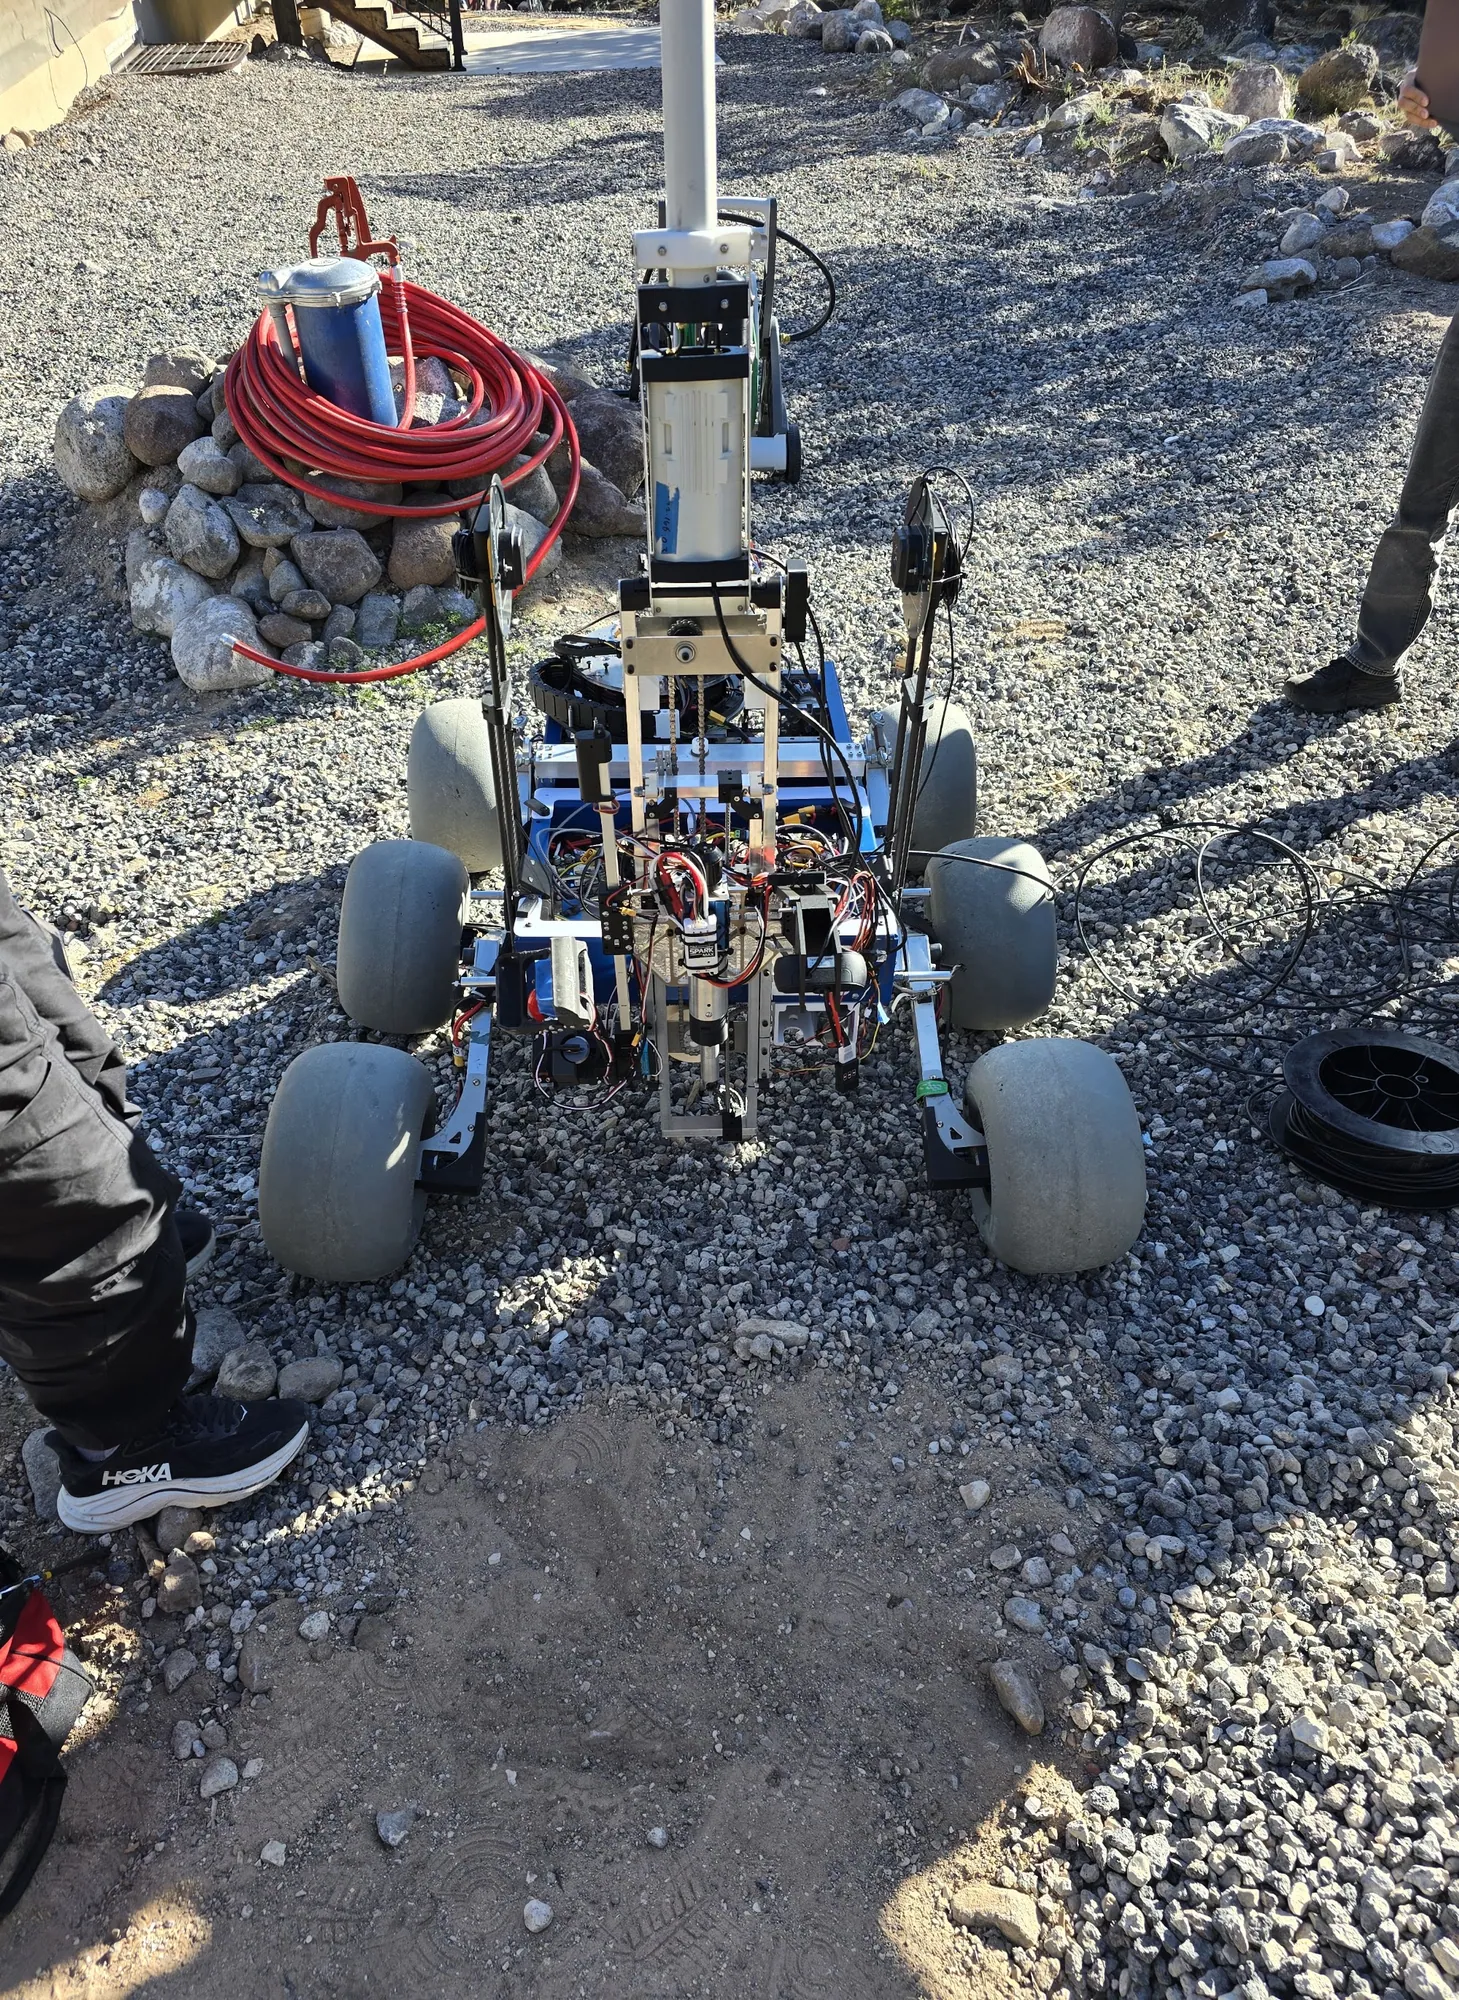
Rover in the field, elevator standing as the rear mast06
Rover in the field, elevator standing as the rear mast

Yonder Robotics

Systems & Architecture