Yonder Robotics · 2026
ARM Sim
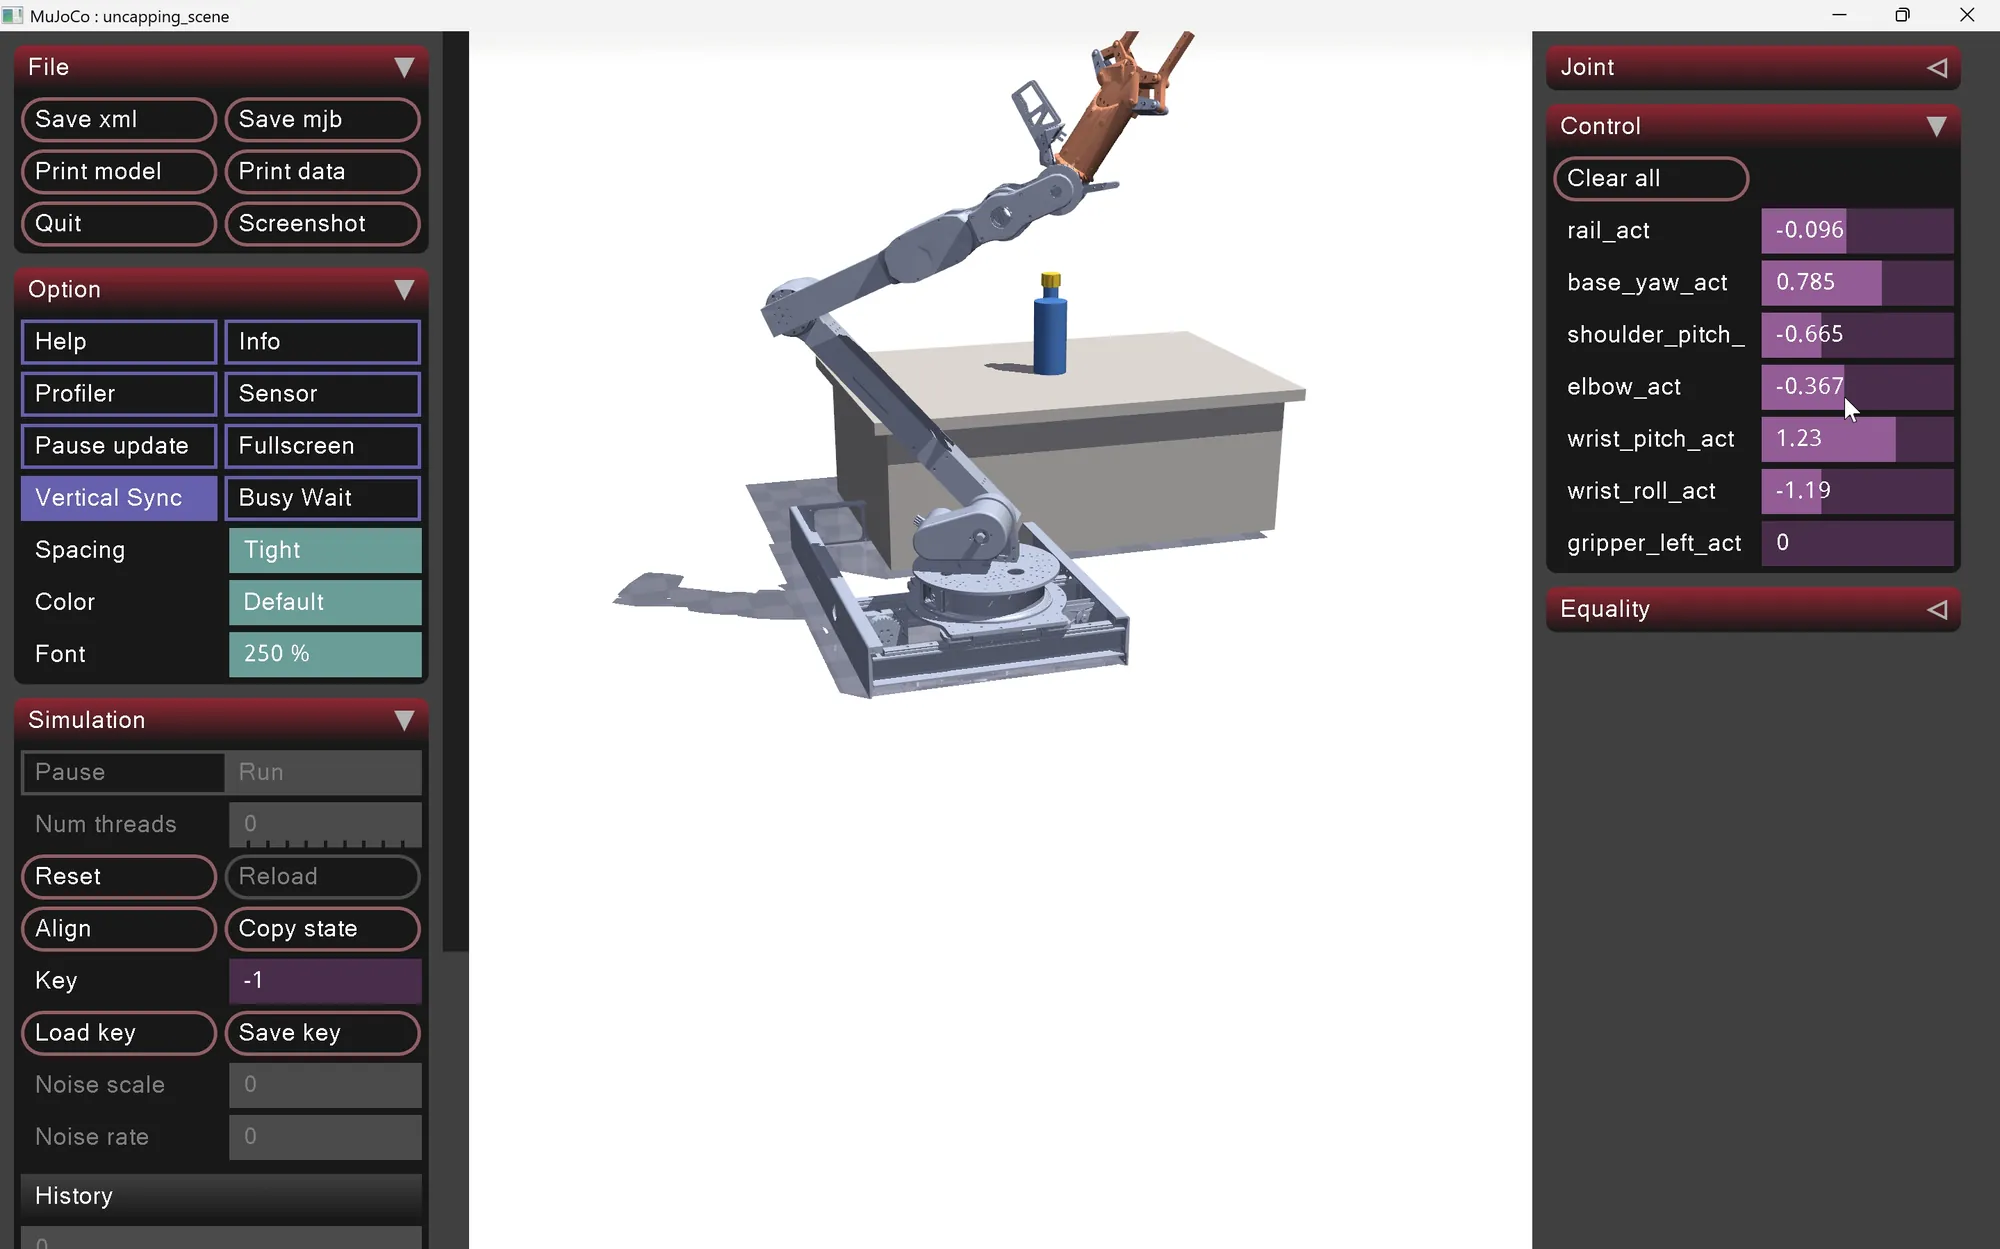
A MuJoCo model of the arm with every joint exposed as an actuator: rail, base yaw, shoulder pitch, elbow, wrist pitch, wrist roll, and the gripper. Somewhere to try a motion before it costs a harmonic drive.
The model
Each joint of the physical arm appears as a named actuator, including the linear rail the base rides on, so the model covers the full reachable workspace rather than the arm alone. Joint values are driven directly, which makes it a debugging tool as much as a simulator: set a pose, see whether it collides.
 01
Solving for reach
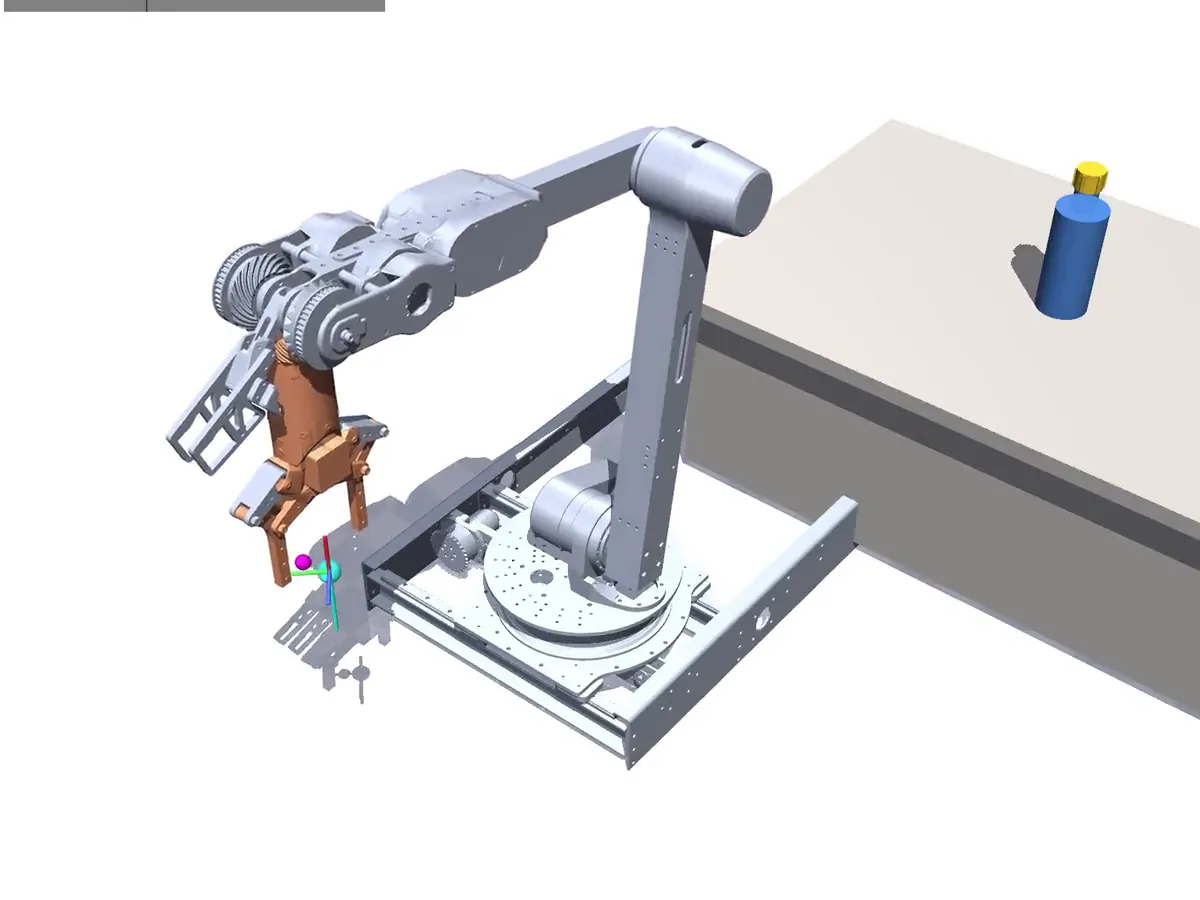
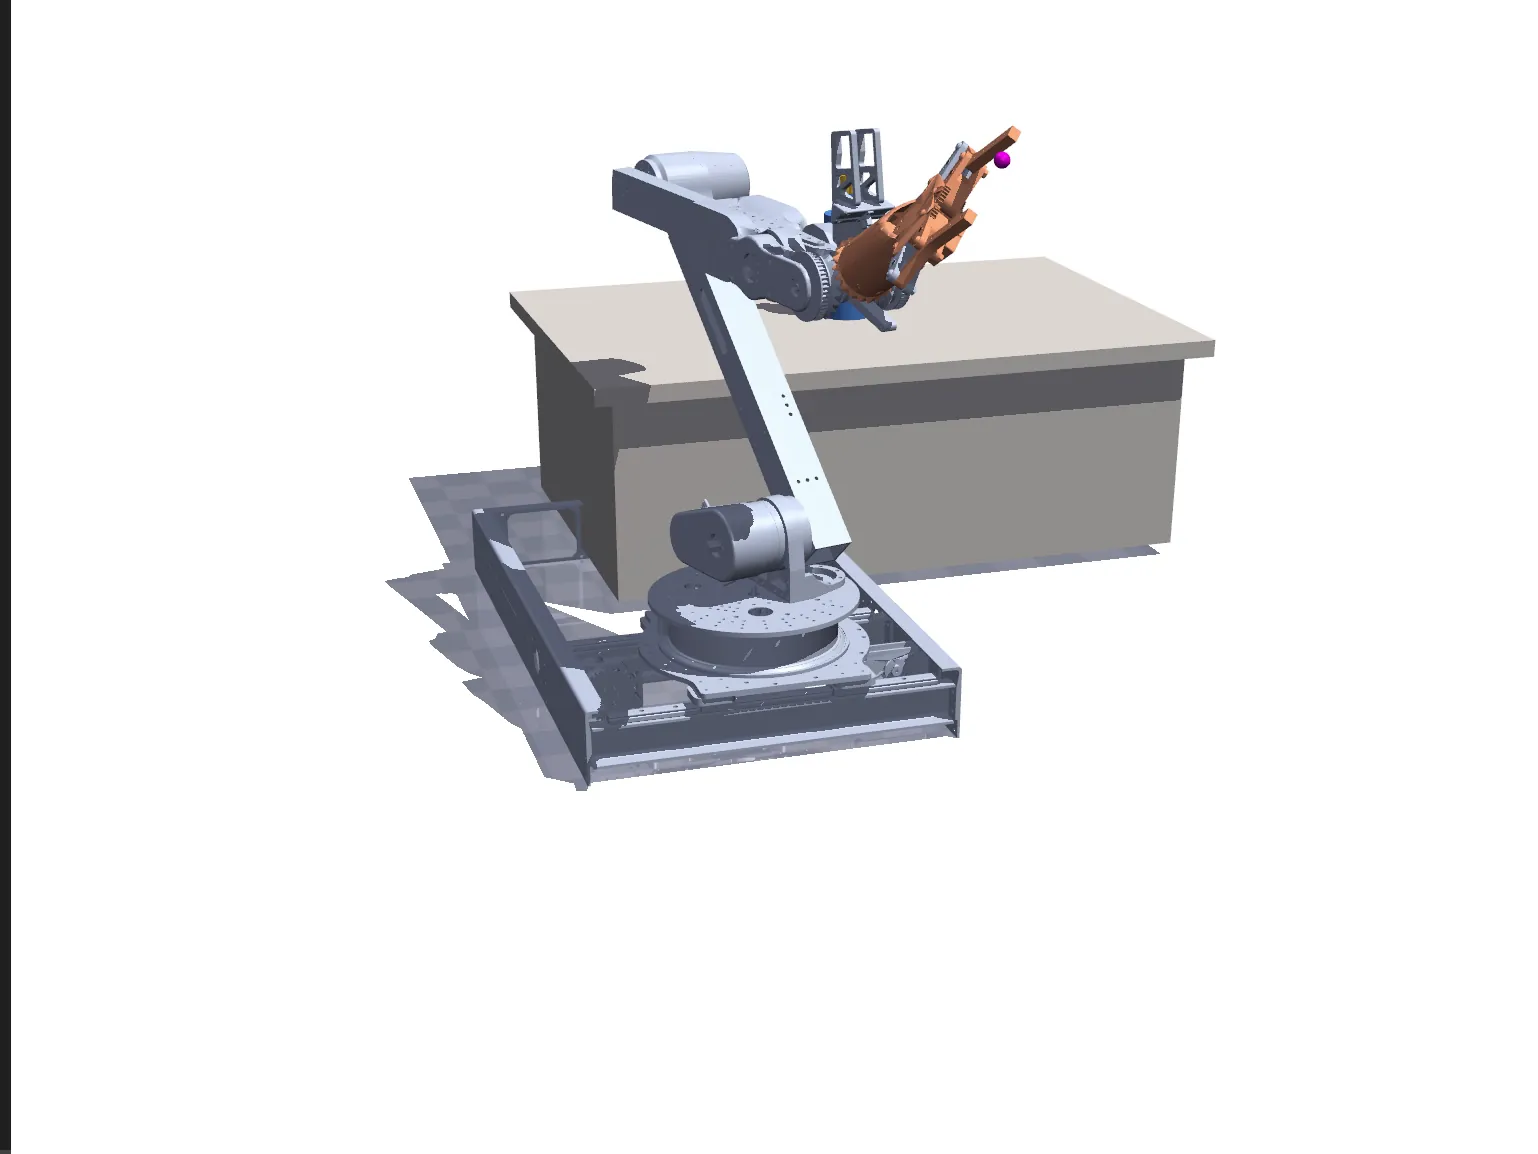
With the model in place, an IK solver takes over and drives the end effector to a target pose, reporting residual position and orientation error as it converges: sub-millimetre and a fraction of a degree on a good solve.
The uncapping scene is the test: approach, align, and turn, with the whole arm plus rail free to find the posture that makes it possible.
Yonder Robotics